It is an honour to invite Isabella Liu to share Recova.
On 10 November at 10:00 am Beijing time, PhD students are also invited to join us for an exchange of ideas.
Subjects of exchange
Failure Recovery in Robot Manipulation: Why is it so difficult for existing VLA strategies to continue from a failed scenario once they go wrong? Why is failure recovery still largely dependent on artificial takeover?
Recova & Real2Sim2Real: How to get programming intelligence to reproduce failures in digital chips built on real observations, diagnose causes, and automatically write replicable recovery skills, then migrate them to real robots for verification and refinement?
From Failures to Autonomy: How to use VLM monitors to determine whether a task has stalled, whether the scenario has recovered, and how to turn each failure into training data by deploying mission strategies, recovery strategies, skills libraries and human demonstration, reducing the number of rounds of AI interventions to zero, making robots more autonomous?
The paper
Recova: Agent-Guided Failure Recovery for Autonomous Robotic Manipulation
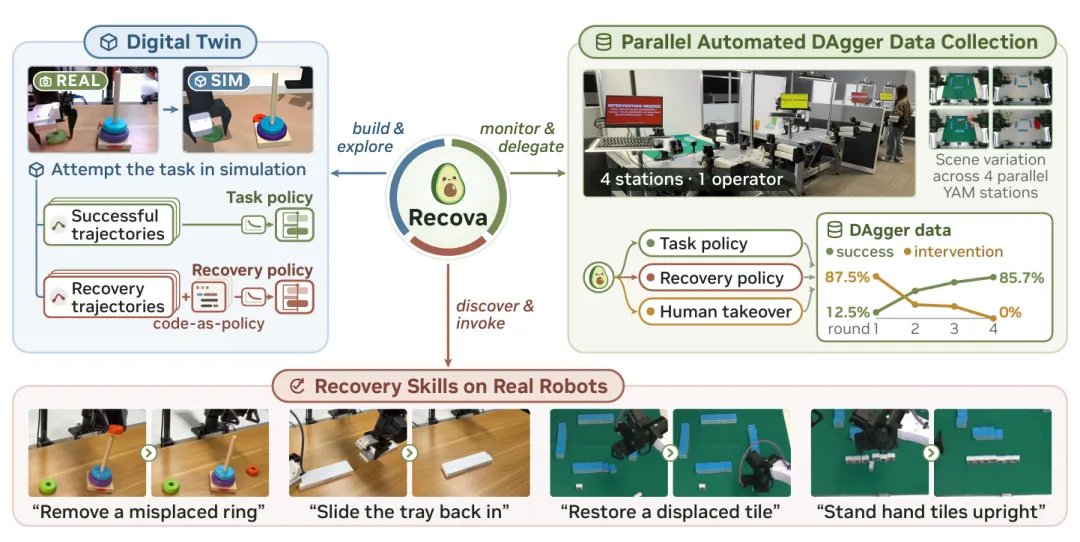
The paper
Project homepage
Personal introduction
Isabella Liu, PhD student in Computer Science at the University of California, San Diego (UC San Diego) and a professor from Xiaolong Wang. Her main research focus is on Robotic Manipulation, Robot Learning and Embodied Agents. She has worked on building autonomous systems that understand, interact with, and continually learn from the physical world, with a recent focus on allowing robots to autonomously complete long-range tasks in the real world and recover from failure. Her research has been published in international academic conferences and journals such as ICLR, NeurIPSCVPR, CoRL, and representative work includes Recova, LoHoManip, RigAnything, DG-Meshthing, and more.
Registration for the event Registration is required: for the purpose of ensuring an interactive experience, students with a PhD-only and in-depth research background in related fields can join the Robotion community at the end of each participant's real name registration, and the link to each event will be placed in the community (no need to re-submit the registration).
 More communication.