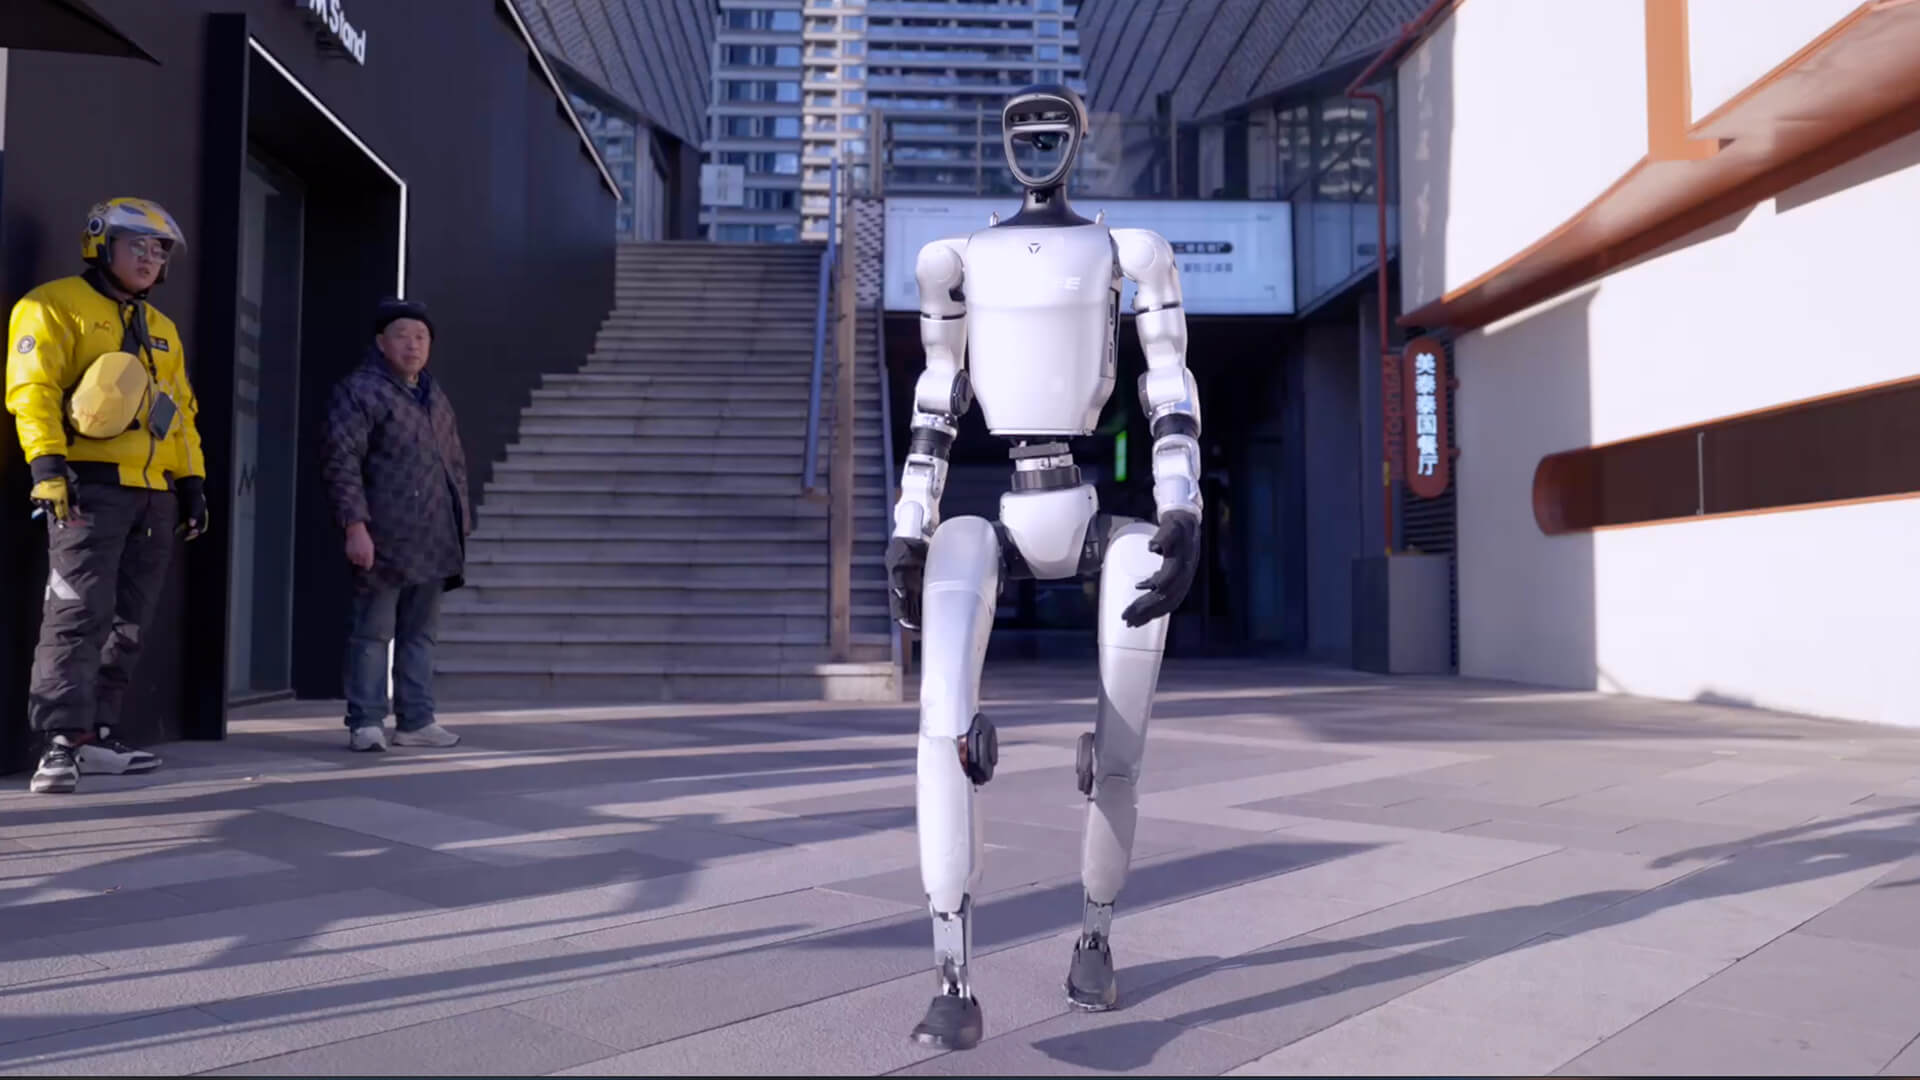


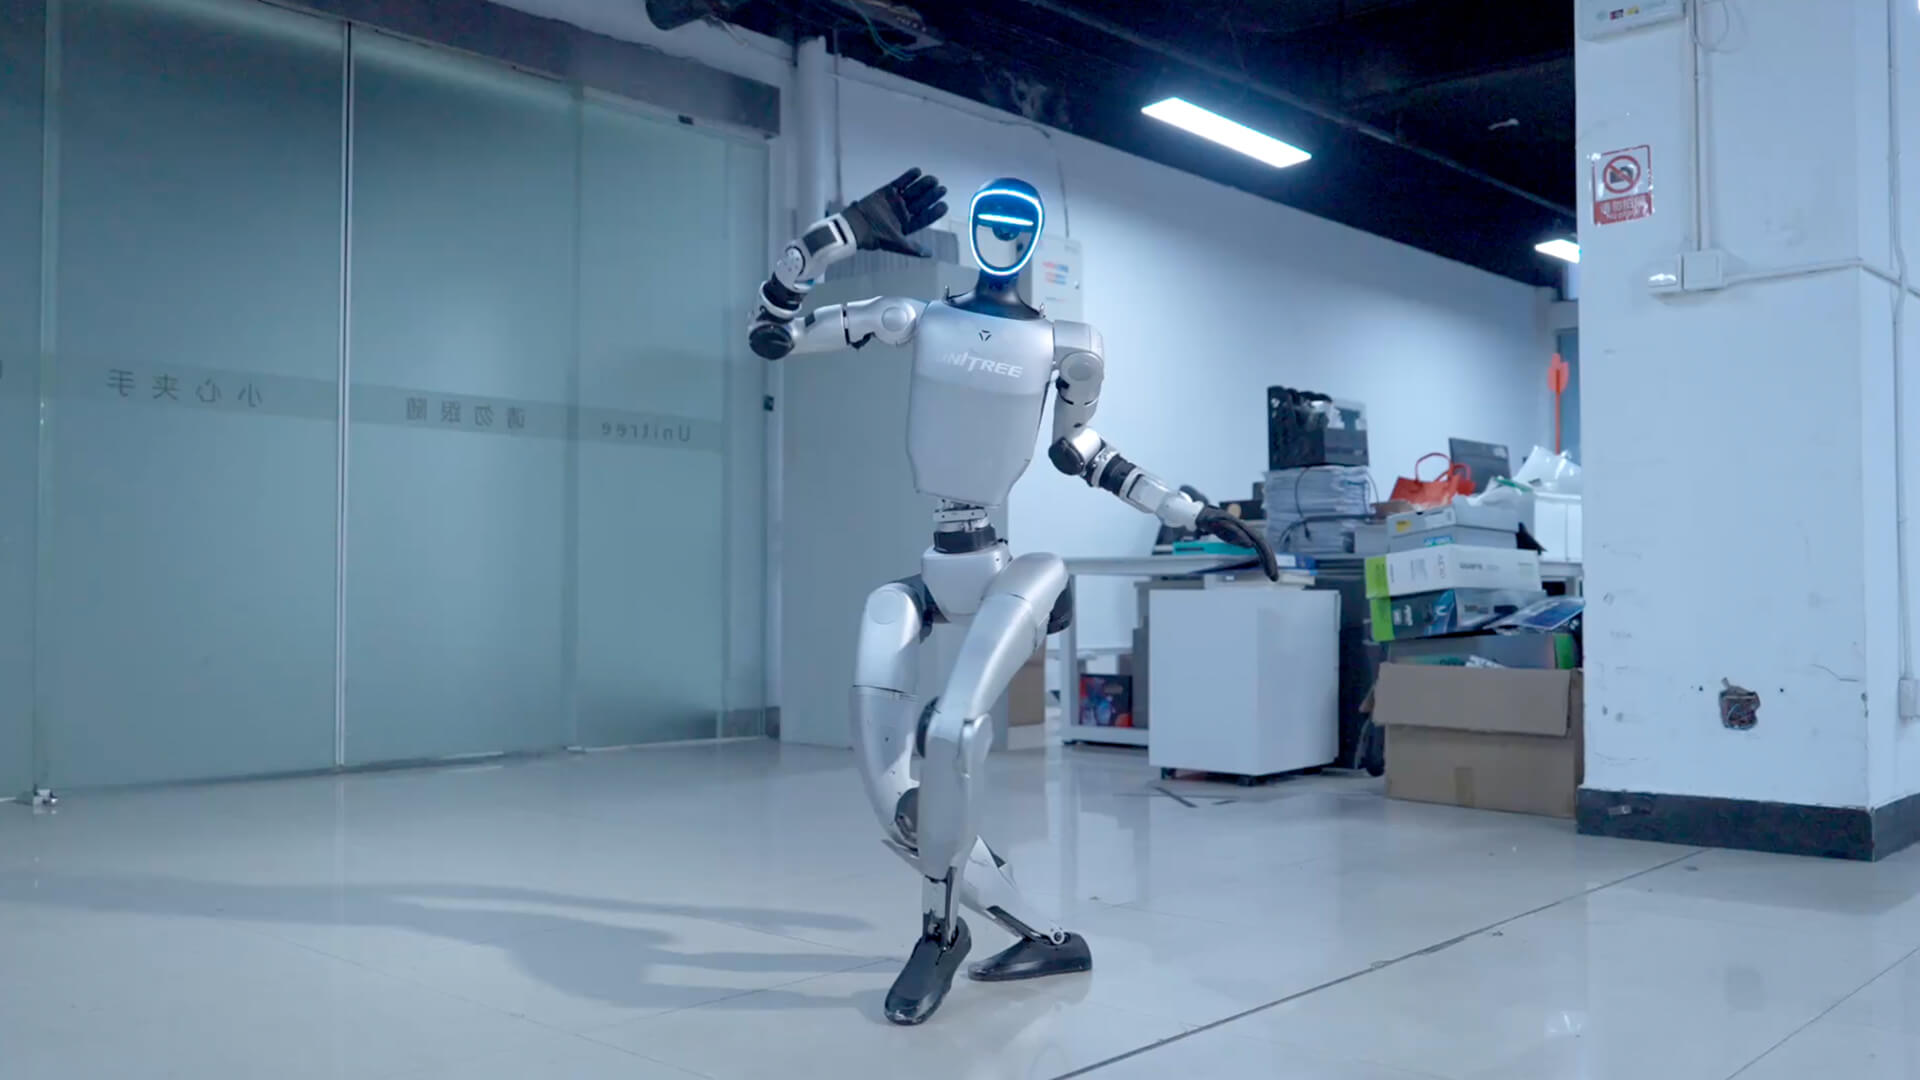
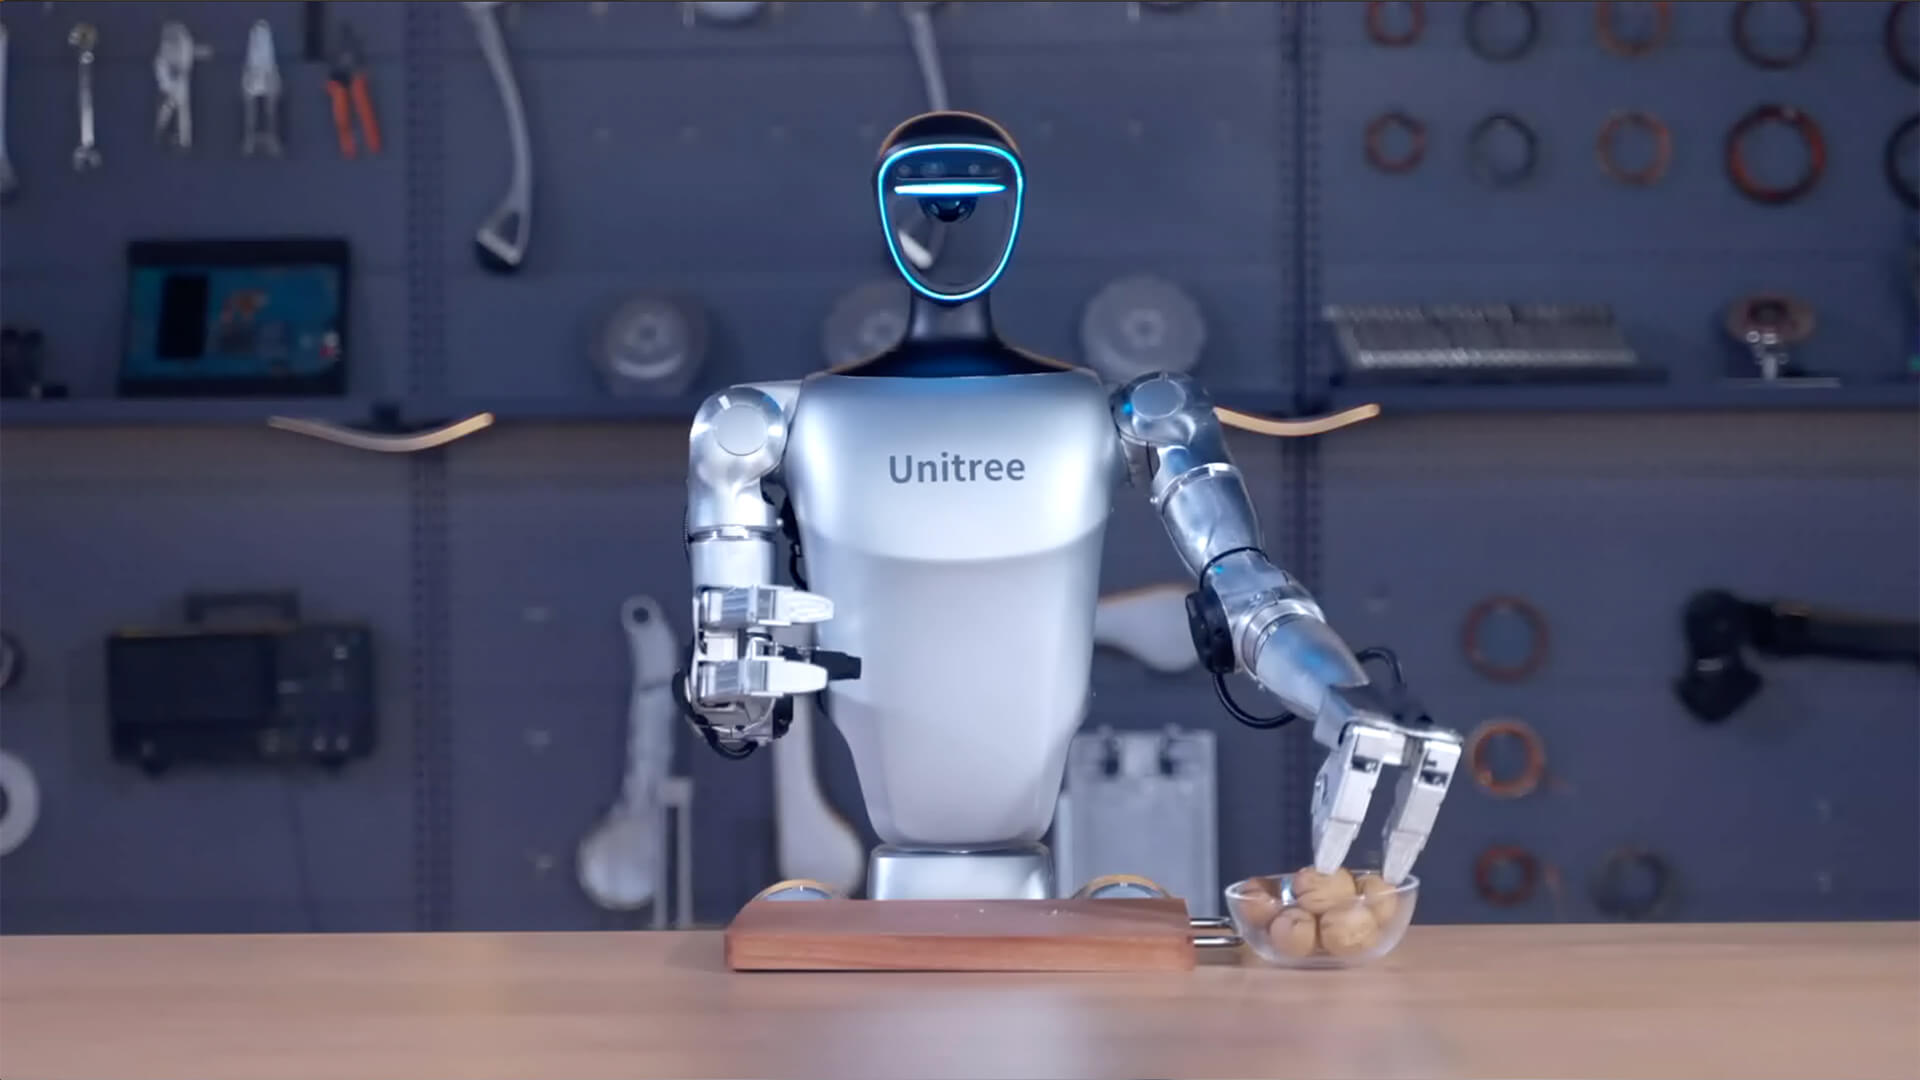
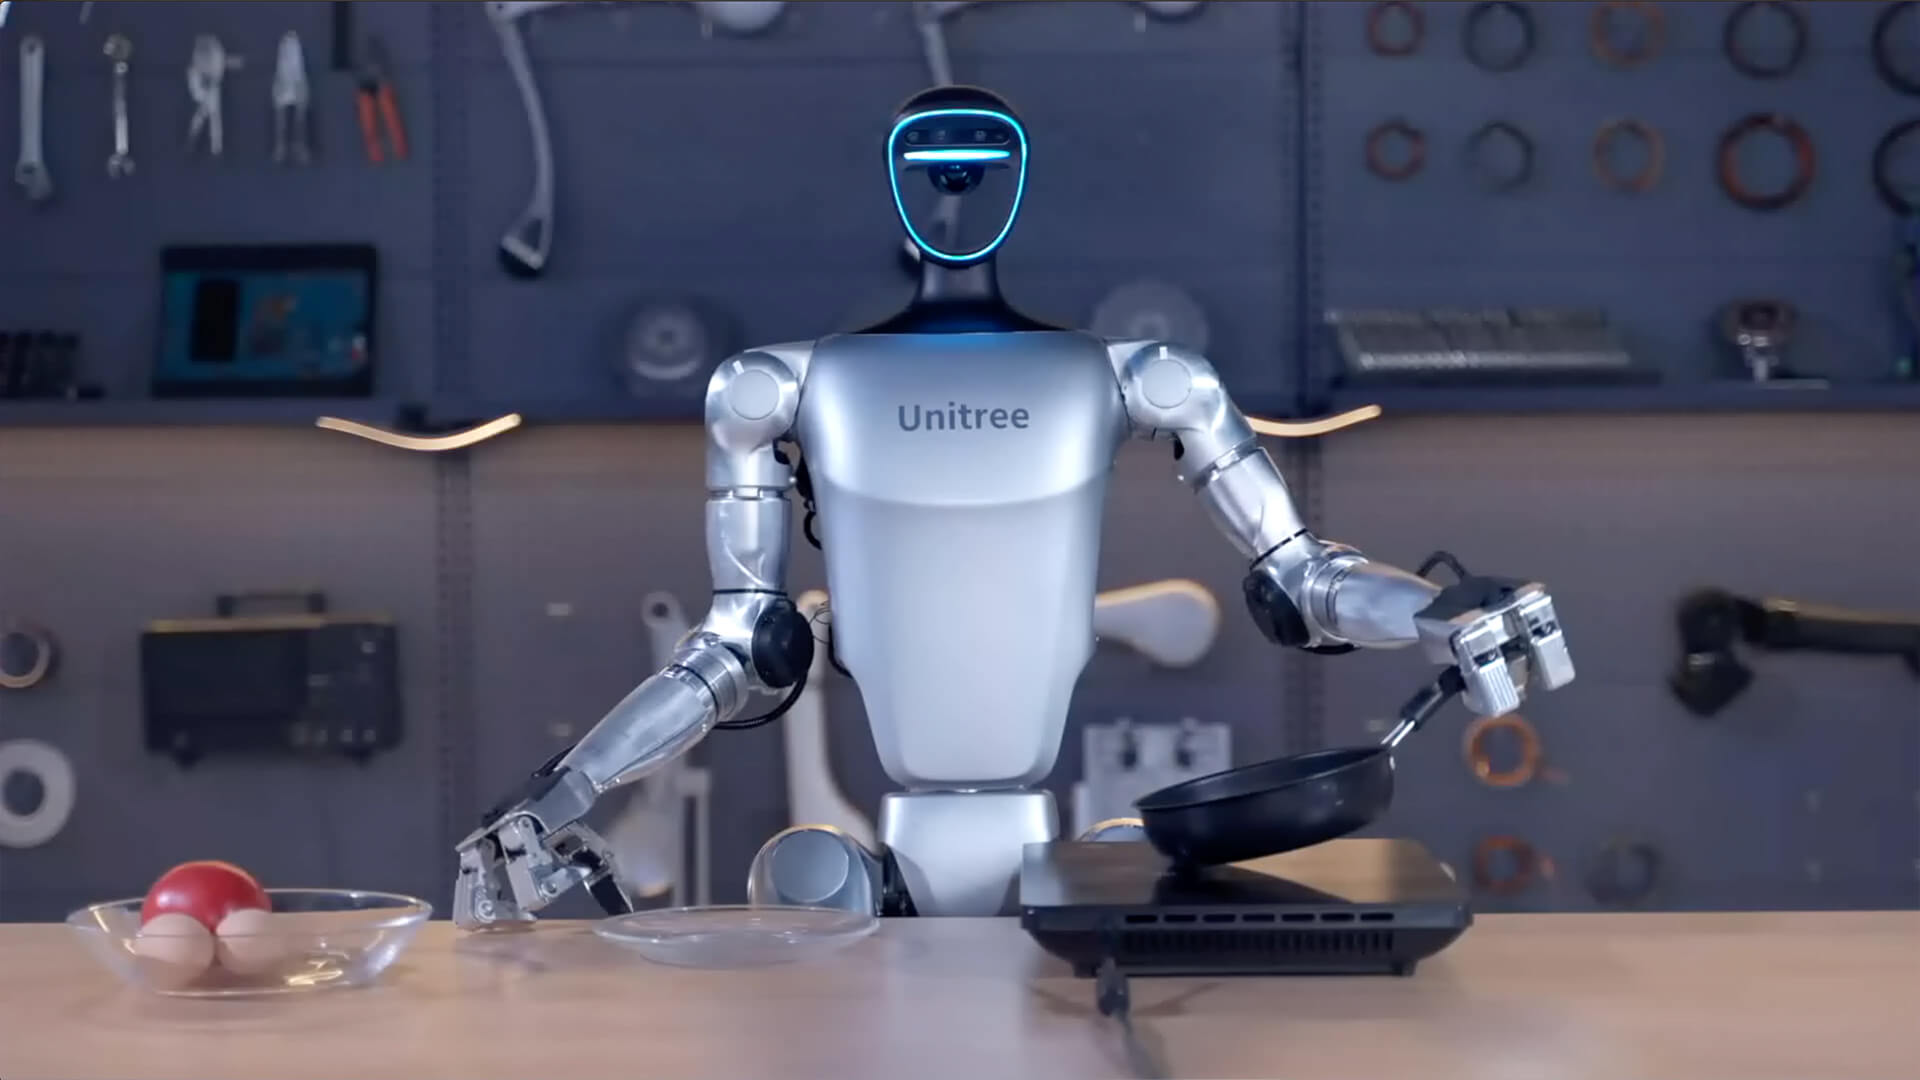


General humanoid robot / research and developer platform
Official Claims
- Listed as G1 Humanoid Agent AI Avatar.
- Official page publishes height, weight, DOF range, arm load, sensors, battery, and pricing information.
- Public page positions G1 as a lower-cost general humanoid development platform.
Official Detailed Specs
| 带电池重量 | 约35kg+ |
|---|---|
| 总自由度(关节电机) | 23 - 43 |
| 单腿自由度 | 6 |
| 腰部自由度 | 1+(可加选2个腰部自由度) |
| 单手臂自由度 | 5 |
| 单手自由度 | 7(可加选力控3指灵巧手Dex3-1)+ 2(可加选2个手腕自由度) |
| 关节输出轴承 | 工业级交叉滚子轴承(高精度,高承载力) |
| 关节电机 | 低惯量高速内转子永磁同步电机(更好的响应速度和散热) |
| 膝关节最大扭矩【1】 | 120N.m |
| 手臂最大负载【2】 | 约3Kg |
| 超大关节运动空间 | 腰关节:Z±155°、X±30°、Y±30° |
| 全关节中空内走线 | 有 |
| 关节编码器 | 双编码器 |
| 基础算力 | 8核高性能CPU |
| 高算力模组 | 多品牌多型号可选 |
| 智能电池(快拆) | 9000mAh |
| 续航时间 | 约2h |
Source: https://www.unitree.com/cn/g1/
产品介绍
The Unitree G1 is a compact humanoid robot designed for AI-powered mobility and manipulation. It stands out for its agility, force-controlled dexterous hands, and the ability to perform tasks like backflips and fine object handling.
Founded in 2016 by Xingxing Wang , Unitree Robotics emerged from academic research focused on low-cost, high-performance legged locomotion. While pursuing his master’s degree, Wang independently developed the XDog —a quadruped robot using low-cost external rotor brushless motors and a full-degree-of-freedom actuation system. His work included custom motor drive board design, control architecture development, and simulation-based validation of robot gait dynamics. This approach, emphasizing affordability without sacrificing capability, has since become a widely adopted development strategy in quadruped robotics.
资料来源:ROBOTS Guide
 企业会员