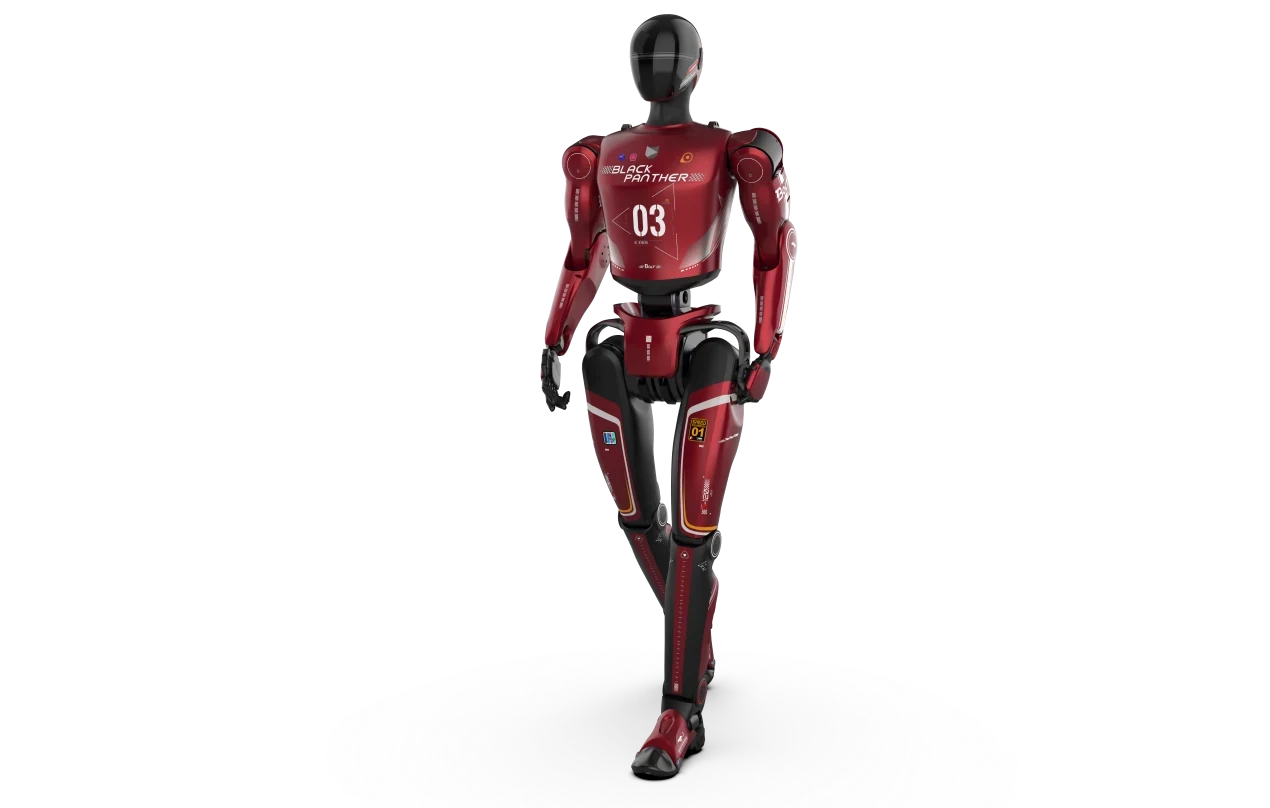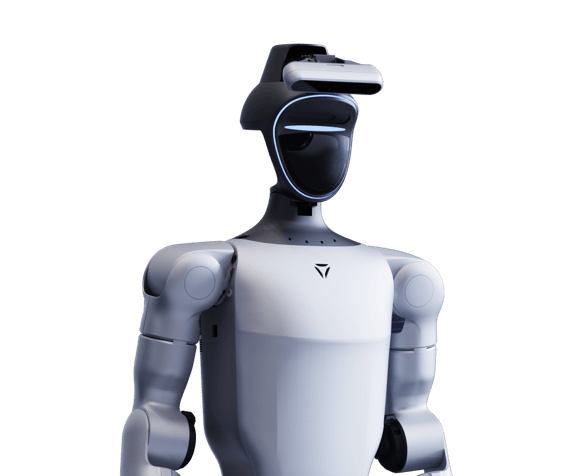


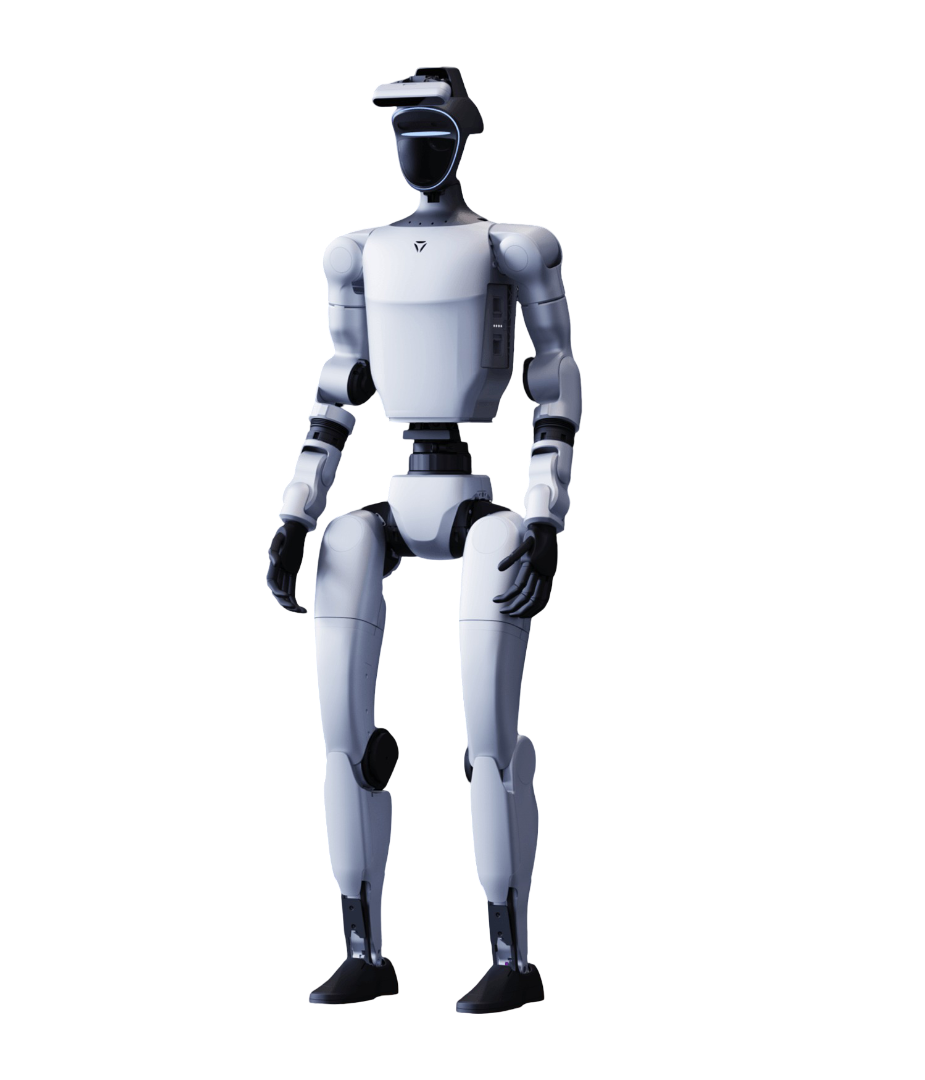


Competition‑grade humanoid robot for RoboCup with high‑speed locomotion and elite stability The G1‑Comp is a 35 kg humanoid with 25–45 DOF and 120 Nm knee torque enabling fast acceleration, stable turning and impact recovery. Its foldable frame from 1320×450×200 mm to 690×450×300 mm supports transport and on‑field agility. It reaches 3.3 m/s sprint speed and maintains ±2° pitch‑roll stability on uneven turf. LIVOX MID‑360 LiDAR RealSense depth vision and YOLO11 stadium detection enable mapping, target tracking and opponent localization. Its software ecosystem includes a Jetson Orin NX module with 100–157 TOPS AI compute, the unitree_rl_gym RL framework, Isaac Gym and Mujoco simulation pipelines, and a dedicated RoboCup SDK providing APIs for motion control, spatial positioning, vision processing, and competition‑rule integration. Dual‑encoder joints enhance precision, while fast‑swap batteries deliver ~2 hours of continuous operation with rapid charging support. Ideal for RoboCup competition teams, locomotion‑research groups, reinforcement‑learning labs, and developers needing high‑speed humanoid autonomy in dynamic, multi‑agent environments.
规格参数
| max. Payload | 3 kg |
|---|---|
| DOF | 45 |
| Weight | 35 kg |
| Height | 1,320 mm |
| Speed | 2 m/s |
| Max Joint torque | 120 nm |
 企业会员