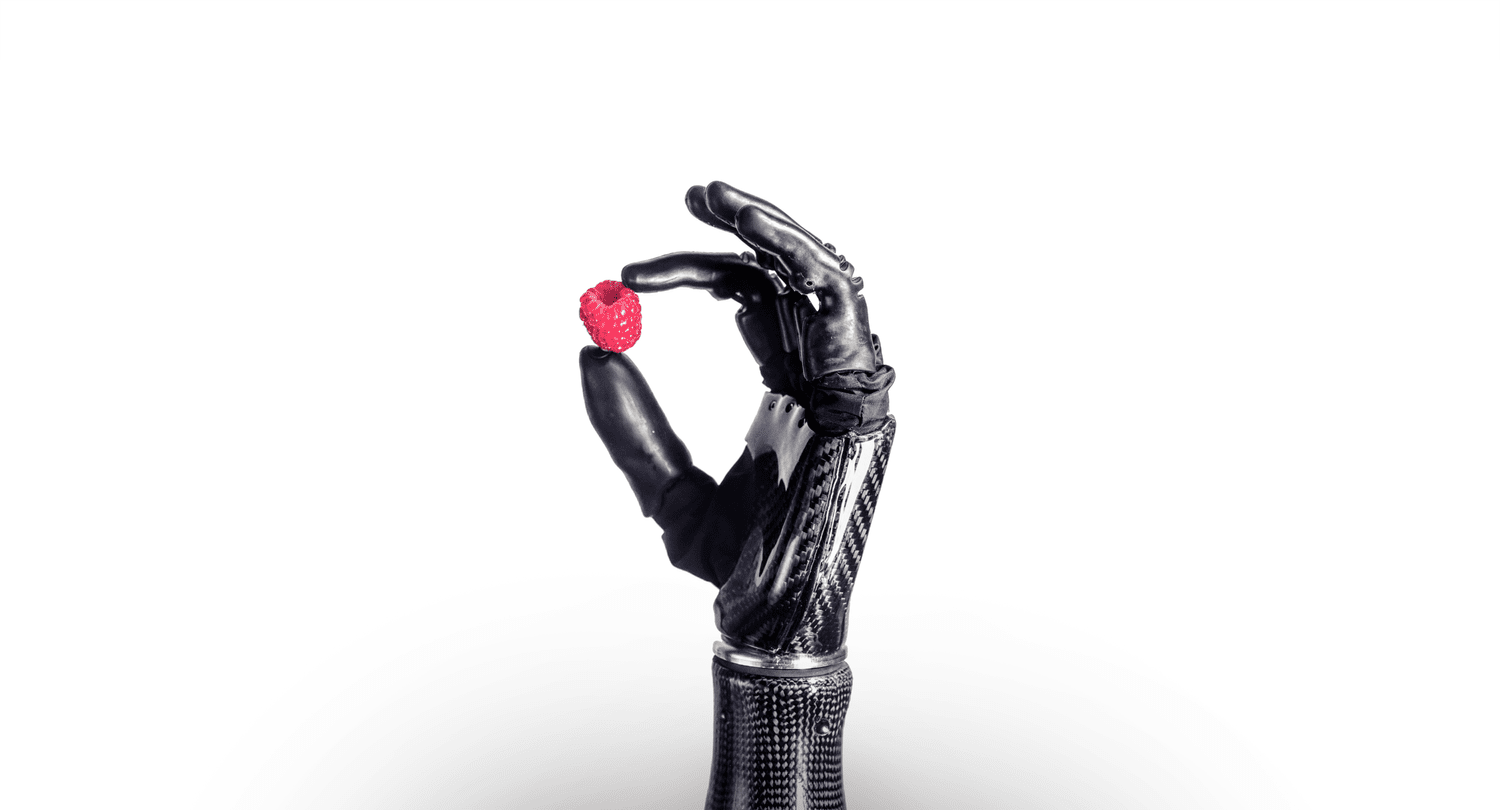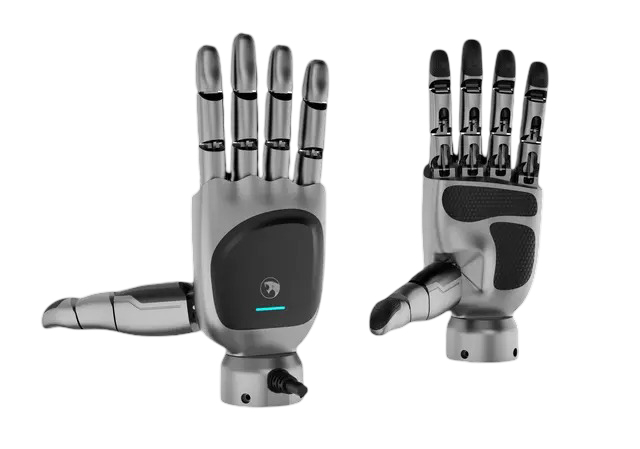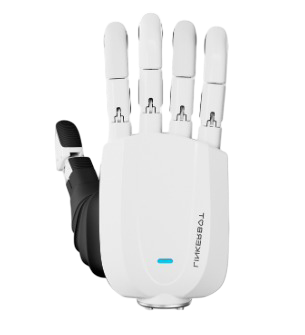


Linkerbot Linker Hand L6 – 6-DOF High-Performance Dexterous Hand The Linkerbot Linker Hand L6 is a high-performance dexterous hand with 6 active degrees of freedom, adopting linkage transmission and self-developed motor drive to ensure stable traction, precise control and excellent motion performance. It is equipped with an advanced multi-sensor system including camera and electronic skin for full-dimensional environmental perception and interaction. It features innovative edge-cloud integration, enabling fast deployment via cloud skill library without coding to realize efficient customized operation and lower usage difficulty. Weighing 623.5g with a maximum payload of 28kg and ±0.2mm repeat positioning accuracy, it is widely used in humanoid robots, industrial flexible operation, embodied intelligence research, robot development and various precise grasping and assembly scenarios, providing a stable and high-performance dexterous manipulation solution for intelligent robotics applications.
规格参数
| Weight | 0.623 kg |
|---|---|
| Max Gripping force | 50 N |
| Propulsion Method | 电动 |
| Repeatability | 0.2 mm |