

The INEXBOT C1102 is an EtherCAT industrial robot controller using an IPC + RTOS architecture. The manufacturer describes support for multiple robot structures and synchronized multi-robot motion.
Specifications
| Product model | C1102 |
|---|---|
| Controller type | IPC+RTOS EtherCAT industrial robot controller; X86 platform |
| CPU model | Intel Celeron J1900, 2.0 GHz |
| Memory | 4 GB |
| Operating system | Linux RT |
| Controlled axis count | Up to 64-axis synchronized interpolation; up to 4 robots simultaneously |
| Communication protocol | EtherCAT, Profinet, Ethernet/IP, OPC-UA, FinsTCP, TCP/IP, ModbusTCP, ModbusRTU |
| Fieldbus | EtherCAT and CANopen |
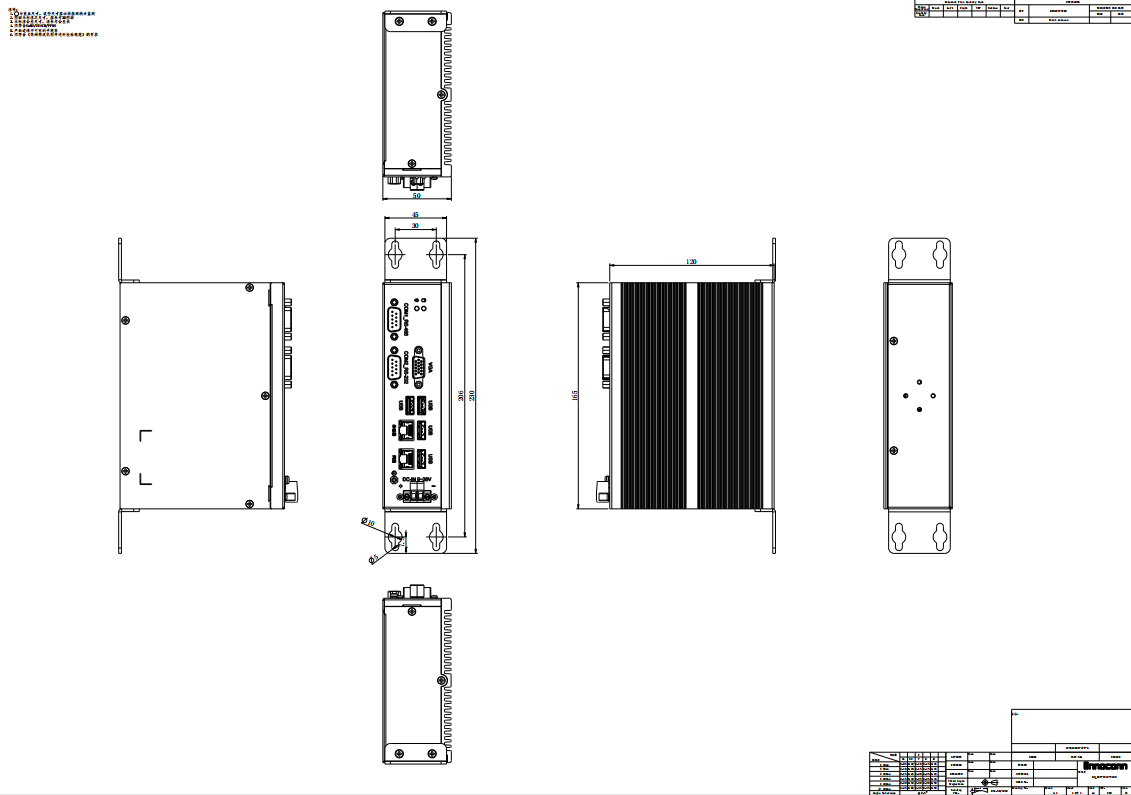
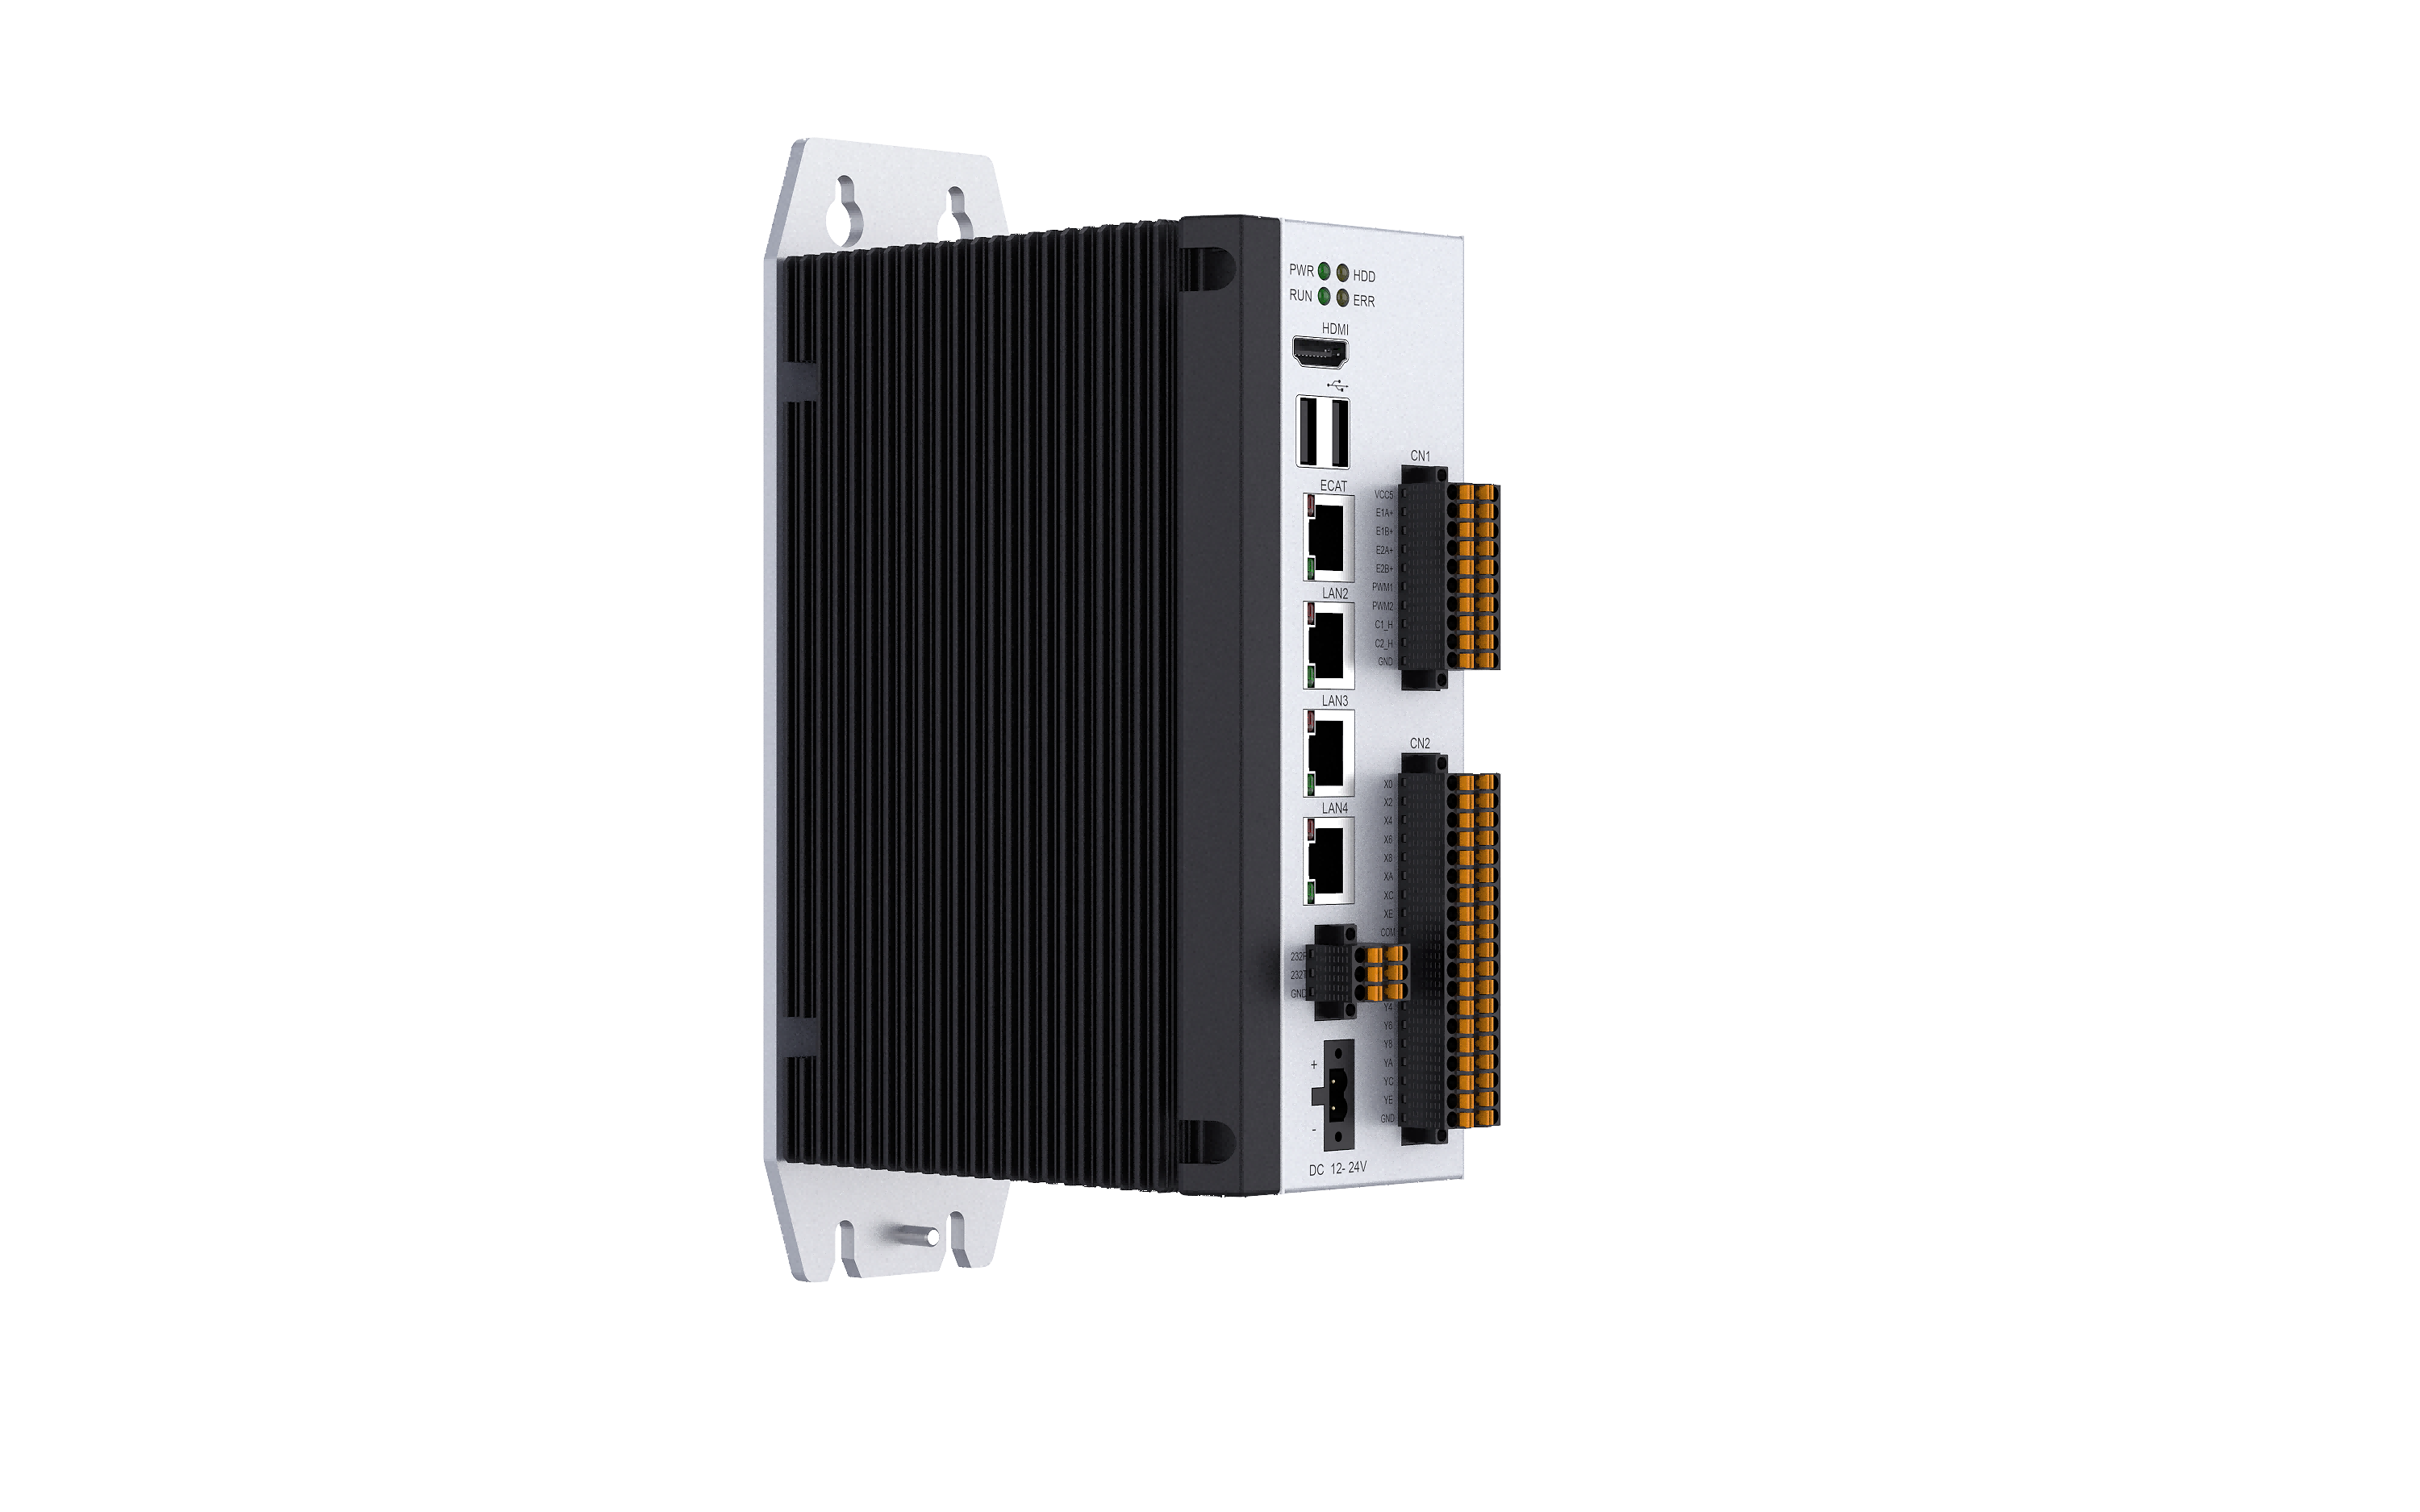
| Expansion interface | 1× EtherCAT, 1× Ethernet, 1× USB 3.0, 3× USB 2.0, 1× RS232, 1× RS485 |
| Programming method | Teach programming, offline programming, drag teaching |
| Real-time capability | IPC + X86 platform with RTOS; synchronized interpolation for up to 64 axes |
Technical extensions
Power supply: 24 VDC (±10%). Operating modes: teach, playback and remote. Optional T30 robot teach pendant: 8-inch TFT full touchscreen, Linux + QT. Built-in process packages include arc/TIG/laser/resistance welding, laser cutting, spraying, dispensing, palletizing and conveyor tracking.

 企业会员

