INSPIRE ROBOTS RH56DFX Robotic End Effector
型号:RH56DFX角色:english_official_product

INSPIRE ROBOTS RH56DFX Robotic End Effector

单价
面议
对比
询价暂无
浏览11
发货北京
品牌INSPIRE ROBOTS
过期长期有效
更新2026-10-12 12:16

详细说明

规格参数

Product specifications · 按产品分类标准字段展示
中英文标准字段
夹爪类型
Gripper type
Five-finger dexterous hand, RH56DFX family
额定负载
Rated payload
30 kg passive payload
夹持力
Grip force
Thumb fingertip force 15 N; four-finger fingertip force 10 N
产品型号
Product model
RH56DFX
手指数量
Number of fingers
5
重复定位精度
Repeatability
±0.20 mm
供电电压
Supply voltage
DC 12–48 V
通信协议
Communication protocol
RS485
重量
Weight
540 g (without wrist); 650 g (with wrist)
技术扩展参数 · Technical extension
产品型号
Product model
RH56DFX
末端类型
Gripper type
Five-finger dexterous robotic hand
承载能力
Passive payload
30 kg passive payload
指尖夹持力
Thumb fingertip force
15 N
手指数量
Finger count
5
重复定位精度
Repeatability
±0.20 mm
重量
Weight
540 g
通信协议
Communication
RS485
技术扩展参数
Technical extension
6 DOF; 12 joints; 0.50 N force resolution; thumb lateral rotation >65°; power-off self-locking
技术扩展参数
Technical extension parameters
Official table: RH56DFX-2L/2R (without wrist) and RH56DFXW-2L/2R (with wrist); 6 DOF / 6+2 DOF, 12 joints; quiescent current 0.09 A / 0.1 A at 24 V; peak current 2 A at 24 V; force resolution 0.50 N; thumb lateral rotation >65° at 107°/s; thumb flexion 70°/s; four-finger flexion 260°/s; wrist yaw ±27° and pitch ±22° on wrist variant; power-off self-locking.
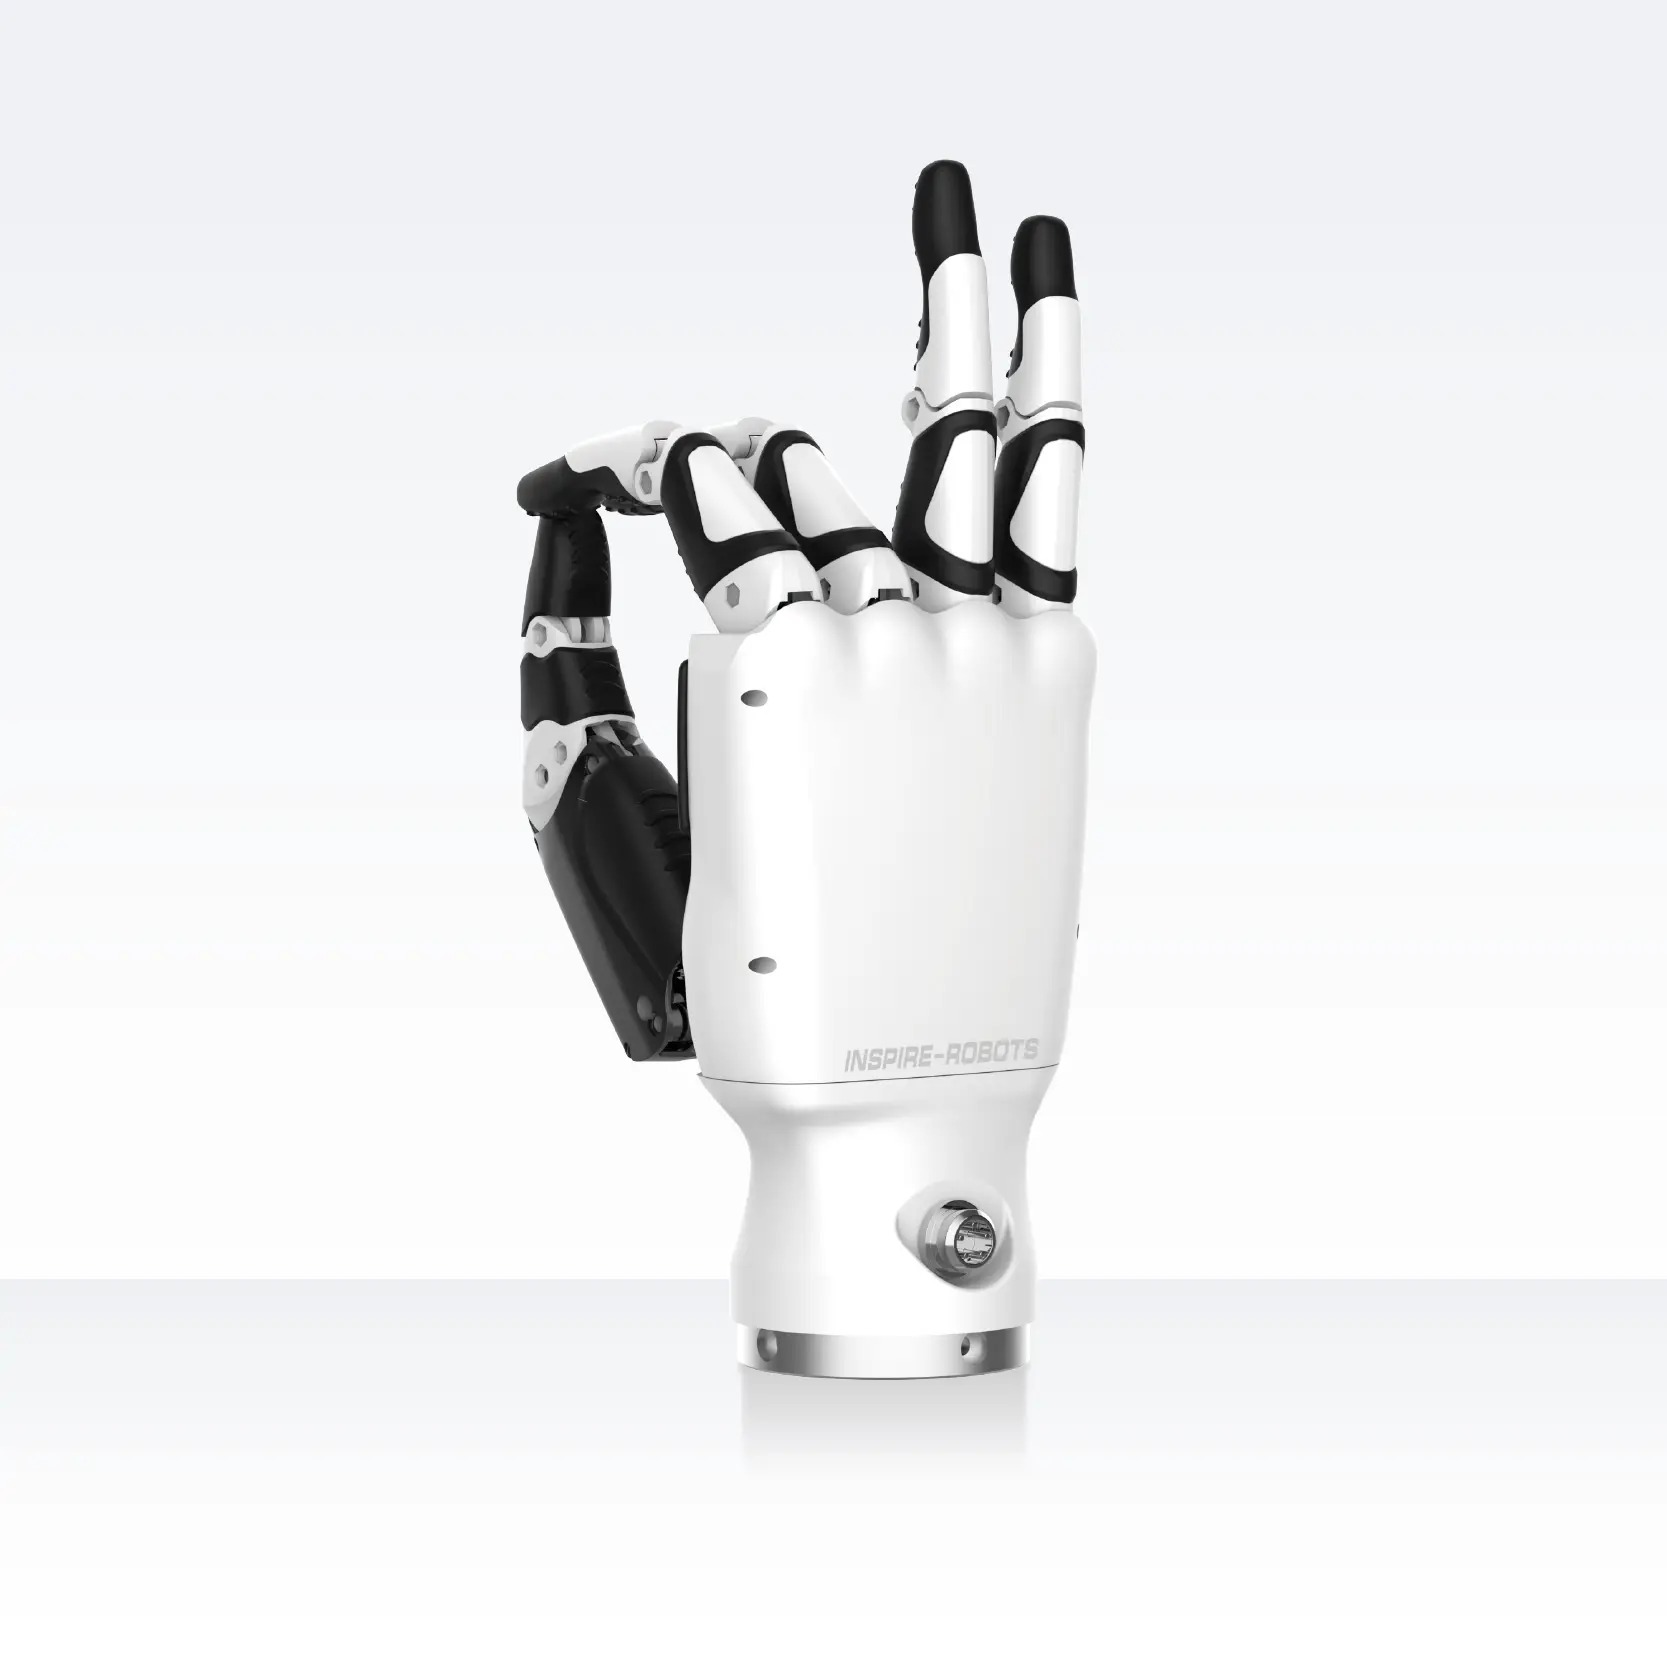
技术扩展参数
Technical extension parameters
Official table: RH56DFX-2L/2R (without wrist) and RH56DFXW-2L/2R (with wrist); 6 DOF / 6+2 DOF, 12 joints; quiescent current 0.09 A / 0.1 A at 24 V; peak current 2 A at 24 V; force resolution 0.50 N; thumb lateral rotation >65° at 107°/s; thumb flexion 70°/s; four-finger flexion 260°/s; wrist yaw ±27° and pitch ±22° on wrist variant; power-off self-locking.

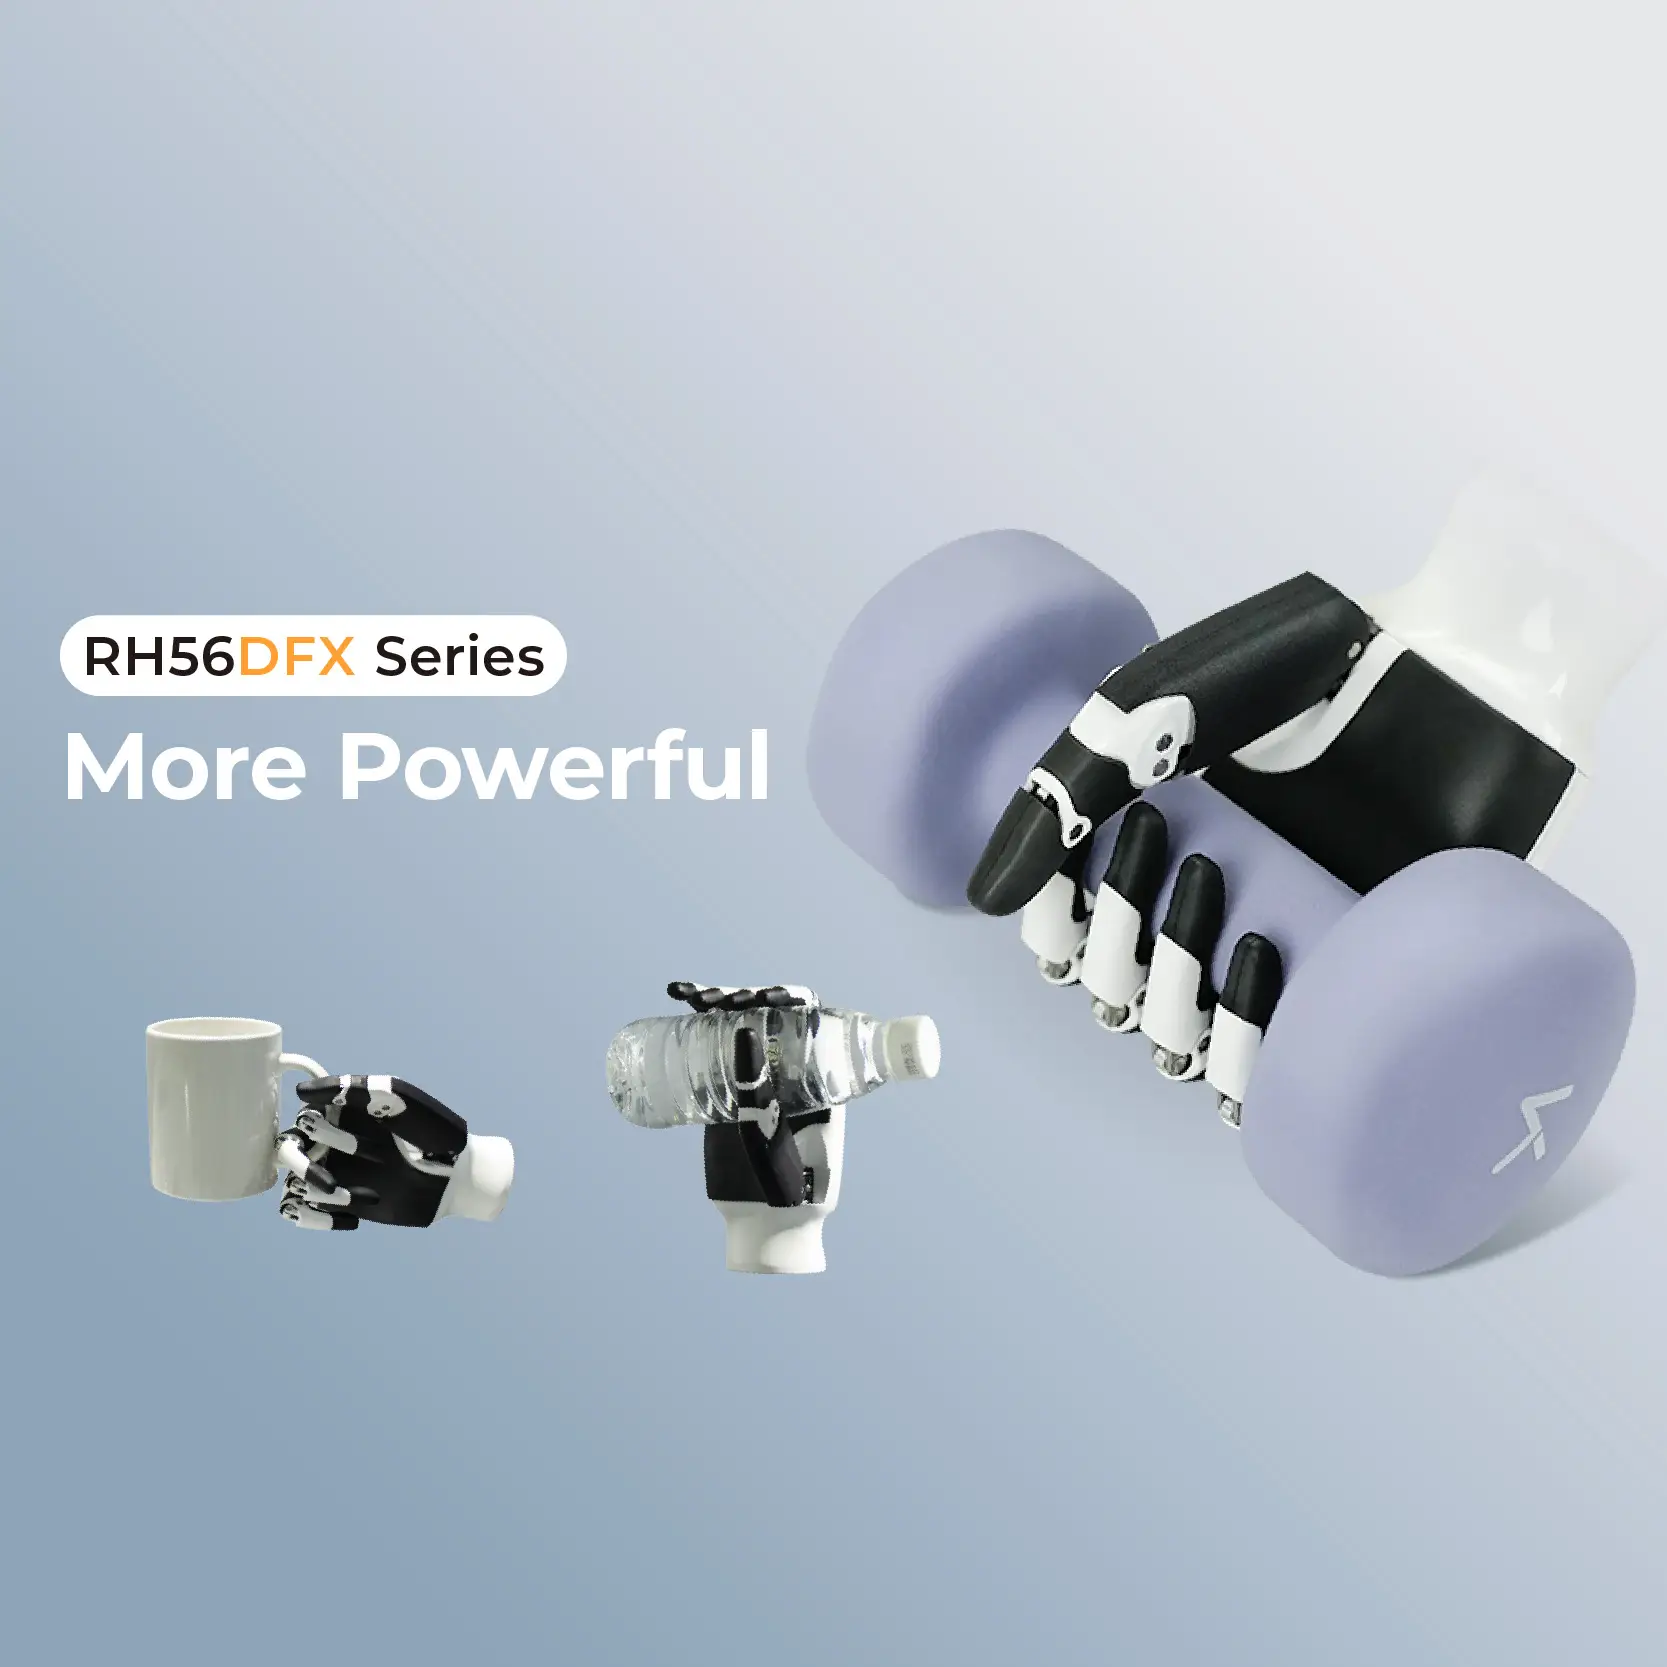
RH56DFX official English product information from INSPIRE ROBOTS.

Standard specifications

gripper typeFive-finger dexterous hand, RH56DFX family
grip force nThumb fingertip force 15 N; four-finger fingertip force 10 N
finger count5
repeatability mm±0.20 mm
weight kg540 g (without wrist); 650 g (with wrist)
communication protocolRS485
supply voltage vDC 12–48 V

Technical extensions

Official table: RH56DFX-2L/2R (without wrist) and RH56DFXW-2L/2R (with wrist); 6 DOF / 6+2 DOF, 12 joints; quiescent current 0.09 A / 0.1 A at 24 V; peak current 2 A at 24 V; force resolution 0.50 N; thumb lateral rotation >65° at 107°/s; thumb flexion 70°/s; four-finger flexion 260°/s; wrist yaw ±27° and pitch ±22° on wrist variant; power-off self-locking.
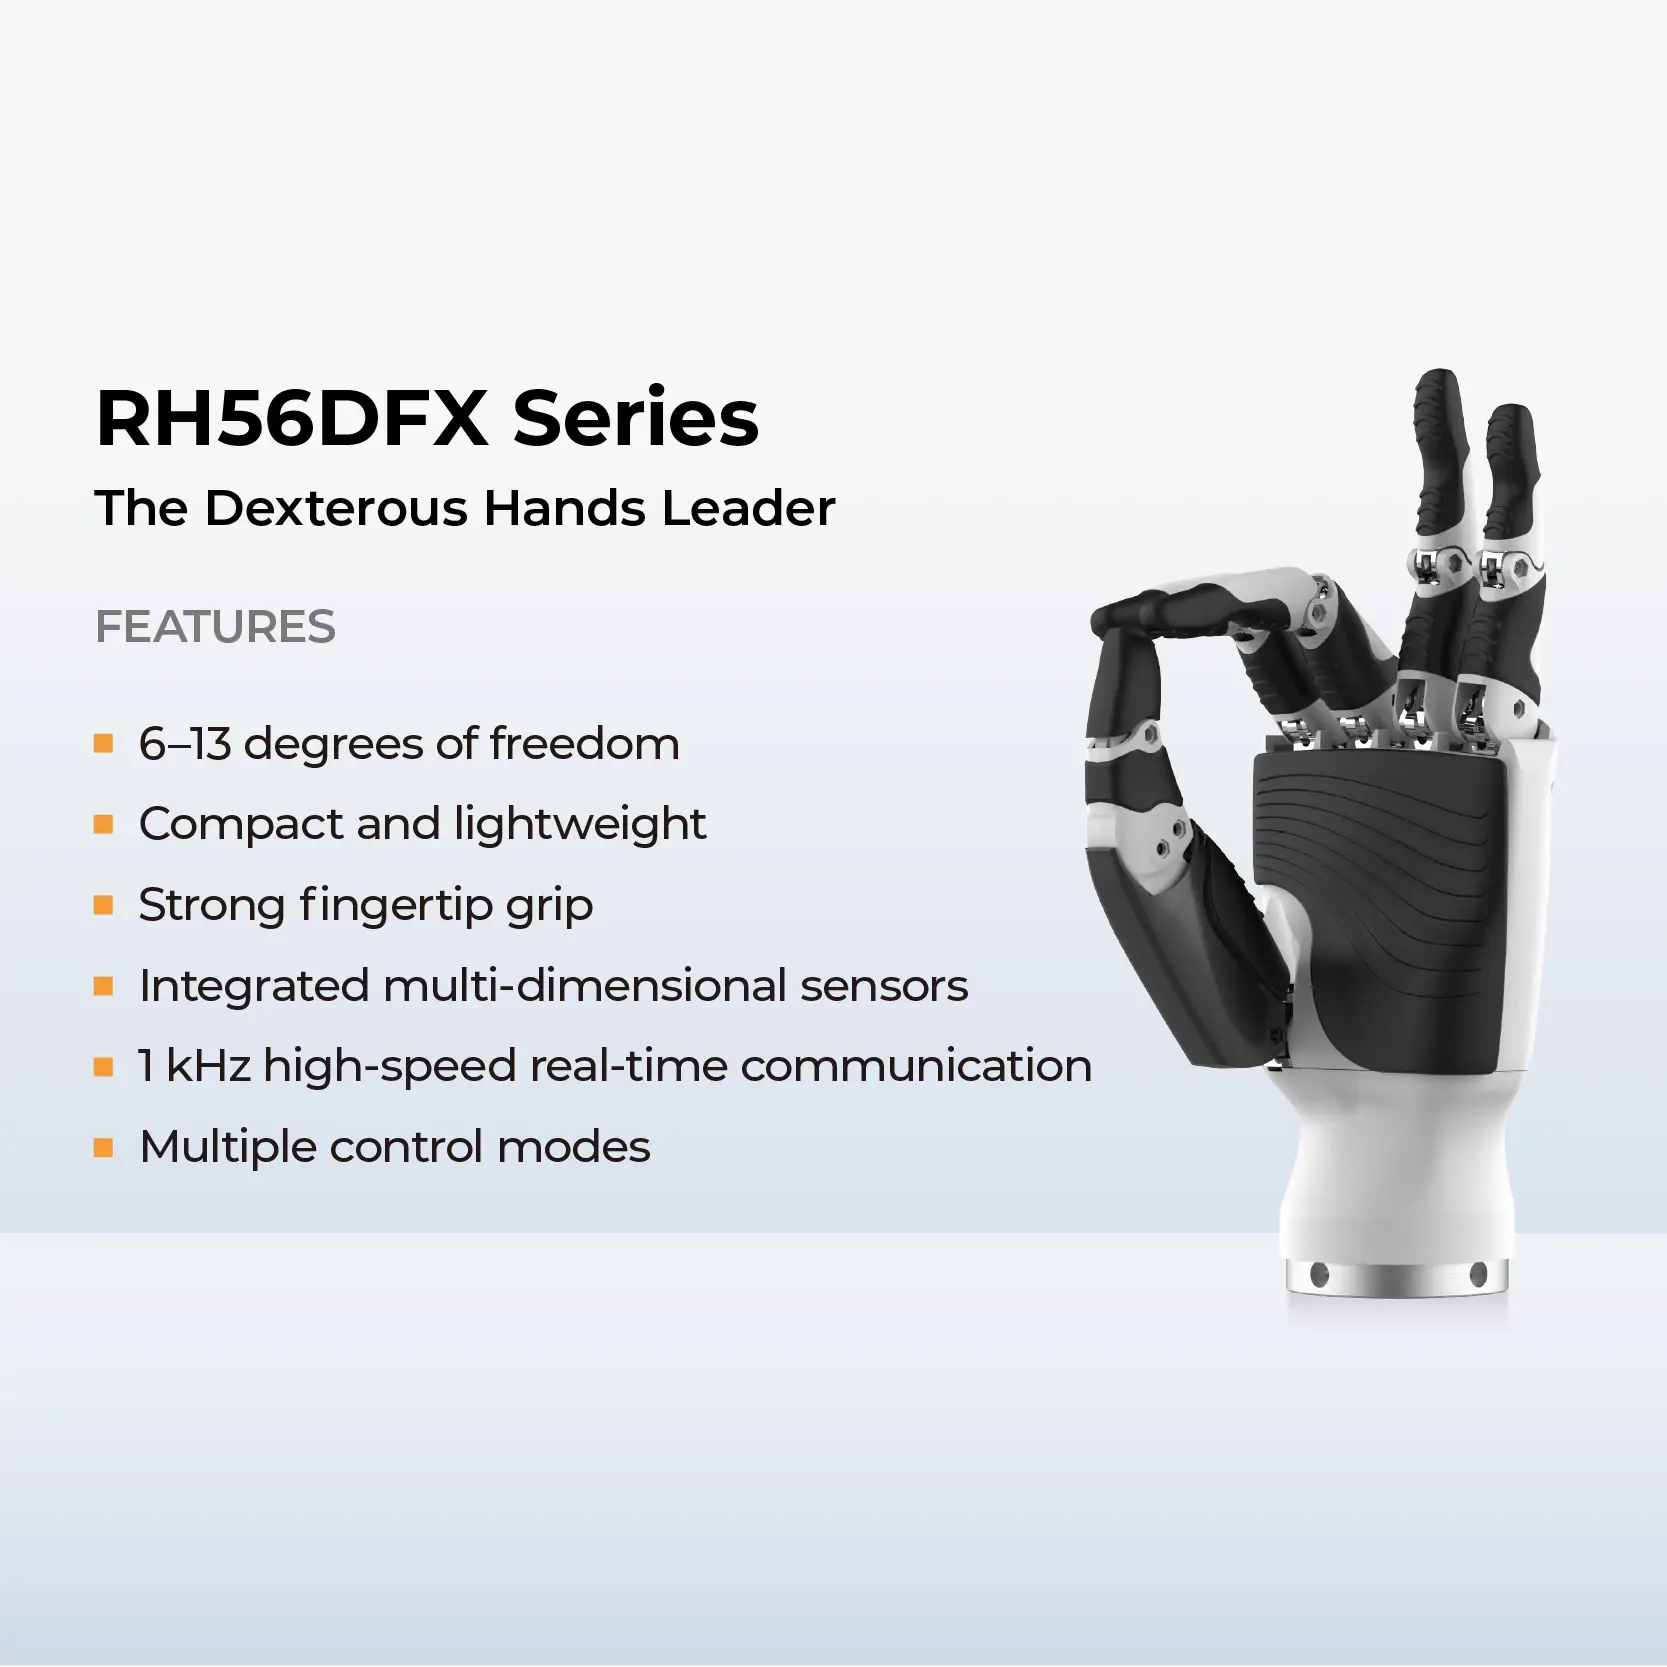
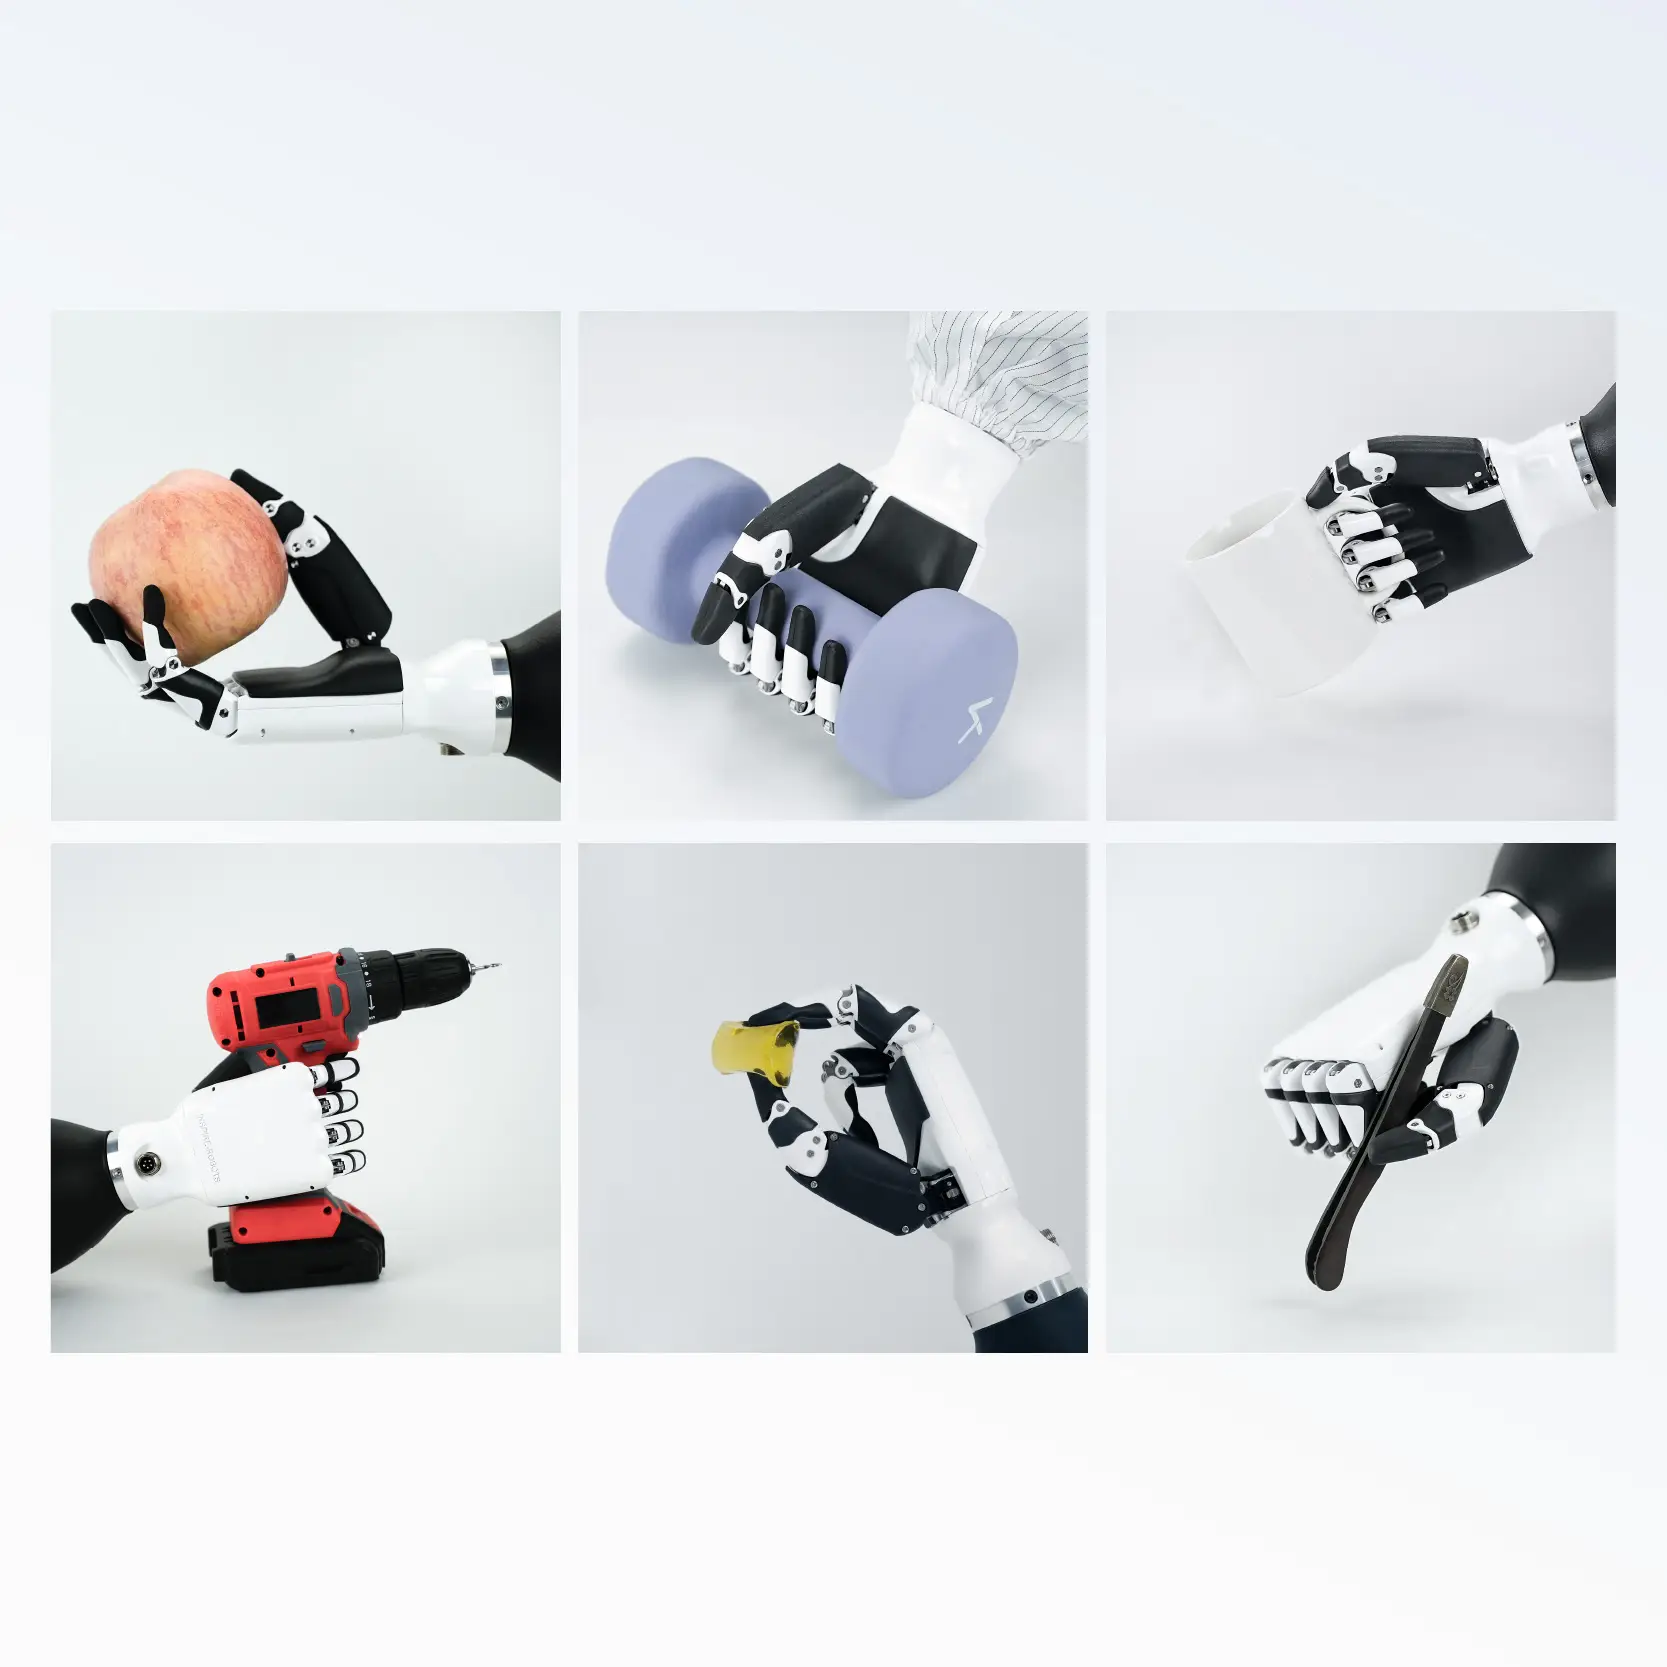
RH56DFX official product view 1

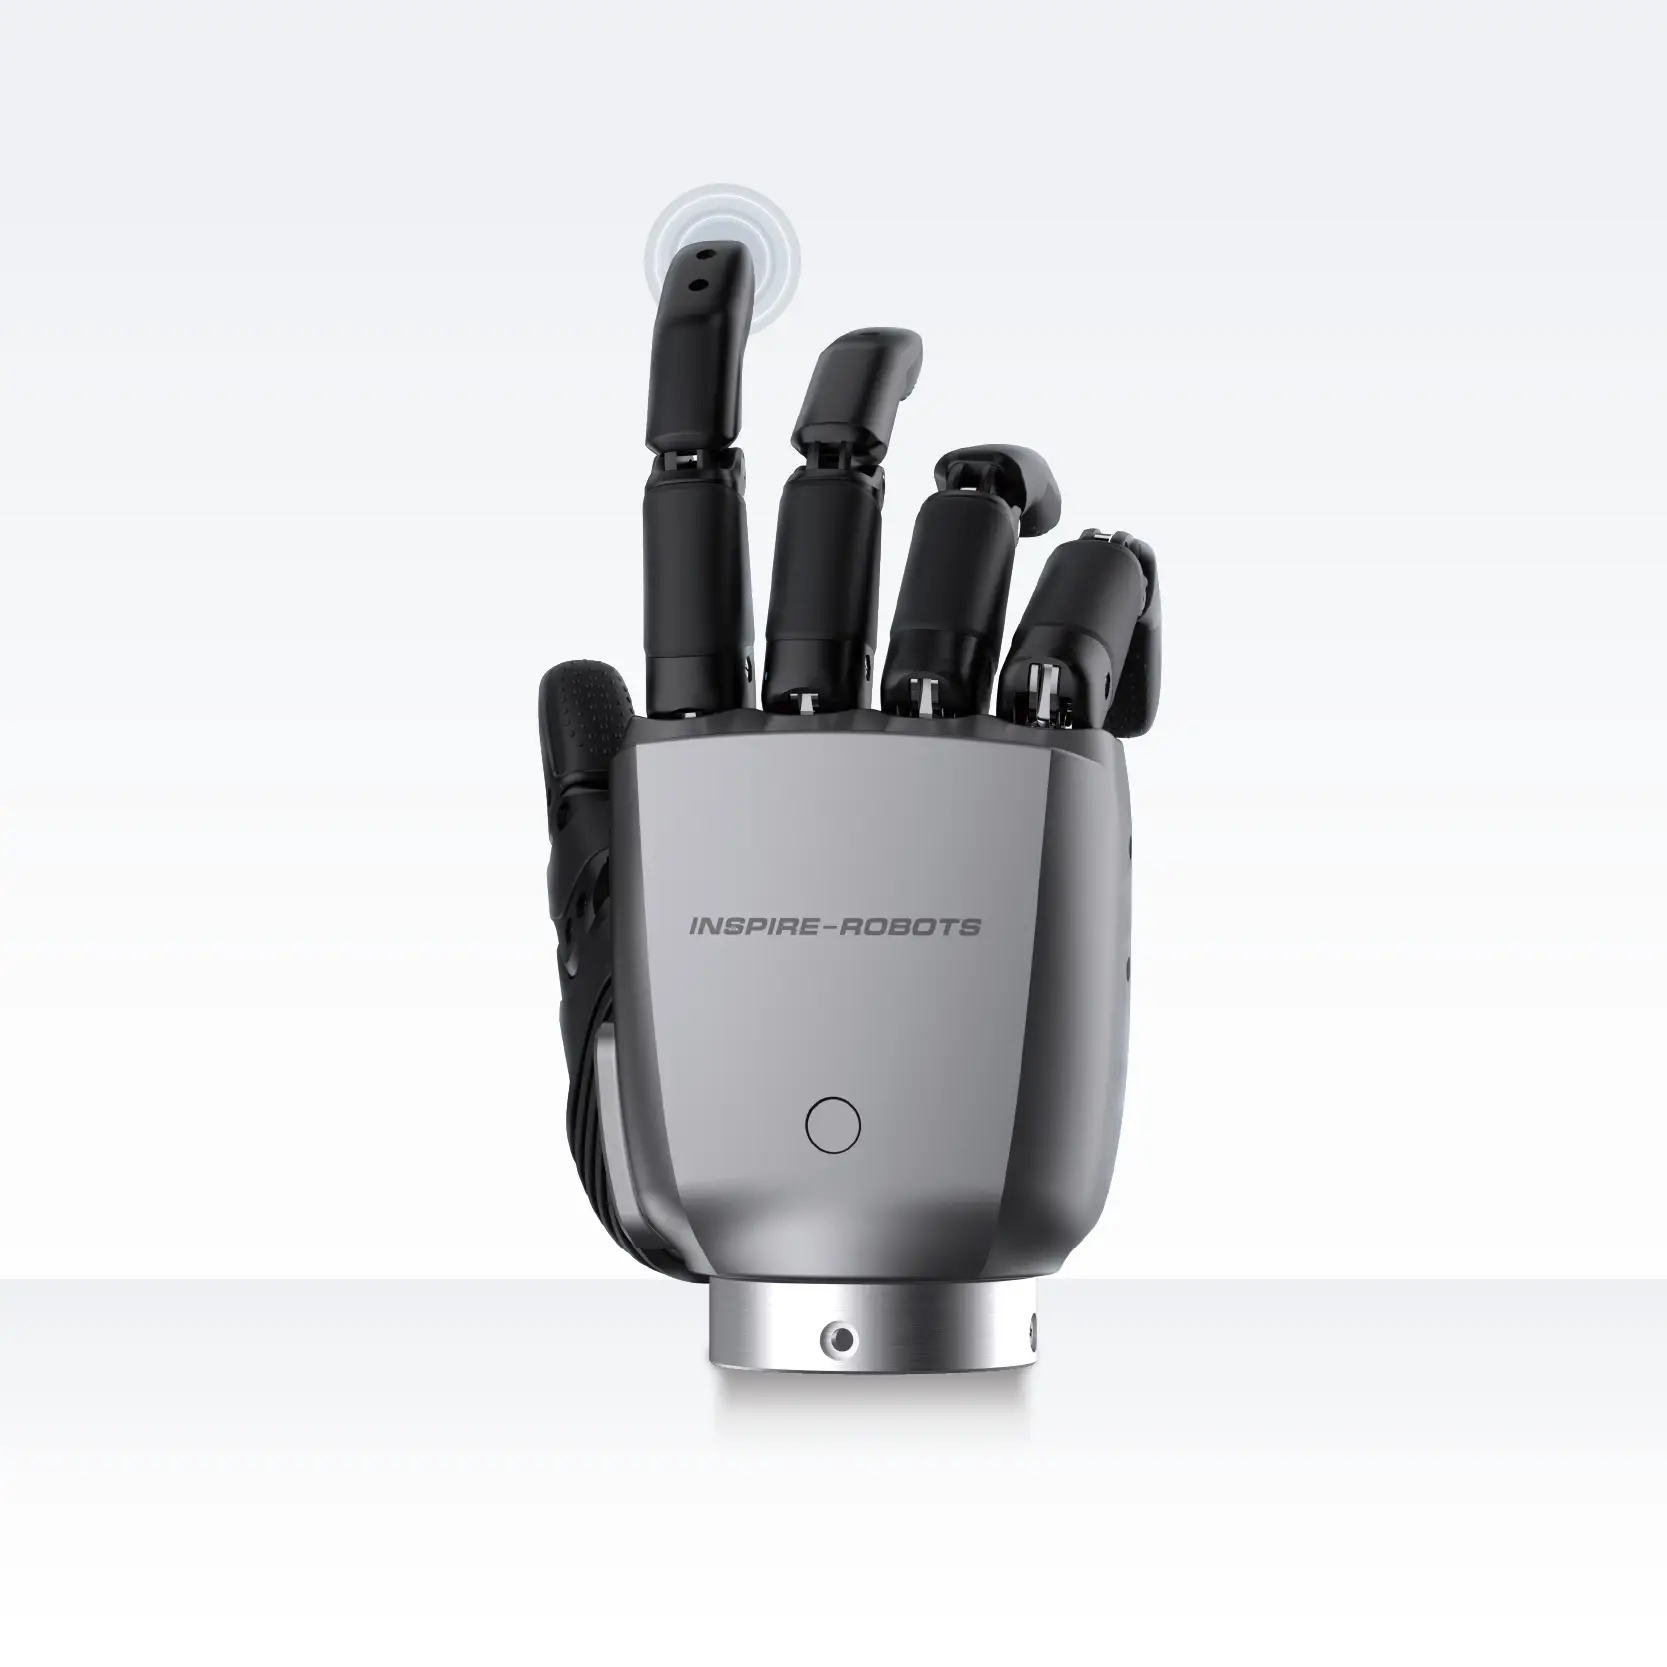
RH56DFX official product view 2

RH56DFX official product view 3

RH56DFX official product view 4

分享2

联系卖家

联系方式
加关注0

北京因时机器人科技有限公司

企业会员第1年
资料通过RoboInd企业数据导入认证
保证金未缴纳
  • 北京
  • 上次登录 06-15 00:28 •
Shopping Cart
0 new
购物车

当前购物车数量由 Destoon 实时读取

Cart Items
0
打开购物车时加载商品清单
Go to shopping cart 我的订单