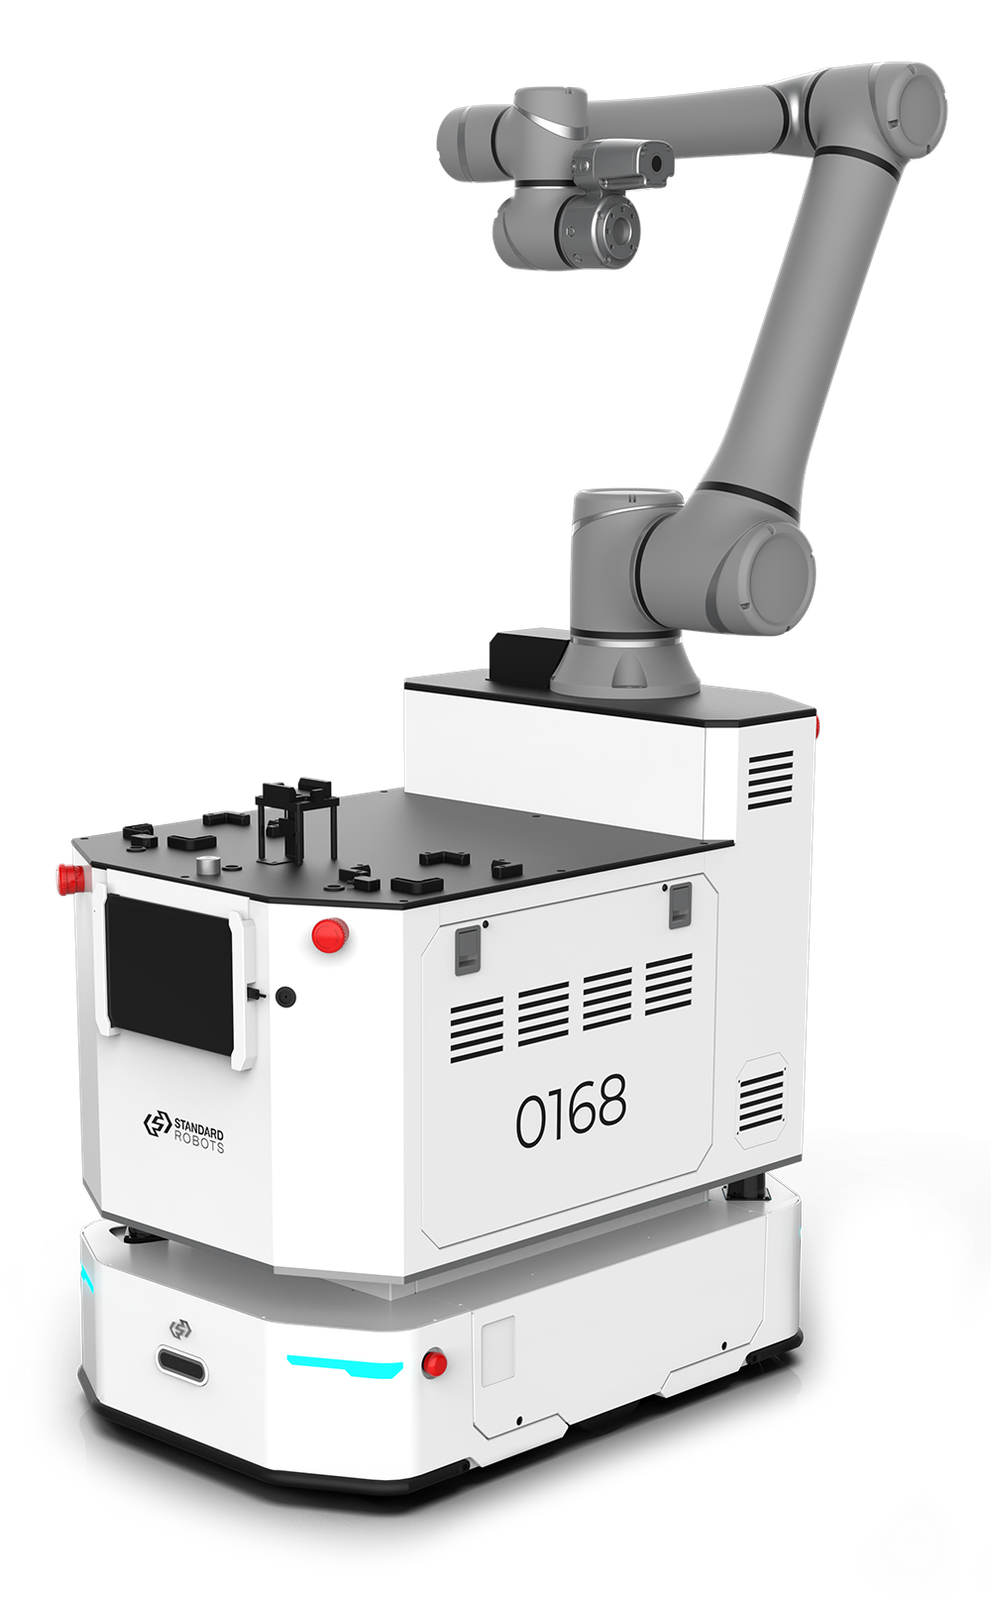
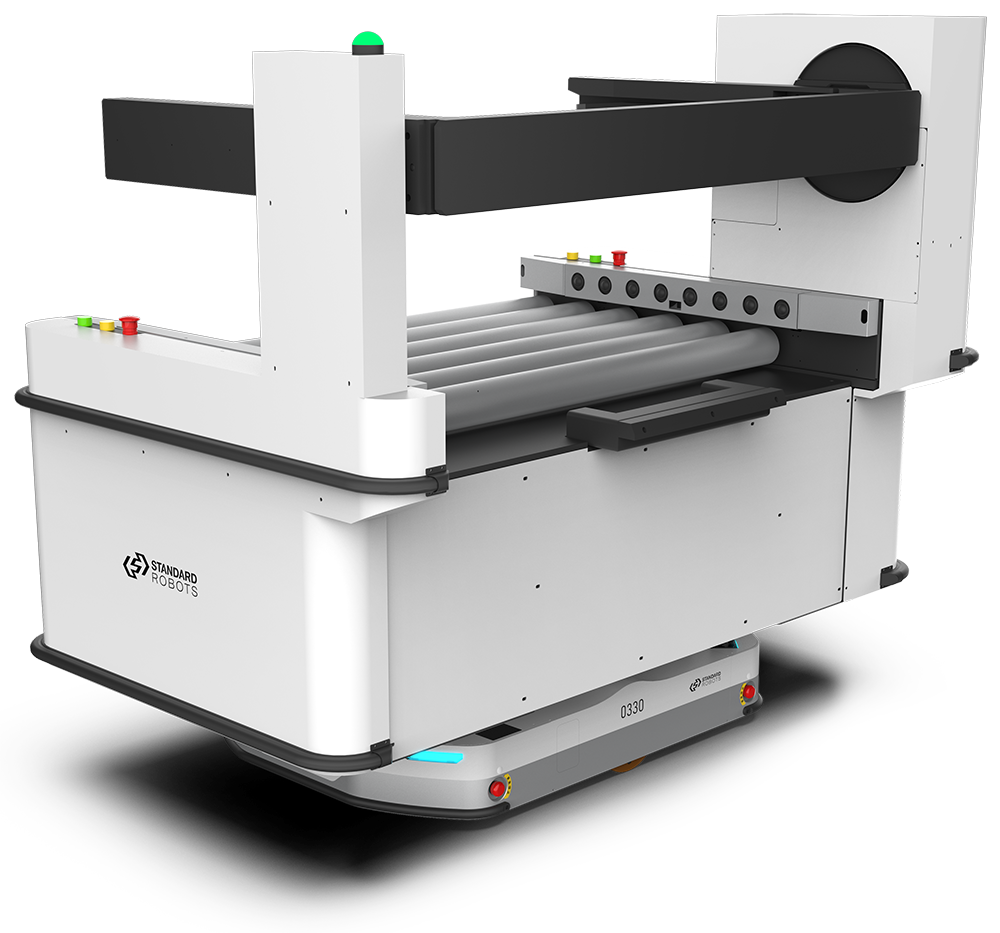
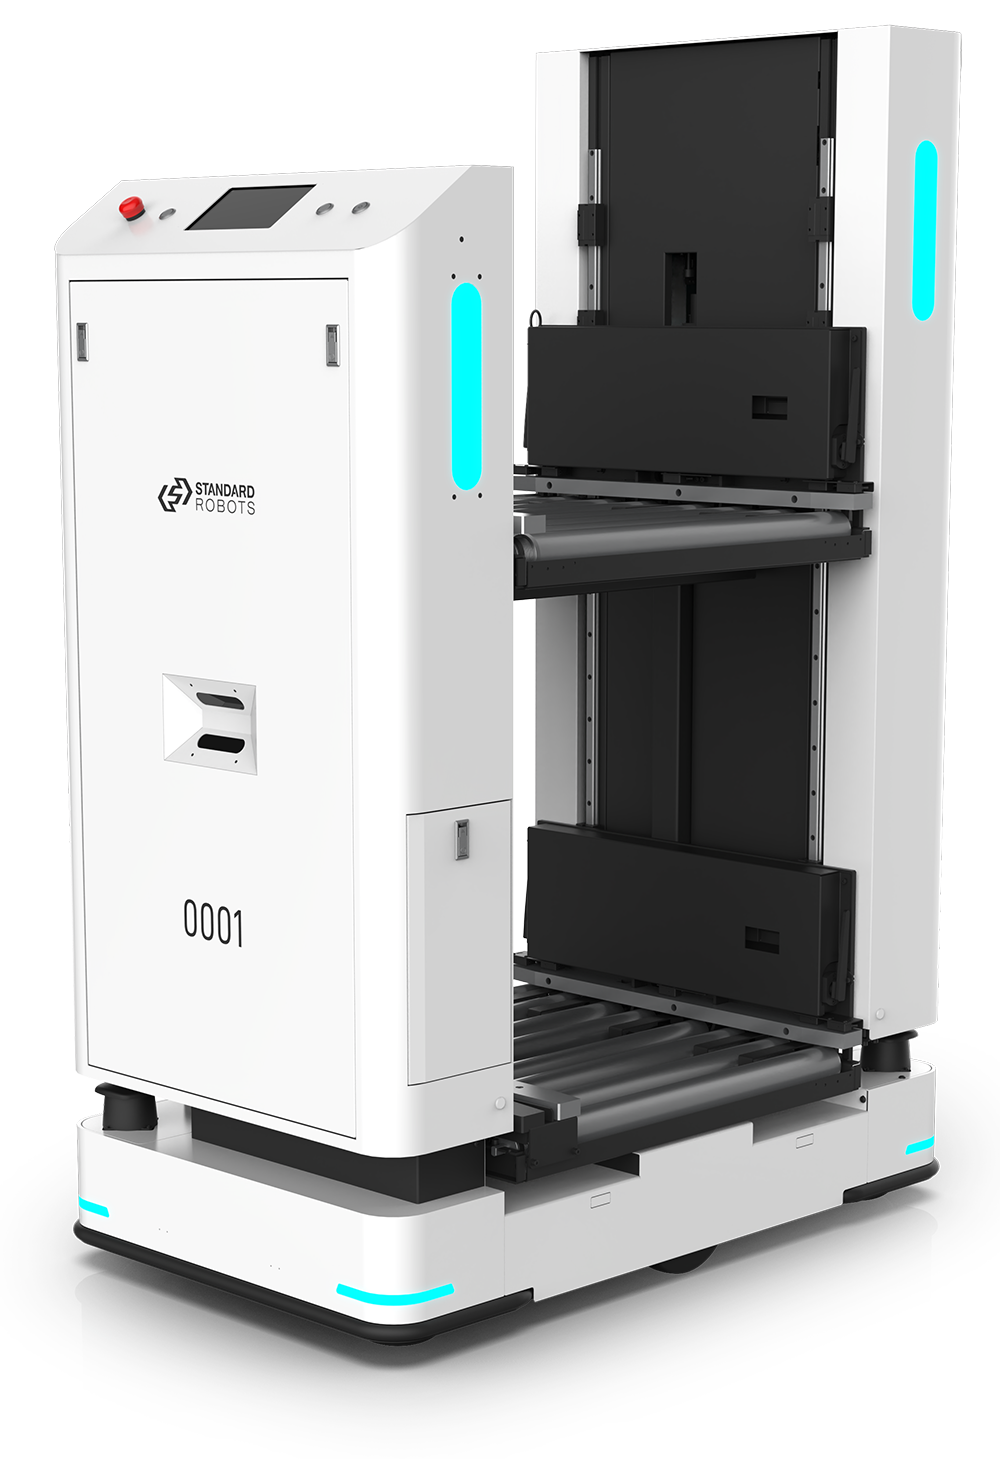
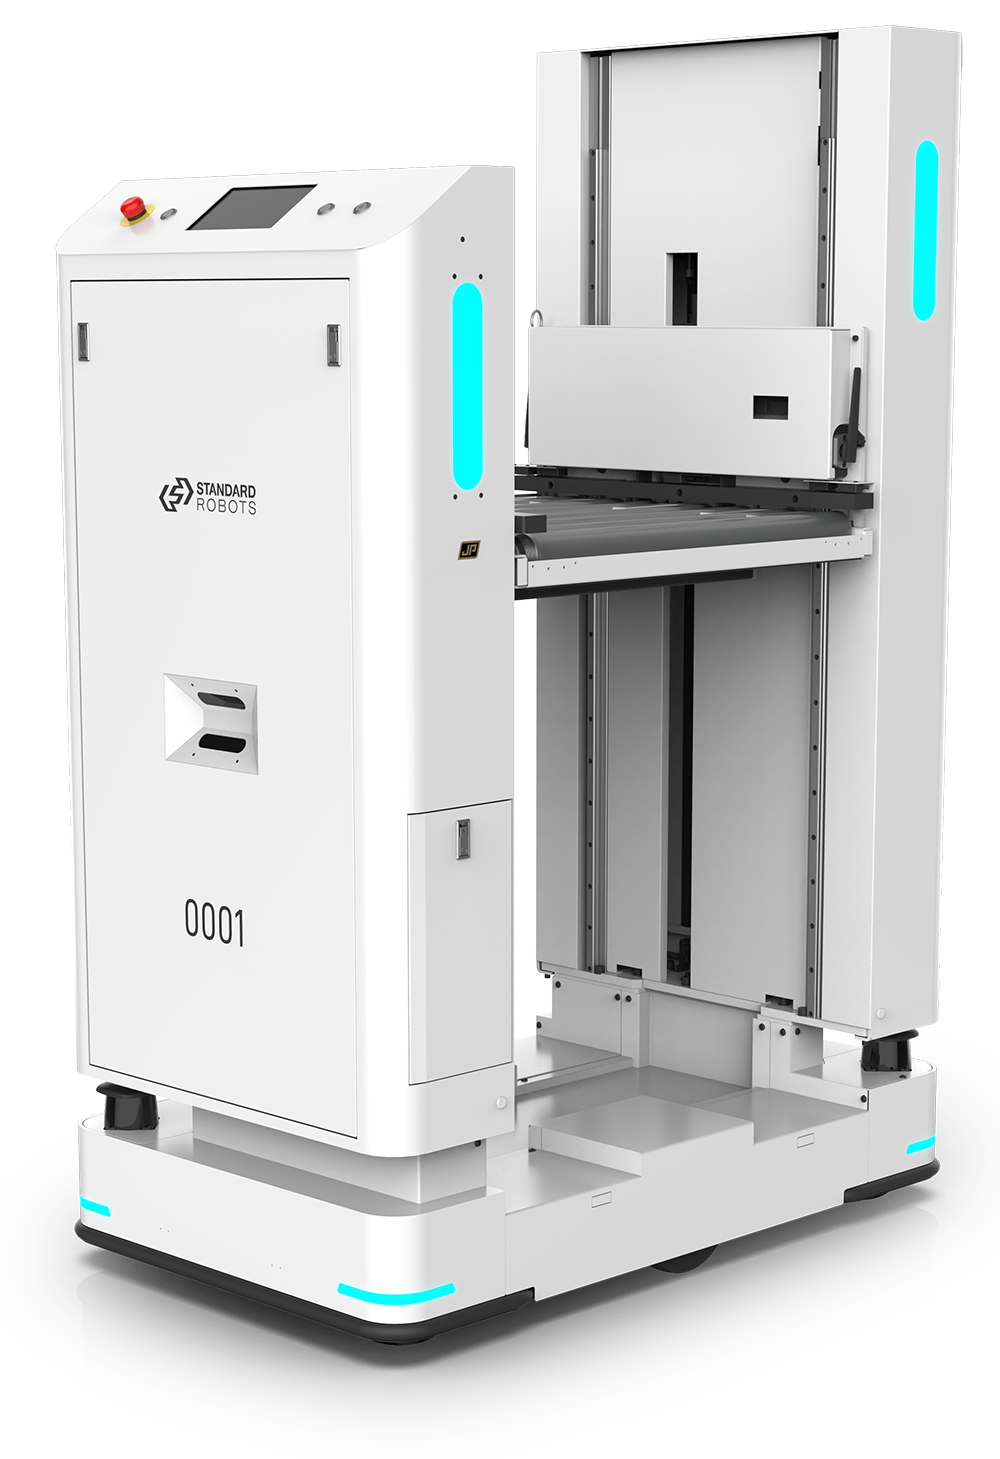
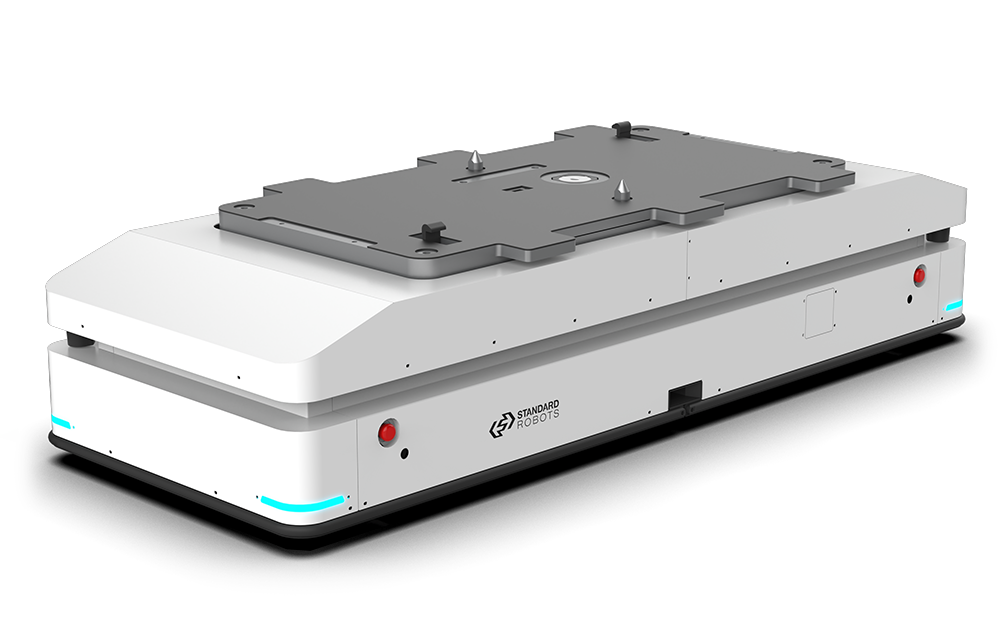
A differential drive embodied robot with a maximum end-effector load of 12kg, which addresses the automated handling of carriers such as cassettes in the packaging and testing processes of semiconductors. The composite robot completes the transportation of carriers like cassettes using the mechanical arm's gripping method, achieving full automation docking.
Specifications
| Product model | LINK-300EL-SRA-12 |
|---|---|
| Max. Speed | 1.5 m/s |
| Duration | 8 Hours |
| Payload | 12kg |
| Dimensions | 950*620*946mm |
| Rotating Radius | 500mm |
| 驱动形式 | Differential drive / omnidirectional platform as stated on official product category |
| 导航方式 | High-precision SLAM navigation |
| 通信协议 | Standard electrical interfaces and communication protocols |