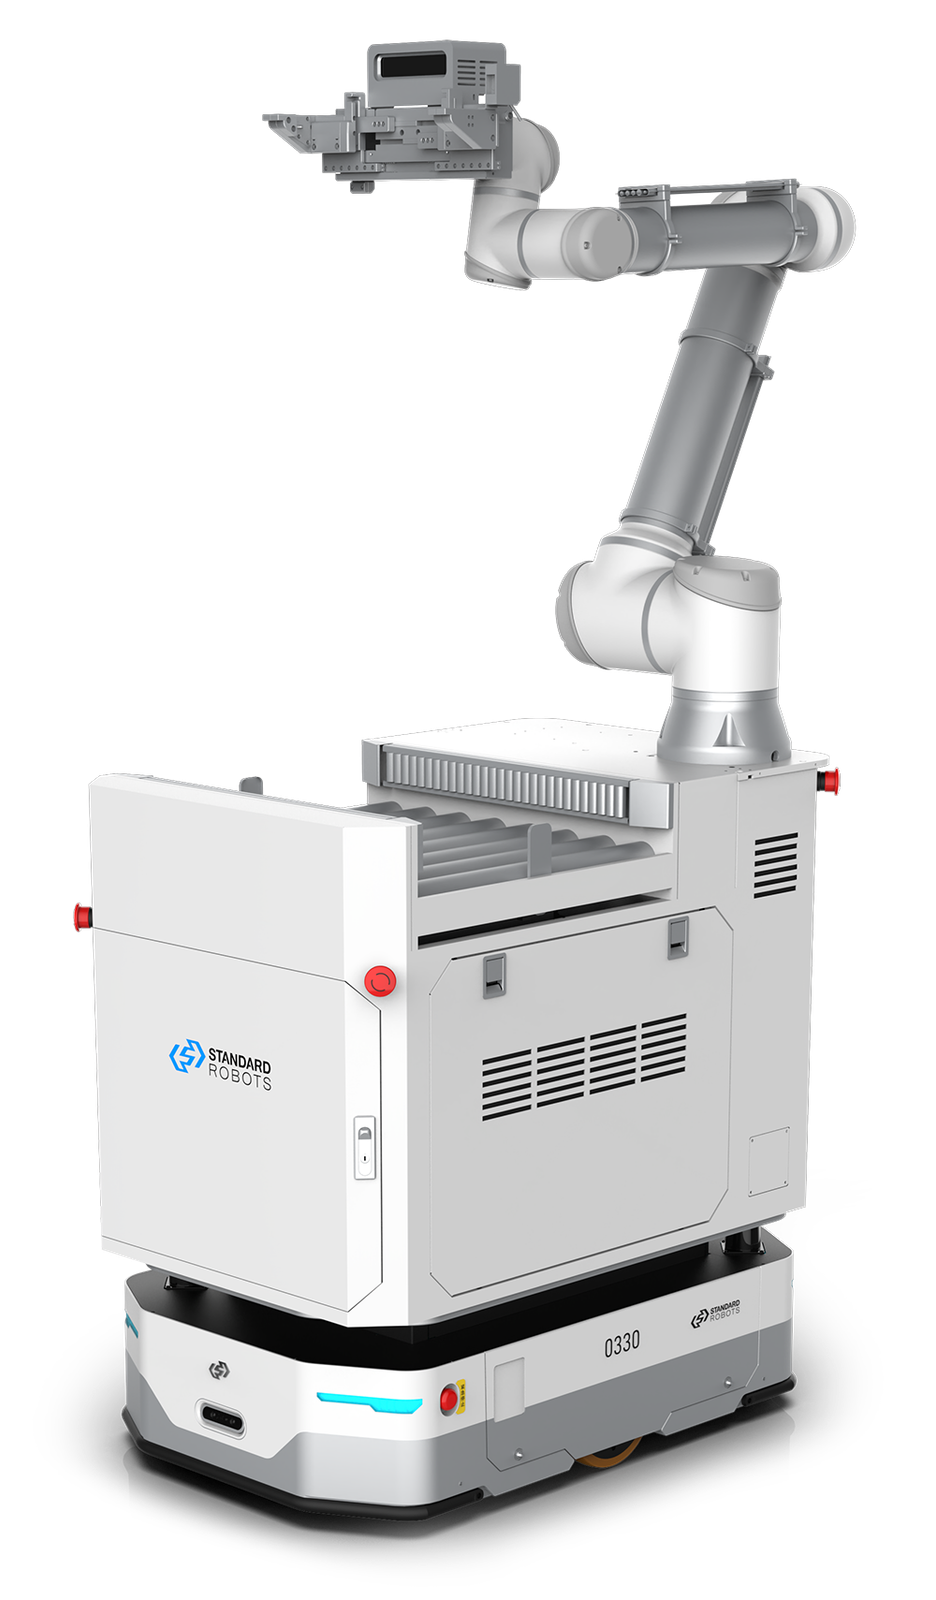
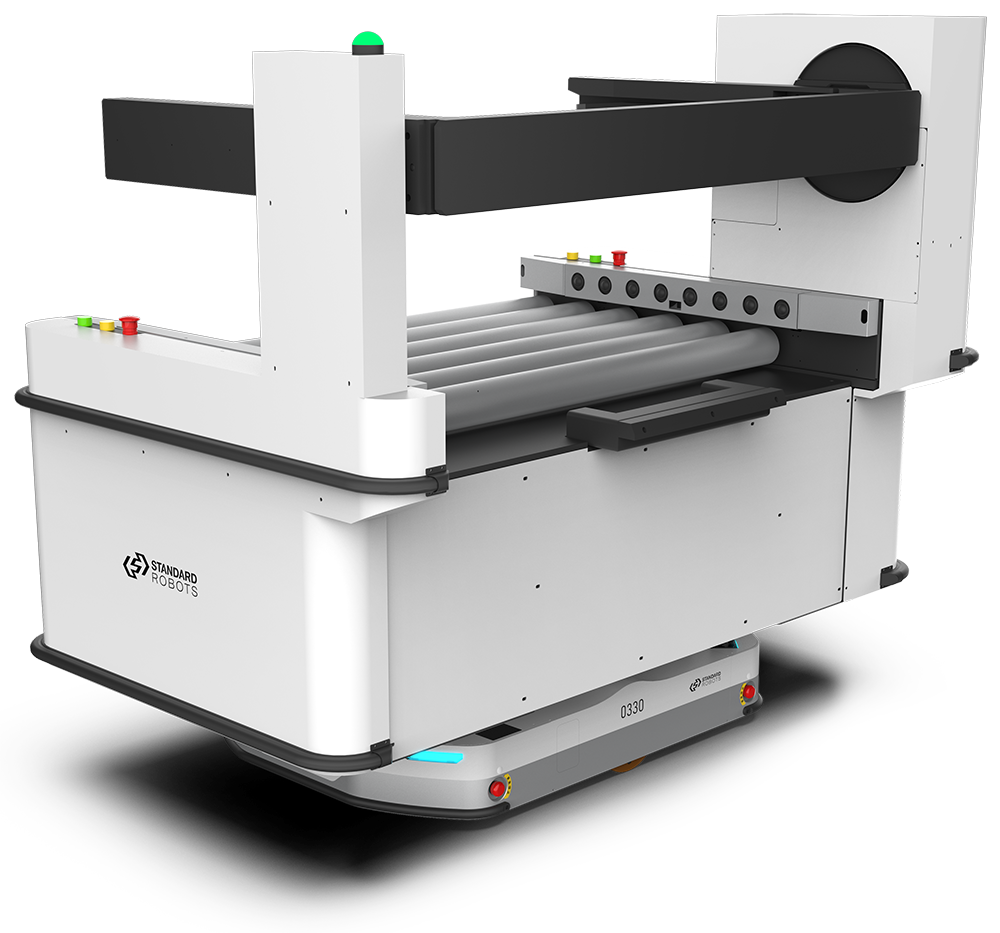
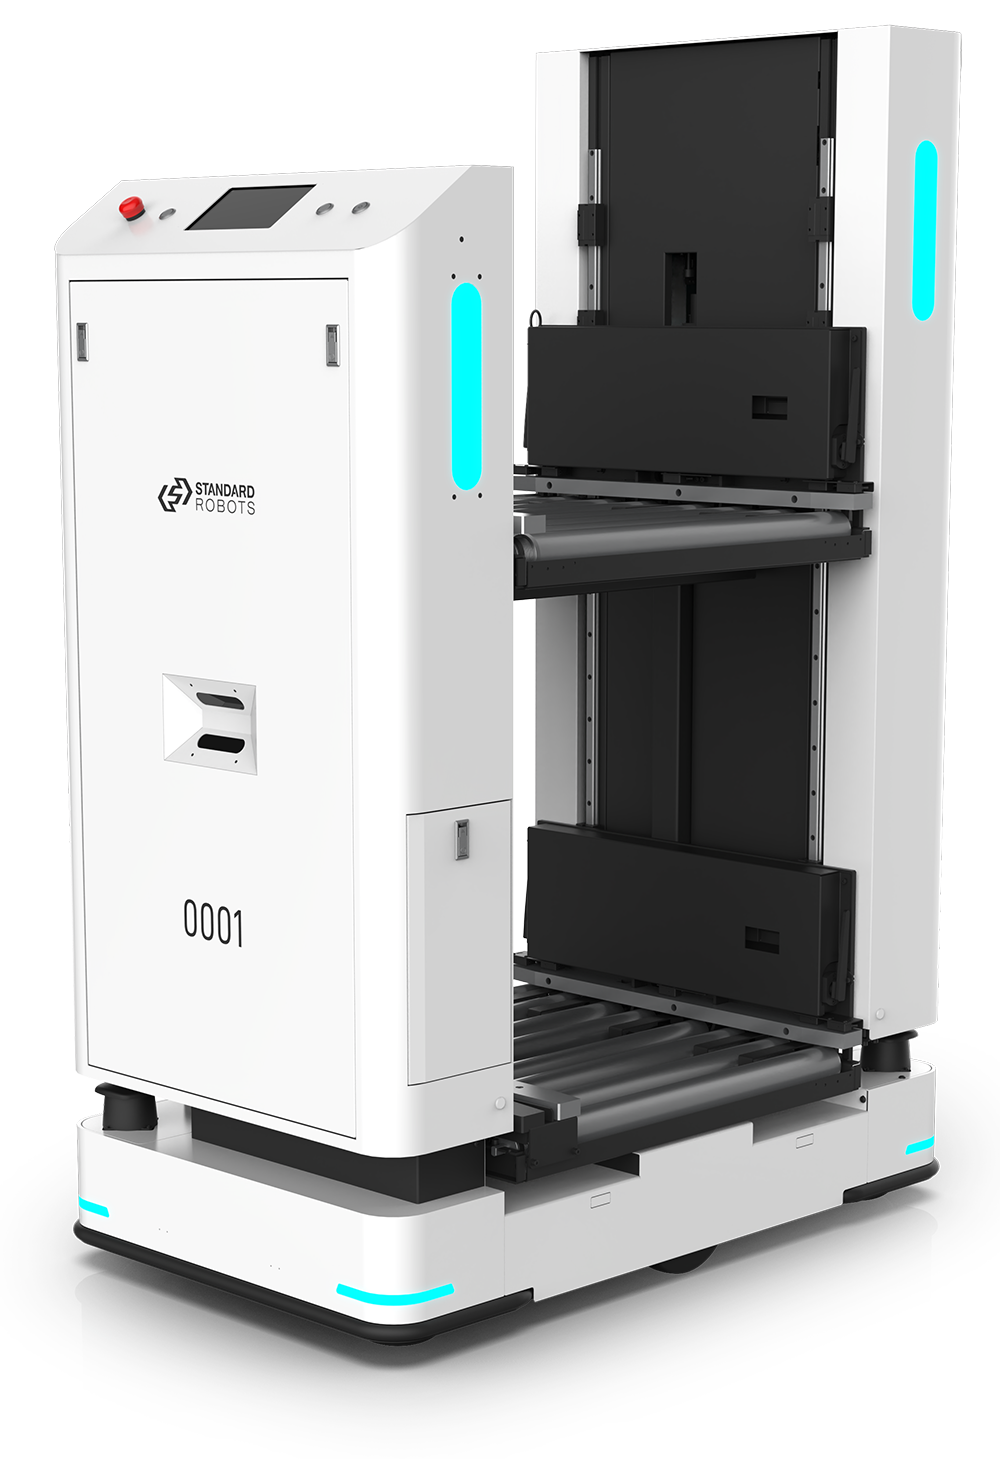
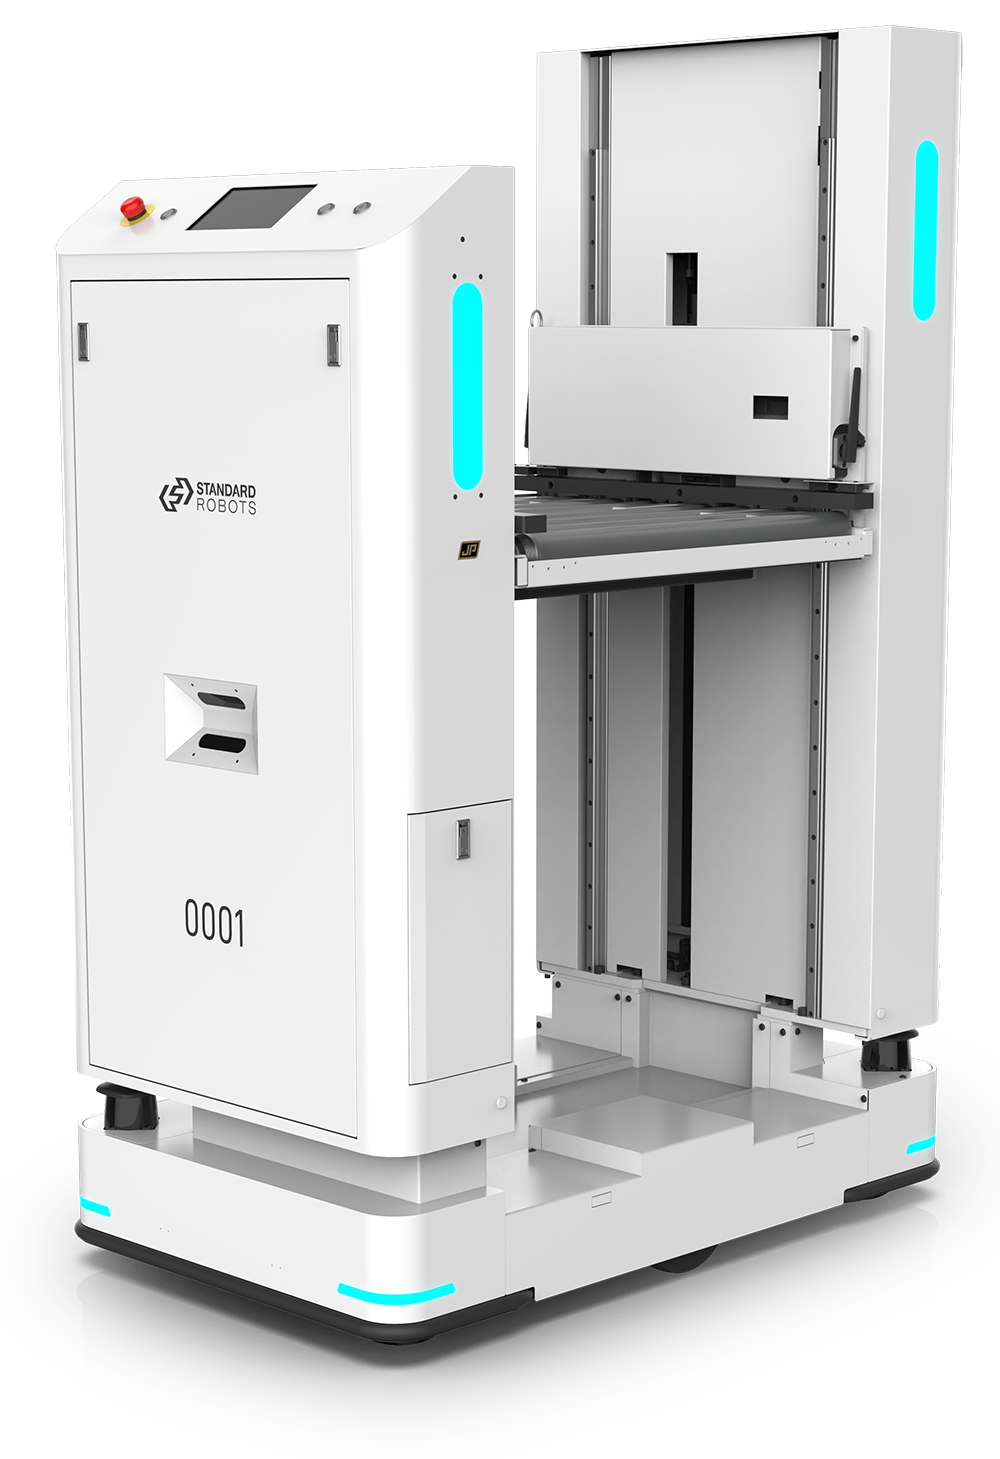
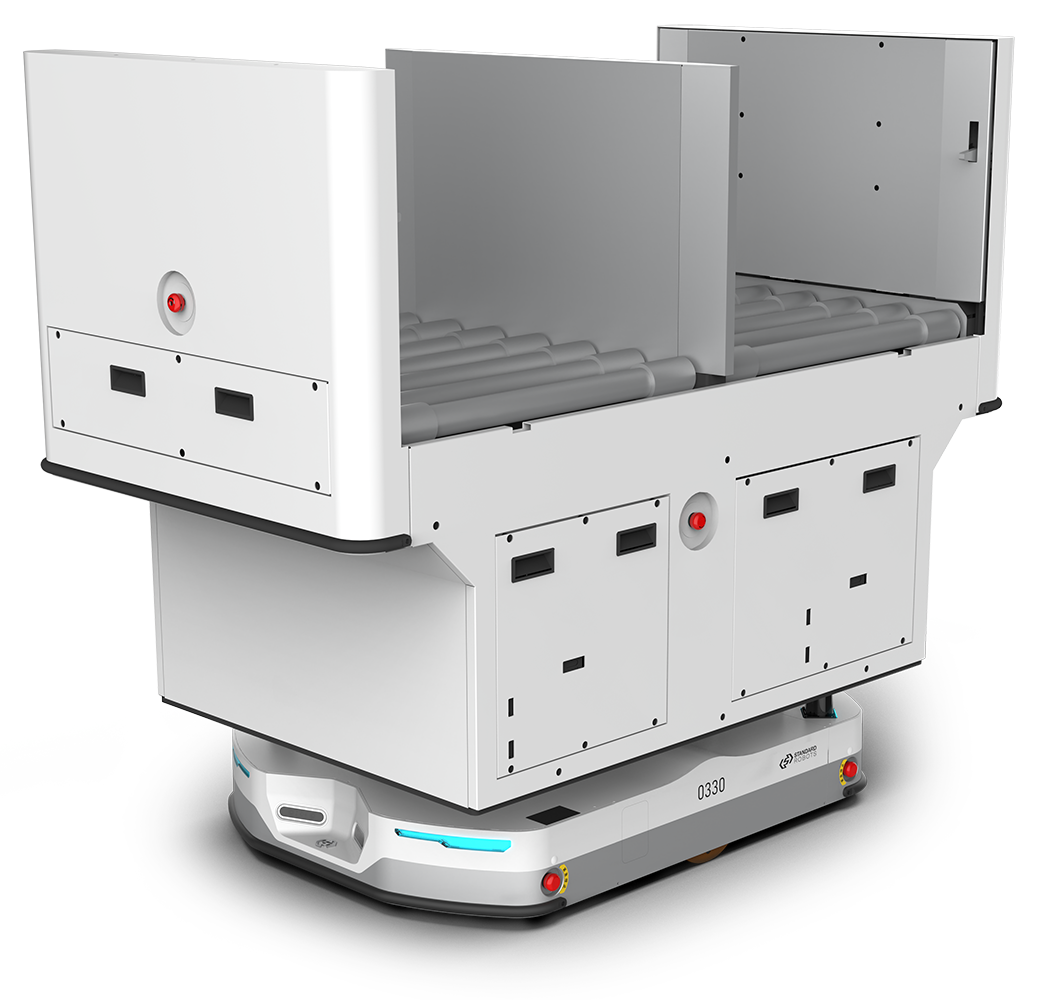
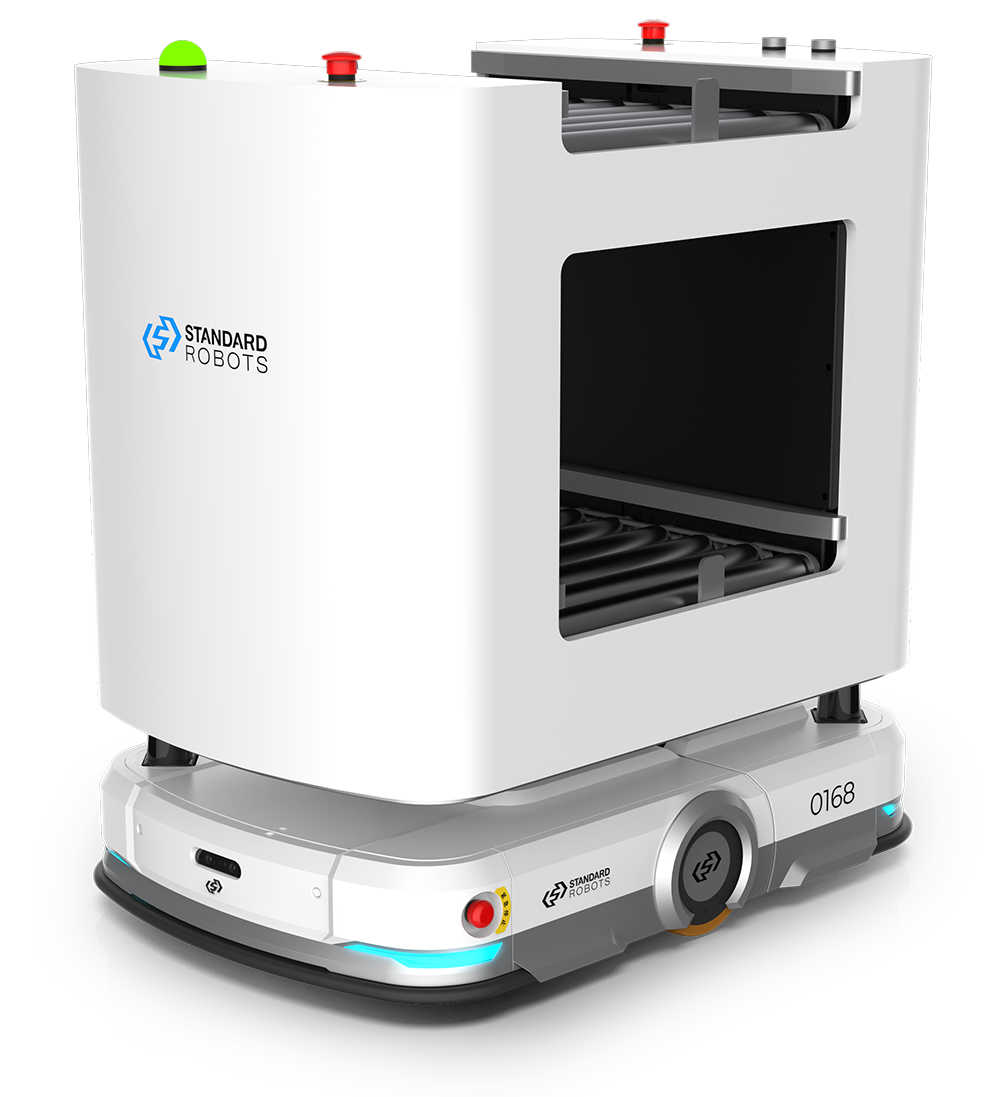
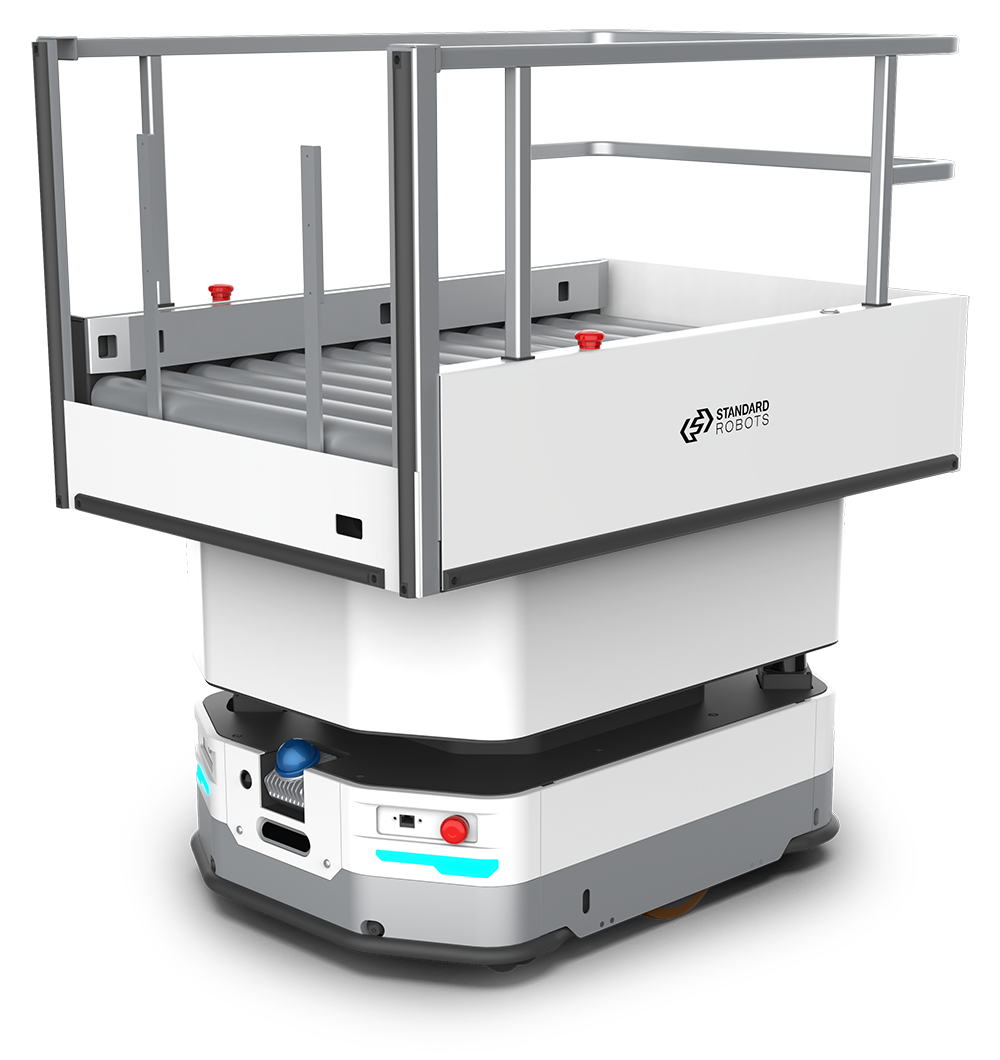
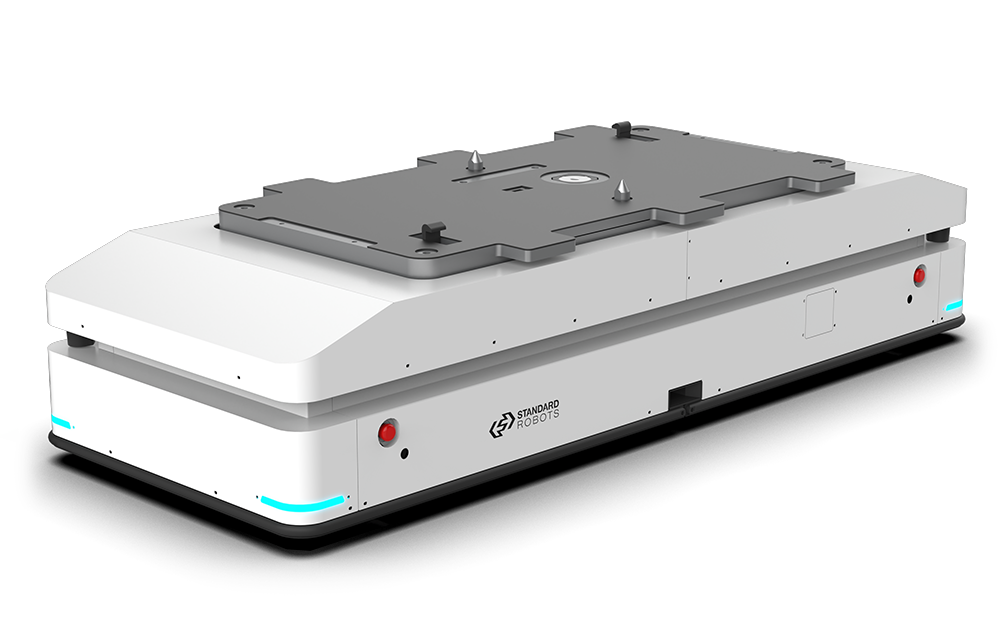
A 12kg maximum end-effector load differential drive transport embodied robot, which completes the transportation of cassettes, materials, fixtures, etc., using the mechanical arm's gripping method. It can also complete the pick-and-place of entire trays of materials through the transport module, improving the docking efficiency with raw material and finished product warehouses.
Specifications
| Product model | LINK-300EL-SRA-12-SRT |
|---|---|
| Max. Speed | 1.5 m/s |
| Duration | 8 Hours |
| Payload | 12kg |
| Dimensions | 1050*800*1050mm |
| Rotating Radius | 550mm |
| Drive configuration | differential |