

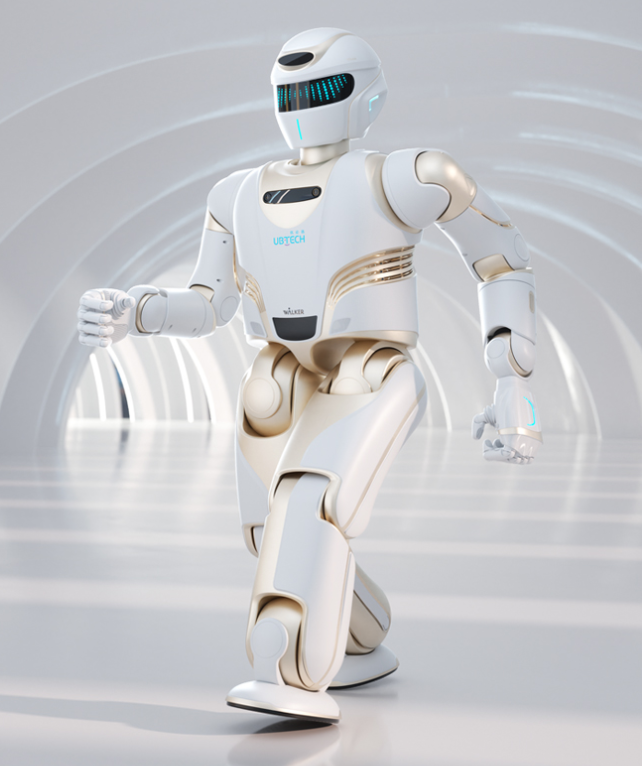
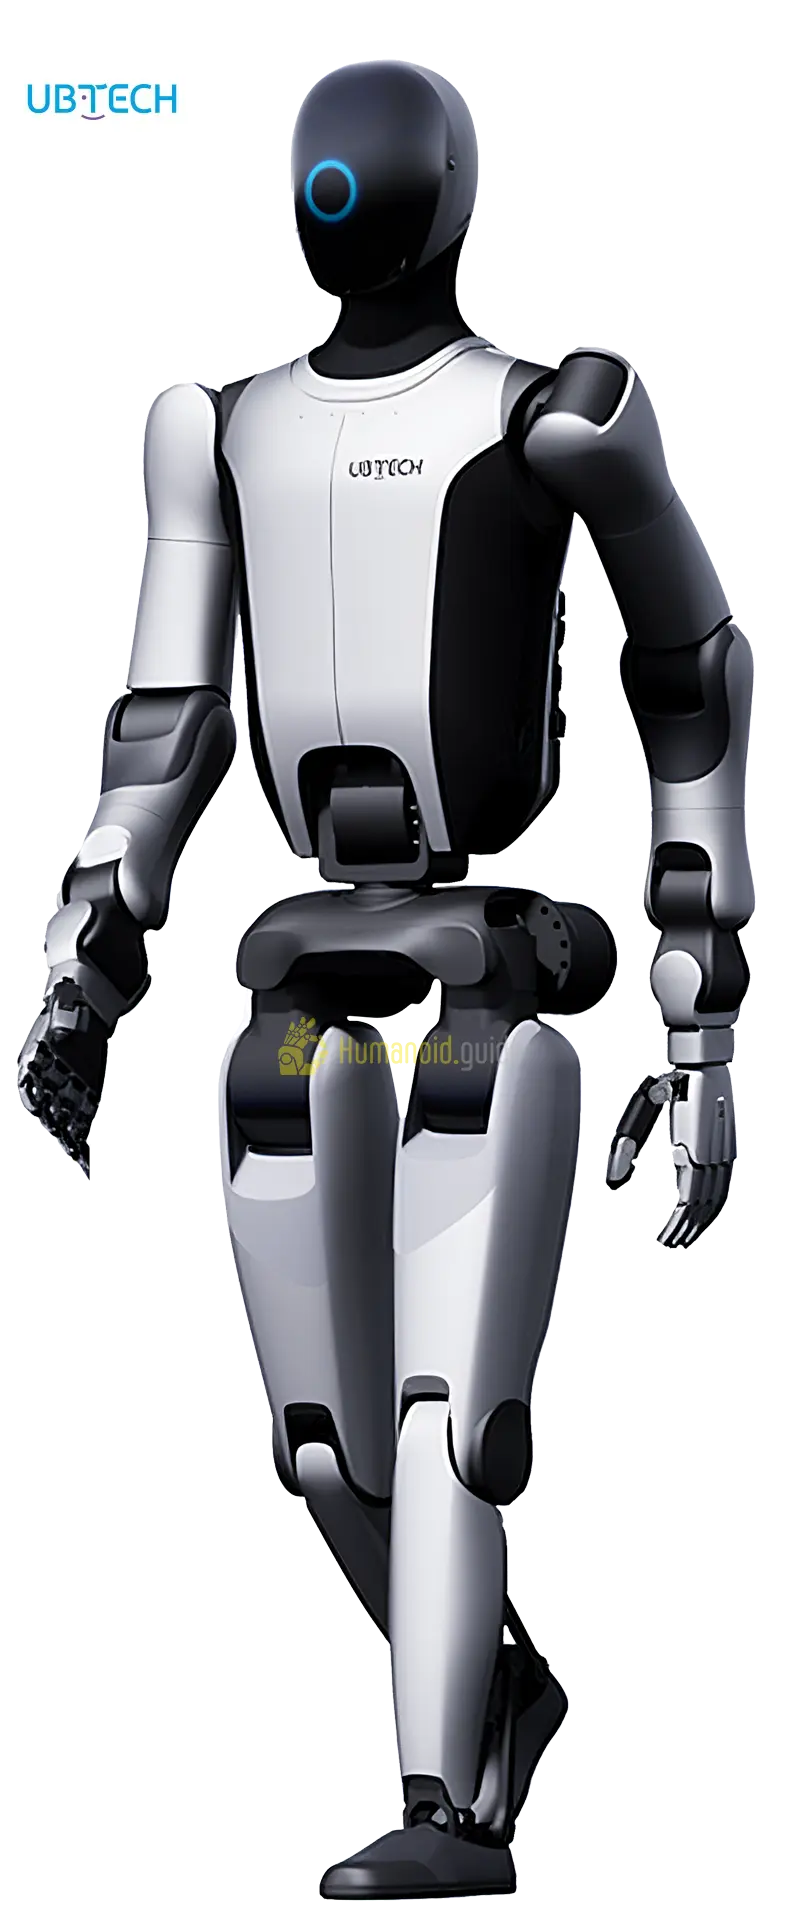
UBTECH Walker X is a humanoid service robot designed for household and office scenarios, with bipedal walking, autonomous navigation and hand-eye coordination.
Official product source: https://www.ubtrobot.com/en/humanoid/products/walker-x.
Specifications
| Overall height | 1300 mm |
|---|---|
| Robot weight | 63 kg |
| Degrees of freedom | 41 servo-joint degrees of freedom |
| Payload | Can carry 10 kg; can walk while carrying 3 kg in both hands |
| Arm payload | 1.5 kg per arm in extended state |
| Reach / workspace | 600 mm single-arm span |
| Product model | Walker X |
| Walking speed | 3 km/h (about 0.83 m/s) |
| Battery capacity | 546 Wh (54.6 V, 10 Ah) |
| Runtime | About 2 hours |
| Perception sensors | RGB_camera|depth_camera |
| Communication protocol | WiFi|EtherCAT |
| Hand degrees of freedom | 6-11_dof |
| Arm degrees of freedom | 7_dof_redundant |
| Leg degrees of freedom | 6_dof |
| Walking mode | full_bipedal |
Official UBTECH Walker X page lists 130 cm height, 63 kg weight, 41 servo joints (legs 6×2, arms 7×2, hands 6×2, neck 3), single-arm extended-state load 1.5 kg, single-arm span 600 mm, 3 km/h maximum walking speed, 20° slope capability, 15 cm step capability, 10 cm localization accuracy, and about 2 hours use time with 54.6 V / 10 Ah battery. The page also says it can carry 10 kg or walk with 3 kg in both hands.
 企业会员

