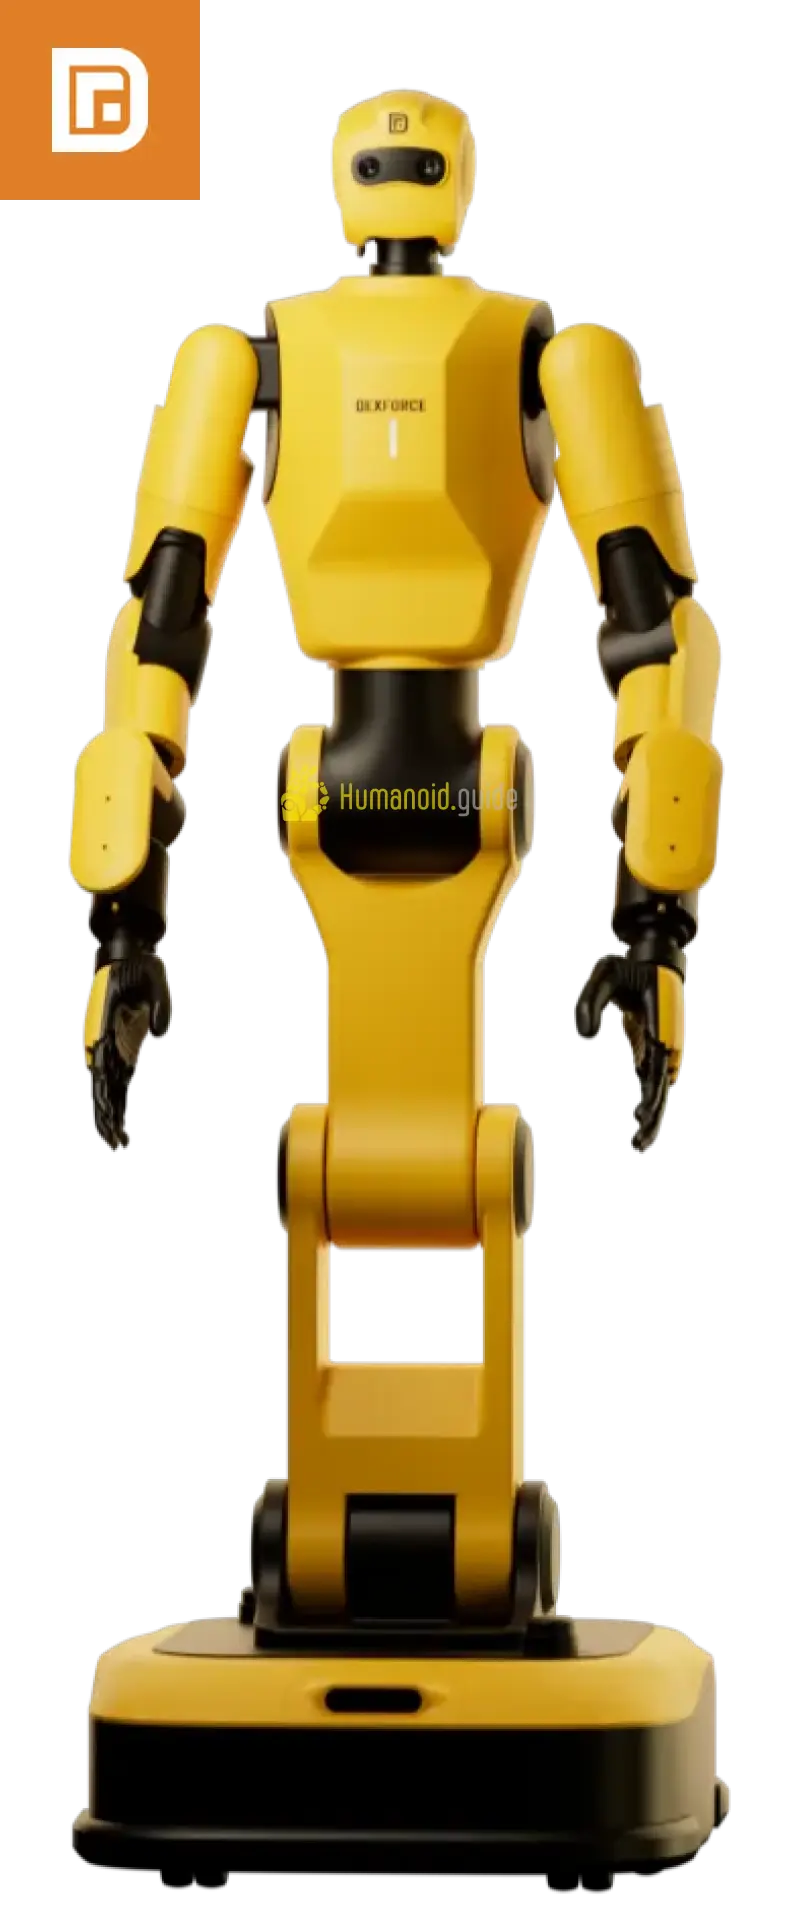
DexForce W1 Pro is an AI-defined wheeled humanoid robot with differential or omnidirectional chassis options for embodied intelligence deployments.
Official product source: https://en.dexforce.com/w1pro.html.
Specifications
| Overall height | 1636 mm |
|---|---|
| Robot weight | 110 kg |
| Degrees of freedom | 34 body DOF; up to 40 including omnidirectional chassis |
| Payload | 10 kg maximum single-arm payload |
| Arm payload | 10 kg per arm |
| Product model | W1 Pro |
| Dimensions | 682 × 550 × 1636 mm (L × W × H) |
| Runtime | ≥8 hours continuous power supply when wired; battery endurance not specified |
| Battery capacity | 40 Ah (LiFePO4 battery optional) |
| Walking speed | Maximum 1.5 m/s; rated 1.2 m/s (differential chassis configuration) |
| Perception sensors | RGB_camera|force_torque_sensor |
| Communication protocol | EtherCAT |
| Hand degrees of freedom | 6-11_dof |
| Arm degrees of freedom | 7_dof_redundant |
| Walking mode | wheeled_humanoid_upper |
Official DexForce W1 Pro page distinguishes 34 body DOF for the differential chassis configuration and 40 total DOF for the omnidirectional chassis configuration. It lists 682 × 550 × 1636 mm dimensions, 110 kg weight, up to 10 kg single-arm payload, 7 DOF per arm, ±0.5 mm arm repeatability, max straight-line speed 1.5 m/s (rated 1.2 m/s), and ≥8 h continuous wired power supply. The 40 Ah LiFePO4 battery is optional. A 6-axis wrist force sensor is optional; the source also describes stereo vision, LiDAR and cameras.