

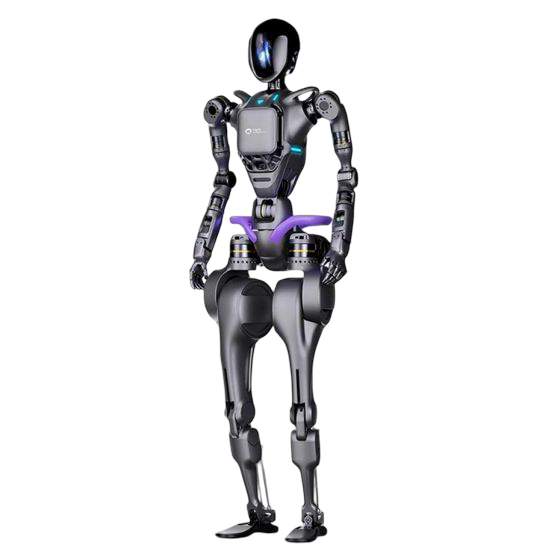
Fourier GR-1 is a general-purpose humanoid robot with a bionic body structure and human-like motion control.
Official English brochure: GR-1 technical specifications. Official documentation: GR-1 introduction and technical details.
Specifications
| Overall height | 1650 mm |
|---|---|
| Robot weight | Approximately 55 kg |
| Degrees of freedom | 44 actuators / degrees of freedom |
| Payload | 3 kg single-hand payload |
| Arm payload | 3 kg single-hand payload |
| Reach / workspace | 1680 mm arm span |
| Product model | GR-1 |
| Walking speed | 5 km/h (about 1.39 m/s) |
| Perception sensors | depth_camera|IMU |
| Arm degrees of freedom | 7_dof_redundant |
| Head and neck DOF | 3_dof_spherical |
| Torso DOF | 3_dof_roll_pitch_yaw |
Fourier official English GR-1 brochure lists GR-1 as 1650×515×320 mm standing, approximately 55 kg, 1680 mm arm span, 44 actuators, 3 kg single-hand payload, 5 km/h speed, approximately 550 W max power, 46.2 V supply, and i7-13700H computing. The official GR-1 documentation describes dual depth cameras, IMU and up to 44 body DOF. GR-1L and Pro variants are listed separately and are not conflated with this GR-1 item.
 企业会员

