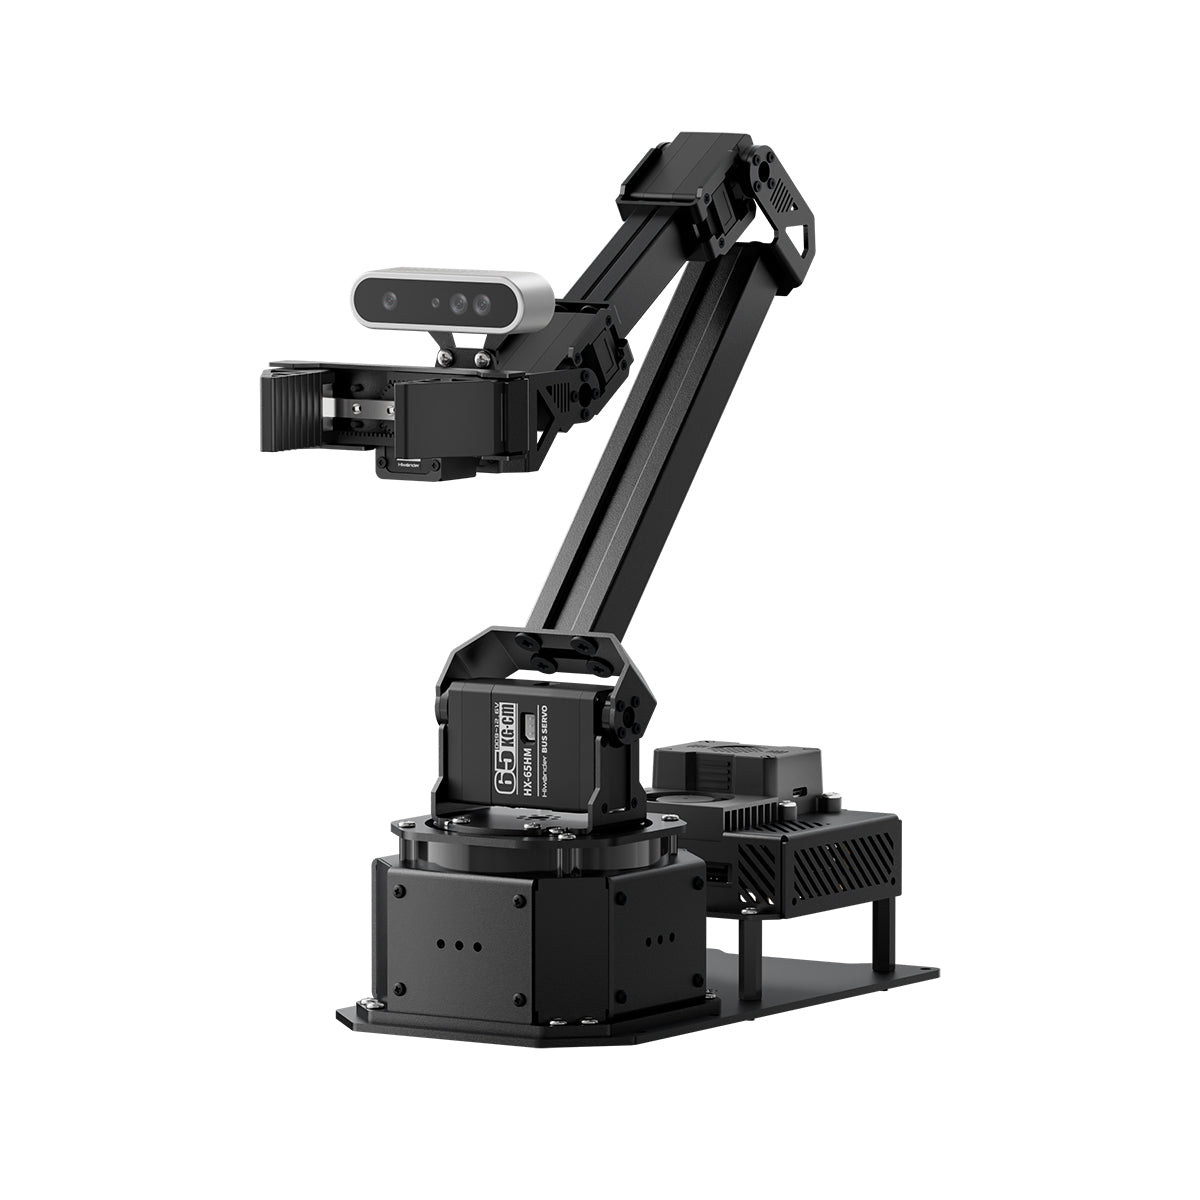


Hiwonder NexArm ROS Embodied AI Open-Source Robotic Arm
Hiwonder NexArm is an open-source ROS robotic arm for embodied AI research. Dual NVIDIA/Raspberry Pi + ESP32 controllers, VLA, ACT, multimodal AI, OpenClaw, 3D depth camera & inverse kinematics — full-stack from sensing to manipulation.
规格参数
| 外形尺寸 | 245 × 131 × 617 mm |
|---|---|
| 重量 | 1.3 kg |
| 技术扩展参数 | ESP32 controller: ESP-WROOM main chip;ROS controller: Raspberry Pi 5 / Jetson Nano / Jetson Orin Nano / Jetson Orin NX;Control Methods: ROS topics/nodes, Python programming, app control, PC software control;Camera: Depth camera;Power supply: 12 V 5 A DC power adapter;Operating system: Ubuntu 22.04 + ROS 2 Humble;Programming tools: Python, C, C++;Storage: 64 GB TF card (Raspberry Pi 5 / Jetson Nano) 128 GB SSD (Orin Nano / Orin NX) |
| 产品型号 | NexArm ROS Embodied AI Open-Source Robotic Arm |