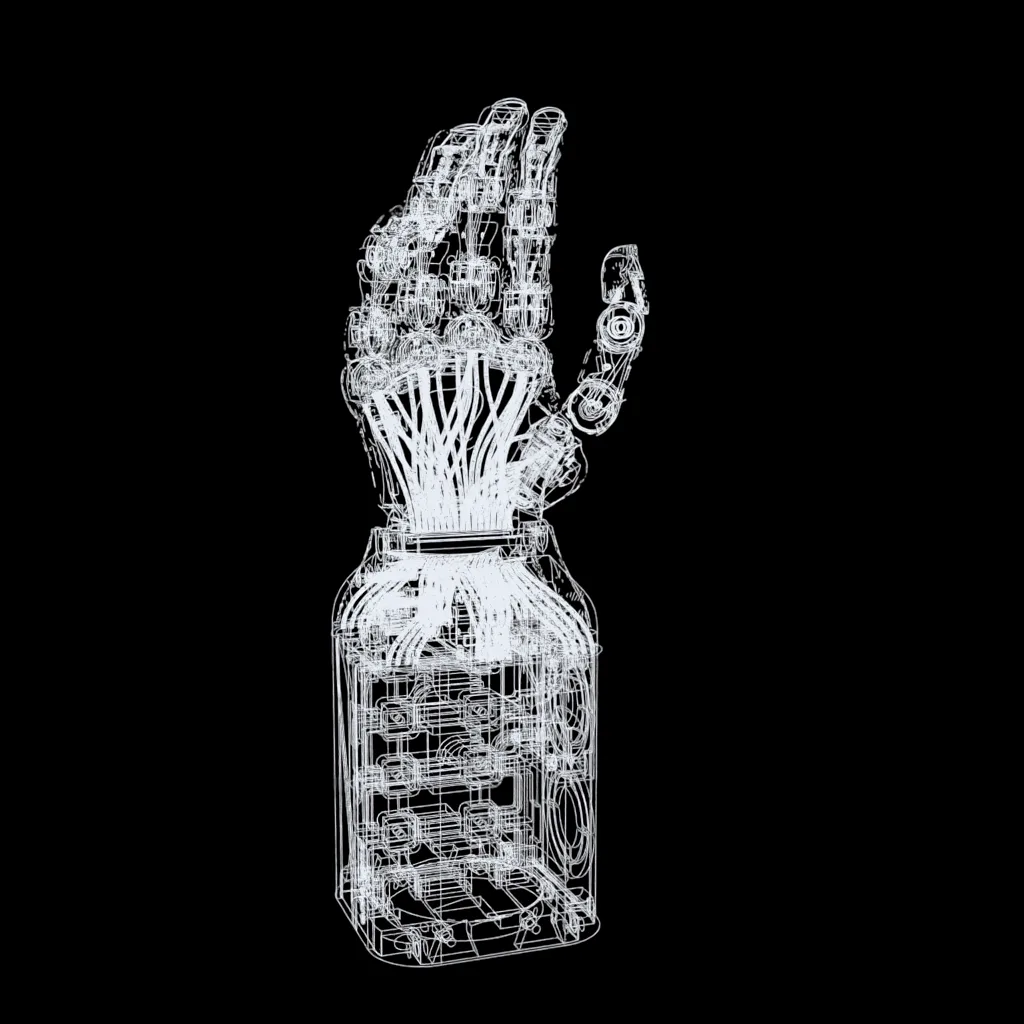
A five-digit dexterous research hand with 17 degrees of freedom and integrated fingertip tactile sensing. The official specification lists 351 Hall-effect 6D force/torque taxels, USB-C connection to a PC, and an ISO 9409-1 mounting interface.
Specifications
| Product model | orcahand v2.0 touch |
|---|---|
| Degrees of freedom | 17 |
| Digits | 5 |
| Tactile taxels | 351 across 5 digits |
| Weight | Approximately 1.25 kg |
| PC connection | USB-C |
| Technical extension parameters | 16 finger actuators plus 1 wrist actuator; Hall-effect 6D force/torque sensing with 51–83 taxels per finger; cooling by two fans; ISO 9409-1 mounting interface (official getting-started page specifies ISO 9409-1-50-4-M6 / A50); Python control through orca_core. Official source: https://www.orcahand.com/hardware/touch and https://www.orcahand.com/getting-started |