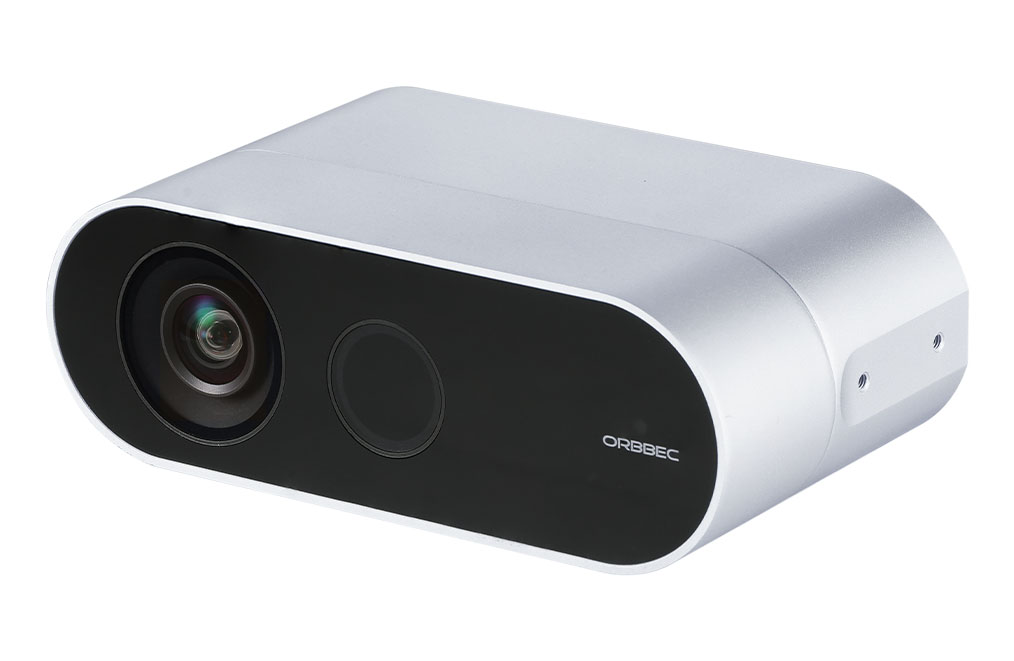
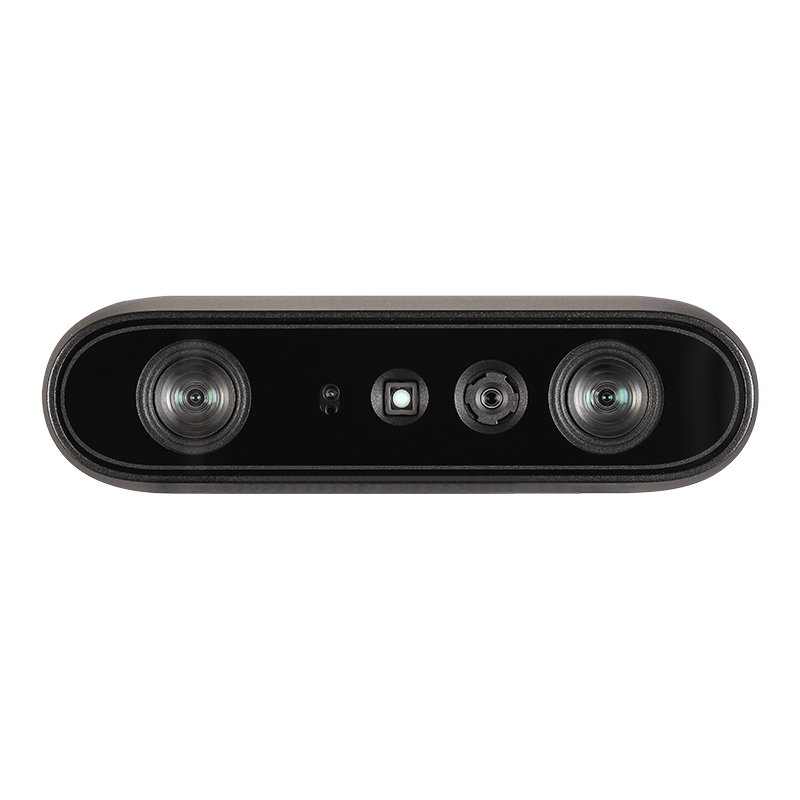
Orbbec Femto Bolt is an indoor time-of-flight depth camera with RGB and IMU sensing. The product page specifies mode-dependent depth performance. Orbbec's product page and hardware documentation report dimensions differently; both original figures are disclosed below without silently reconciling them.
Standard specifications
| Vision type | ToF |
|---|---|
| Image sensor | Time-of-Flight depth camera with RGB imager and 6-DoF IMU; 850 nm illumination |
| Resolution | Depth: 1024 × 1024 at 15 fps (WFOV) or 640 × 576 at 30 fps (NFOV); RGB: 3840 × 2160 |
| Frame rate | Depth: 15 fps (WFOV) or 30 fps (NFOV); RGB: up to 30 fps |
| Field of view | Depth: WFOV 120° × 120°; NFOV 75° × 65°. RGB: 80° × 51° |
| Working distance | 250–5,460 mm, mode-dependent |
| Data interface | USB3 |
| Dimensions | 115 × 40 × 65 mm (W × H × D; product page) |
| Weight | 0.348 kg |
| Operating temperature | 10–25 °C (indoor operating environment) |
| SDK | Orbbec SDK |
| Power consumption | 4.35 W average |
Additional manufacturer specifications
| Depth range by mode | 0.25–5.46 m; available range depends on operating mode |
|---|---|
| Depth accuracy | <11 mm + 0.1% of range; manufacturer-stated condition applies |
| Depth precision | ≤17 mm; manufacturer-stated condition applies |
| RGB field of view | 80° × 51° |
| RGB resolution and frame rate | Up to 3840 × 2160 at 30 fps |
| IMU | 6-DoF IMU supported |
| Data output | Point cloud, depth, IR and RGB |
| Trigger and synchronization | Hardware trigger supported; multi-camera synchronization supported |
| Power input | USB-C or 12 V DC, 2 A |
| Operating environment | Indoor; 10–25 °C; 8–90% relative humidity |
| Mounting | Bottom 1/4-20 UNC; side 4 × M2.5 |
| Dimensions source note | The product page gives 115 × 40 × 65 mm (W × H × D); Orbbec hardware documentation gives 115.30 × 64.95 × 40.26 mm. Both official figures are retained; axis order differs by source. |
Source: Orbbec official English Femto Bolt product page and linked Orbbec hardware documentation.