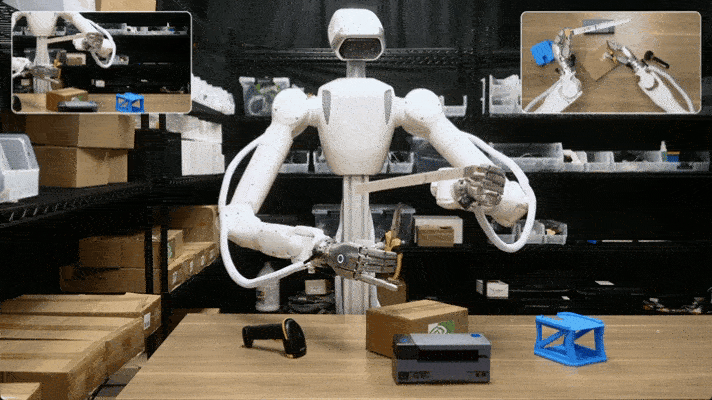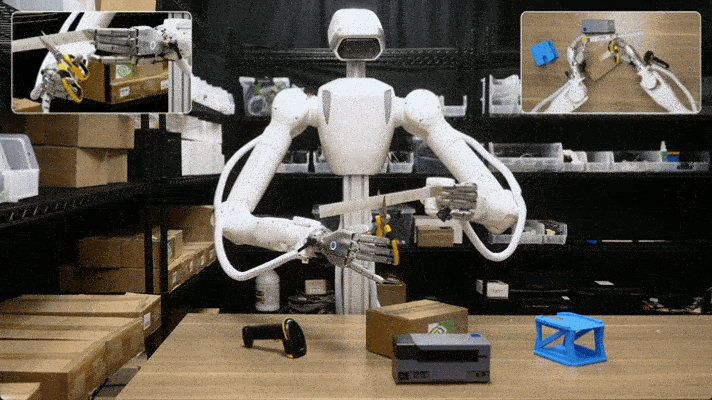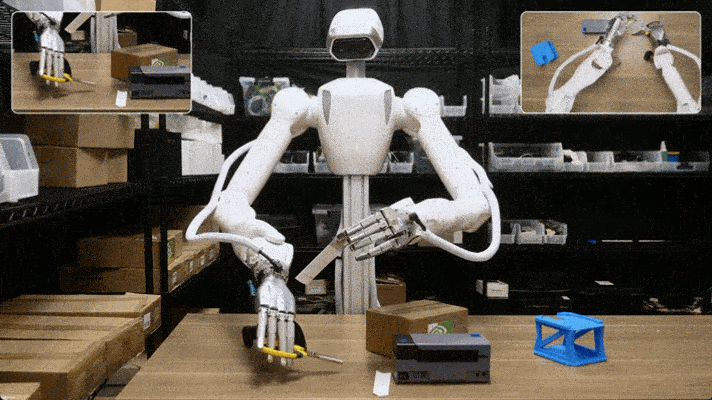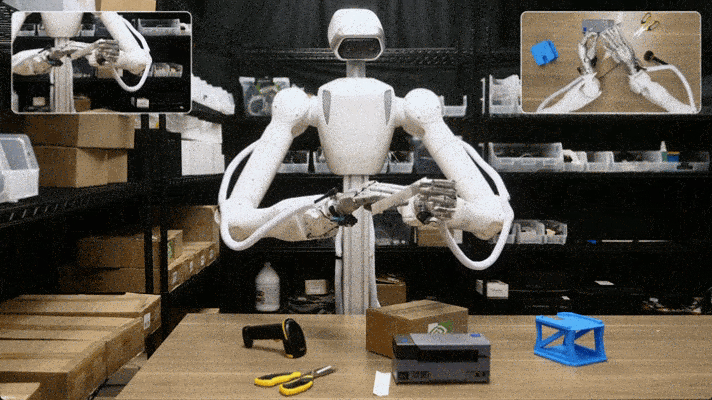
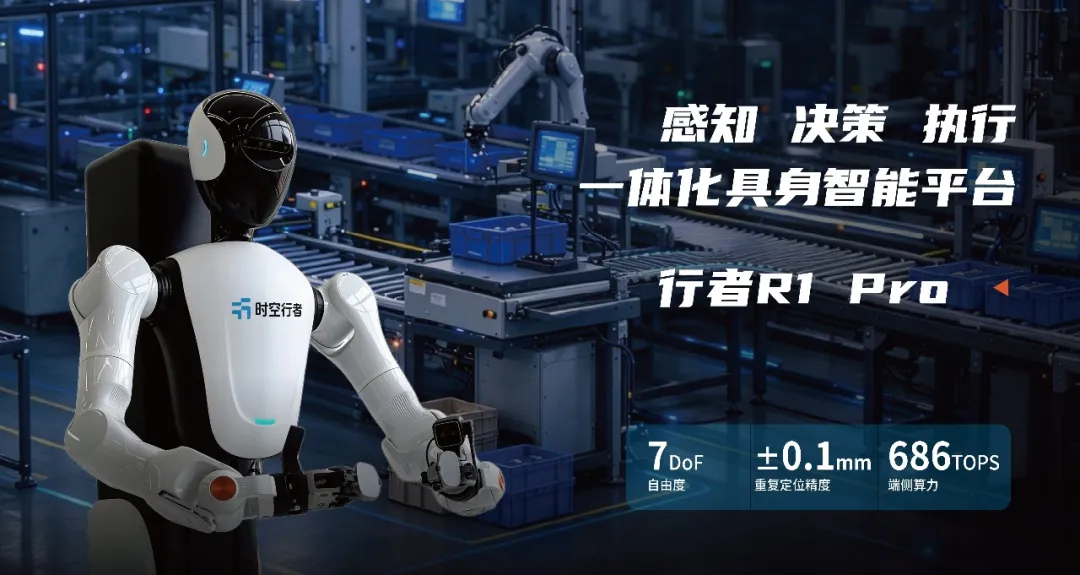
The shift in focus is determined by the technological nature of the physically intelligent. The physically intelligent robot entity relies on the physical world through its continuous interaction with the physical world through perception-decision-making. Models are reinforced, hardware is upgraded, and if it is not in sync with the physical control, real-world scenarios and data flow chains, it is difficult to establish a closed loop.
The same is true for scientific research. The value of robotic research platforms has long been not limited to physical mobility, but to whether they can support a complete experimental process from data collection, model verification to physical control and scenarios reproduction. Only these capabilities are interconnected to truly meet the needs of repeat verification and continuous generation in the scientific research process.
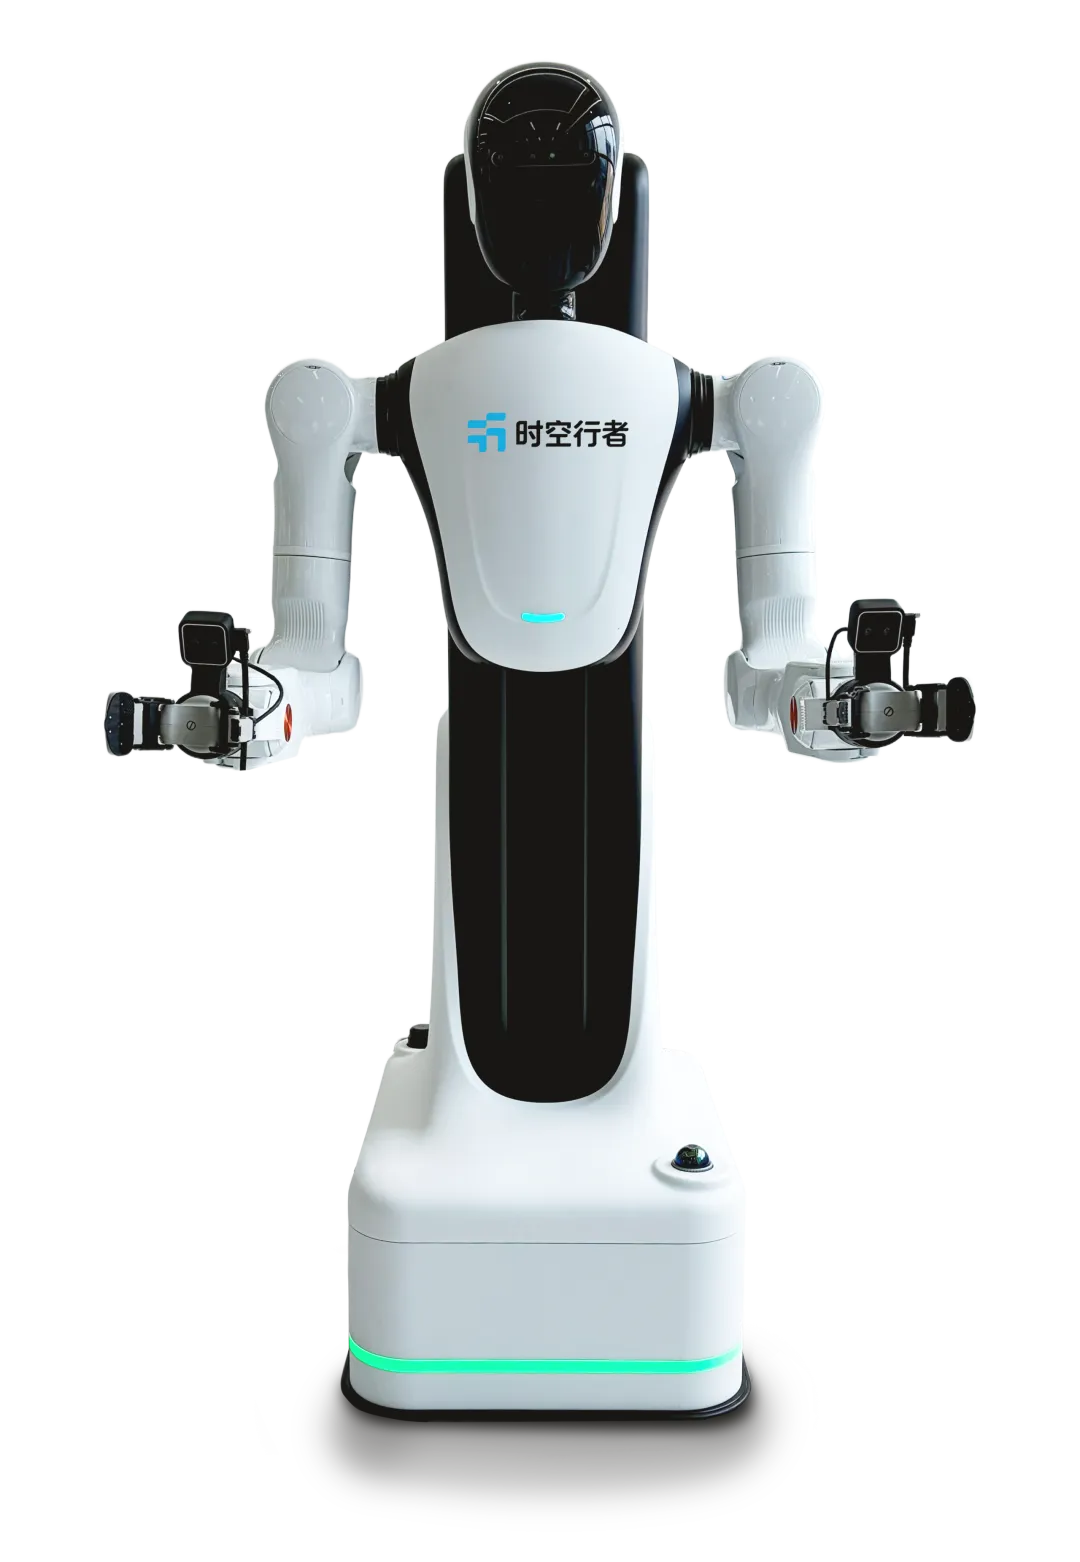
The R1 Pro is a wheeled, two-armed, physically intelligent platform built to meet the needs of scientific research. It is based on the execution of human arms with seven degrees of freedom, incorporates multiple sensors, array speech, and other modular sensing capabilities, and combines high-power computing platforms with large VLA models to build a complete technological chain from environmental perception, intelligent decision-making to action execution, enabling physically intelligent research to continuously verify and iterate in real-world physical environments.
01.
Understanding: See the world clearly, then talk about understanding
Physical intelligence moves from simulation verification to real-world scenarios, where perception has to answer two questions at the same time: to see the whole in the big scene and to see in front of the operating table. Navigation building charts, positioning obstacles and capturing tasks are not the same as the needs for perception of distance and accuracy, single sensors are not compatible, and multi-layered modular perception is therefore an important basis for scientific research platforms.Based on this idea, the Walker R1 Pro's sensing is divided into four layers: a multi-ray laser radar that is responsible for the overall mapping, positioning, and avoidance of obstacles; a single-ray laser radar that supplements the substrate, focusing on low-level obstacles and radar blind areas; a head with a depth camera, a viewfinder covering the operating stage, and an algorithm for verifying direct operation.

These build a multi-layered multi-modal perception system at the global + operating end, which combines large-scale mapping navigation and close-up detail capture while supporting multi-dimensional interaction data recording.
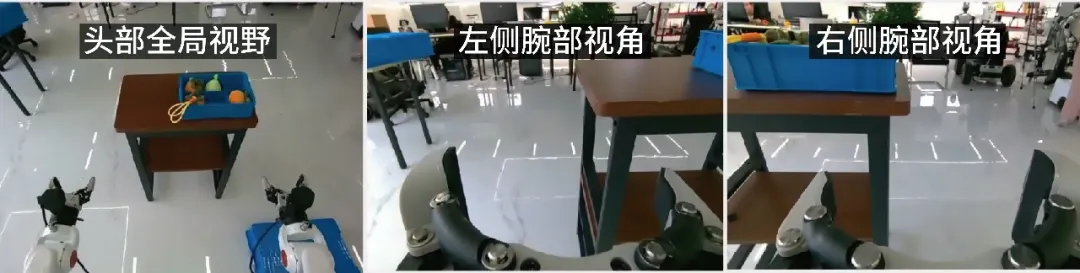
In addition, the platform integrates six-axis IMUs, six microphone arrays, and supports voice source positioning and offline voice interaction. The VR remote control system is marked, researchers can remotely demonstrate, fully collect and record multi-modal data such as vision, depth, force/force matrix, conjunction status, and support the verification of the data flyer closure of the cylinder rotating cylinder model.

02.
Decision: 686 TOPS Calculator + Open Software System to complete understanding, reasoning and task planning
The R1 Pro incorporates an integrated computing design, built-in x86 computing platform, equipped with 686 TOPS computing power, 32GB of memory and 1TB of storage space, and no external workstations to support local deployments and offline operations of large models such as VLAs, LLMs, etc. Depending on the openness of the x86 computing platform and the compatibility of the toolchain, researchers can directly test end-to-end logic delays, power consumption, and model adaptations on cameras, accelerating the algorithm transformation process from development verification to actual deployment.
The software is based on ROS2 eco-building, pre-installed navigation mapping, bi-arm movement planning, behavioral tree scheduling, voice interaction and large-scale model-related development tools, and provides a complete robot URDF model. Based on open software architecture and standardized interfaces, researchers have quick access to various types of Agent frameworks and tools, flexible portfolio perception, planning and execution capabilities, development and verification of physically intelligent agents.
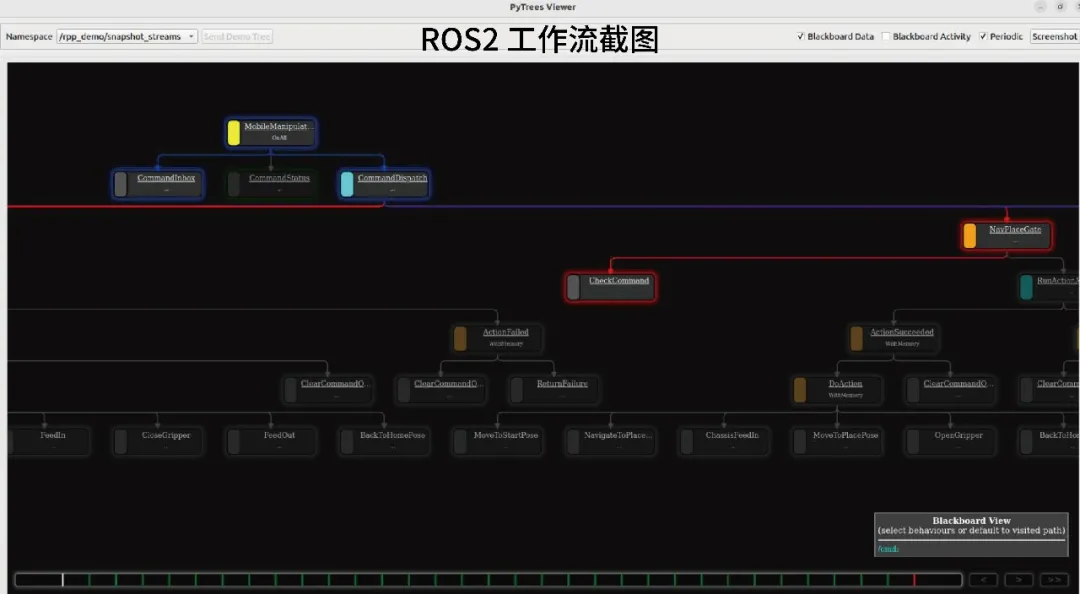
At the same time, the platform is open-source with deep secondary development, which can both directly call on existing components for rapid conceptual verification; and open up all sensor raw data flows, ROS interfaces to researchers, allowing modification of underlying control logic, and replacement of self-development algorithms.
03.
Execution: From the chassis to the claws, a complete set of sporting devices, realising physical world interaction tasks
The chassis is based on a differential-speed drive design that combines motion stability and control precision to provide a reliable base for autonomous navigation, algorithmic verification of location mapping and real-world scenarios. The elevator is a vertical structure with a course of 700 mm, covering multiple operating heights from the desk to the shelf; the top is tilted at 0° 90°, at an insufficient angle, and the body is tilted forward.

The arms use 7Dof human-powered control, motion-flexible; supports a two-finger electric torque holder, repeated positioning accuracy ±0.05mm, and are suitable for multi-dimensional object grabbing experiments.

The whole machine is equipped with emergency stop, safety touch, multiple safety protections with electromagnetic support, battery life can meet the needs of the use of intermittent scientific research experiments in the laboratory.
04.
What is the meaning of this verse?
Many scientific problems with physical intelligence cannot be fully solved on the basis of a simulation environment alone. Simulation can verify algorithmic concepts, but exposure to interference, signal latency, and reality constraints can only be observed and replicated in physical samples.
R1 Pro's goal is not to demonstrate, but to create perception and closure in the real world.
It's about seeing the world clearly. The radar tube is tens of meters, the wrist camera tube is the last ten centimeters, and the moment the six-dimensional tube comes into contact, the closer you get to the contact, the more fine-grained you look.
The decision was to run the model. Computing, interfaces, and ROS2 tool chains were all in the system, and data collection, training models, and running reasoning were not necessary.
To execute is to put the action down. The action does not take place until it is completed, the contact is stable; the result is to return to the perception, and the closed circle is formed when the circle joins.
R1 Pro wants researchers to spend less time on the rooftops and focus on physical intelligence issues in the real world.
About Time Walkers: Hyundai Time Walkers Technology Limited (formerly known as Hyundai Robotics Limited), is a state-owned high-tech enterprise specializing in new and medium-sized enterprises in Anhui province. The company focuses on the field of smart robots, aimed at universities, research institutes and enterprise research and development institutions, providing smart development platforms, wheeled humanoid robots, open mobile/complex robots and complete construction of laboratories.