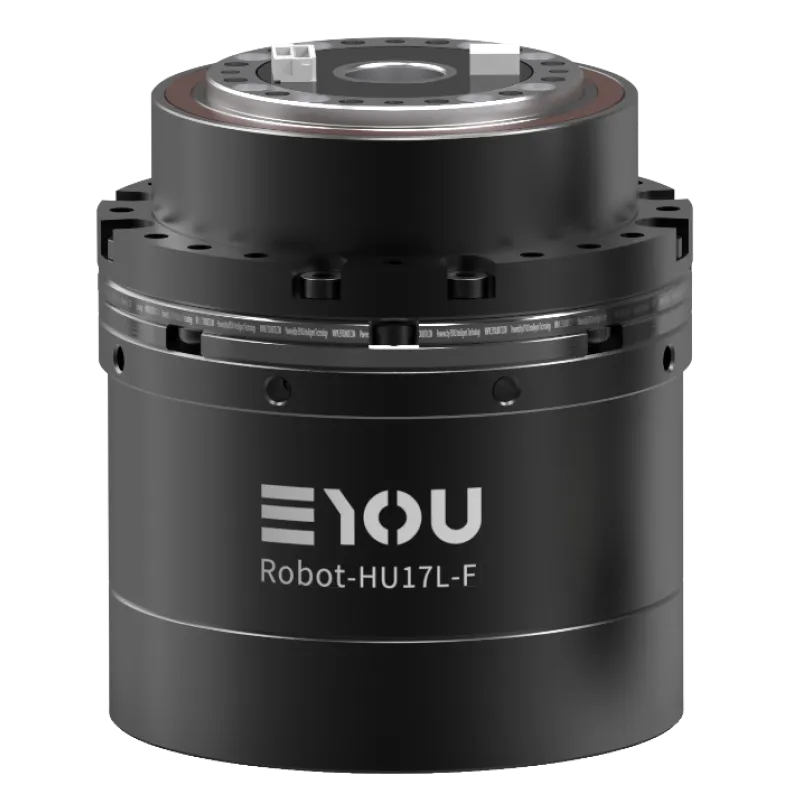
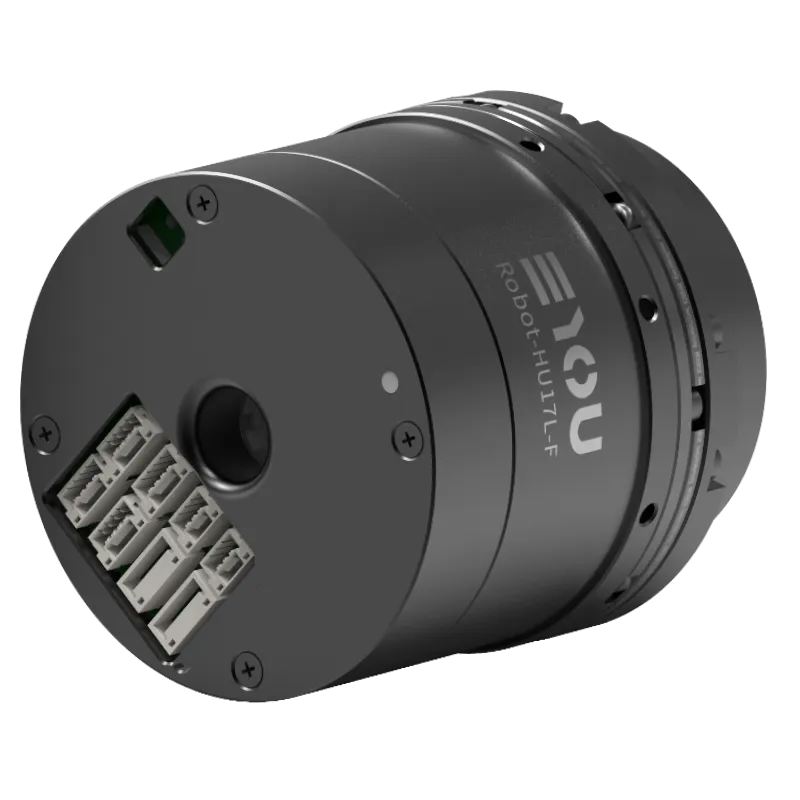
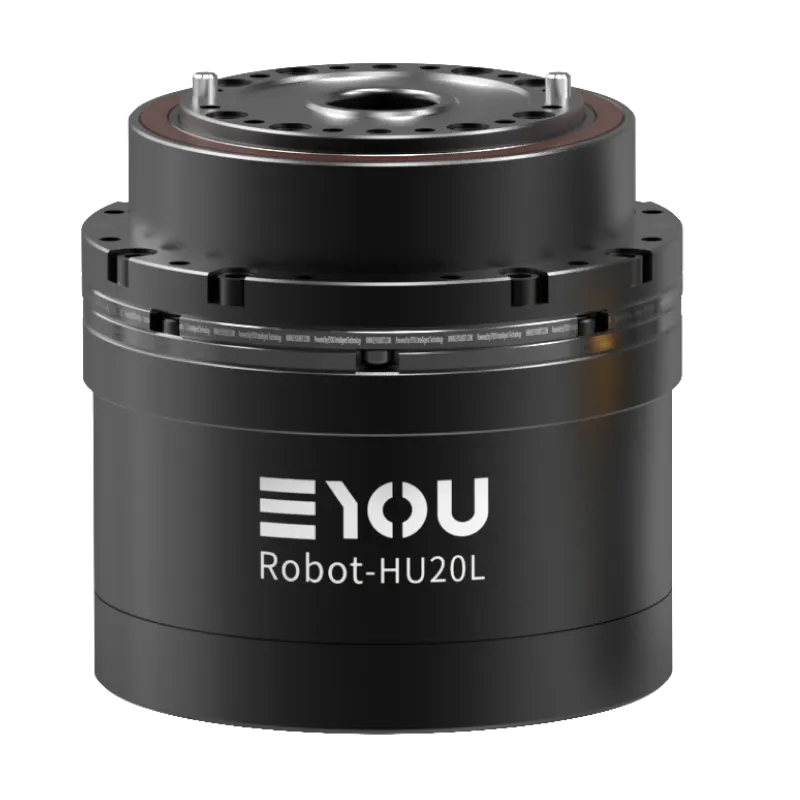
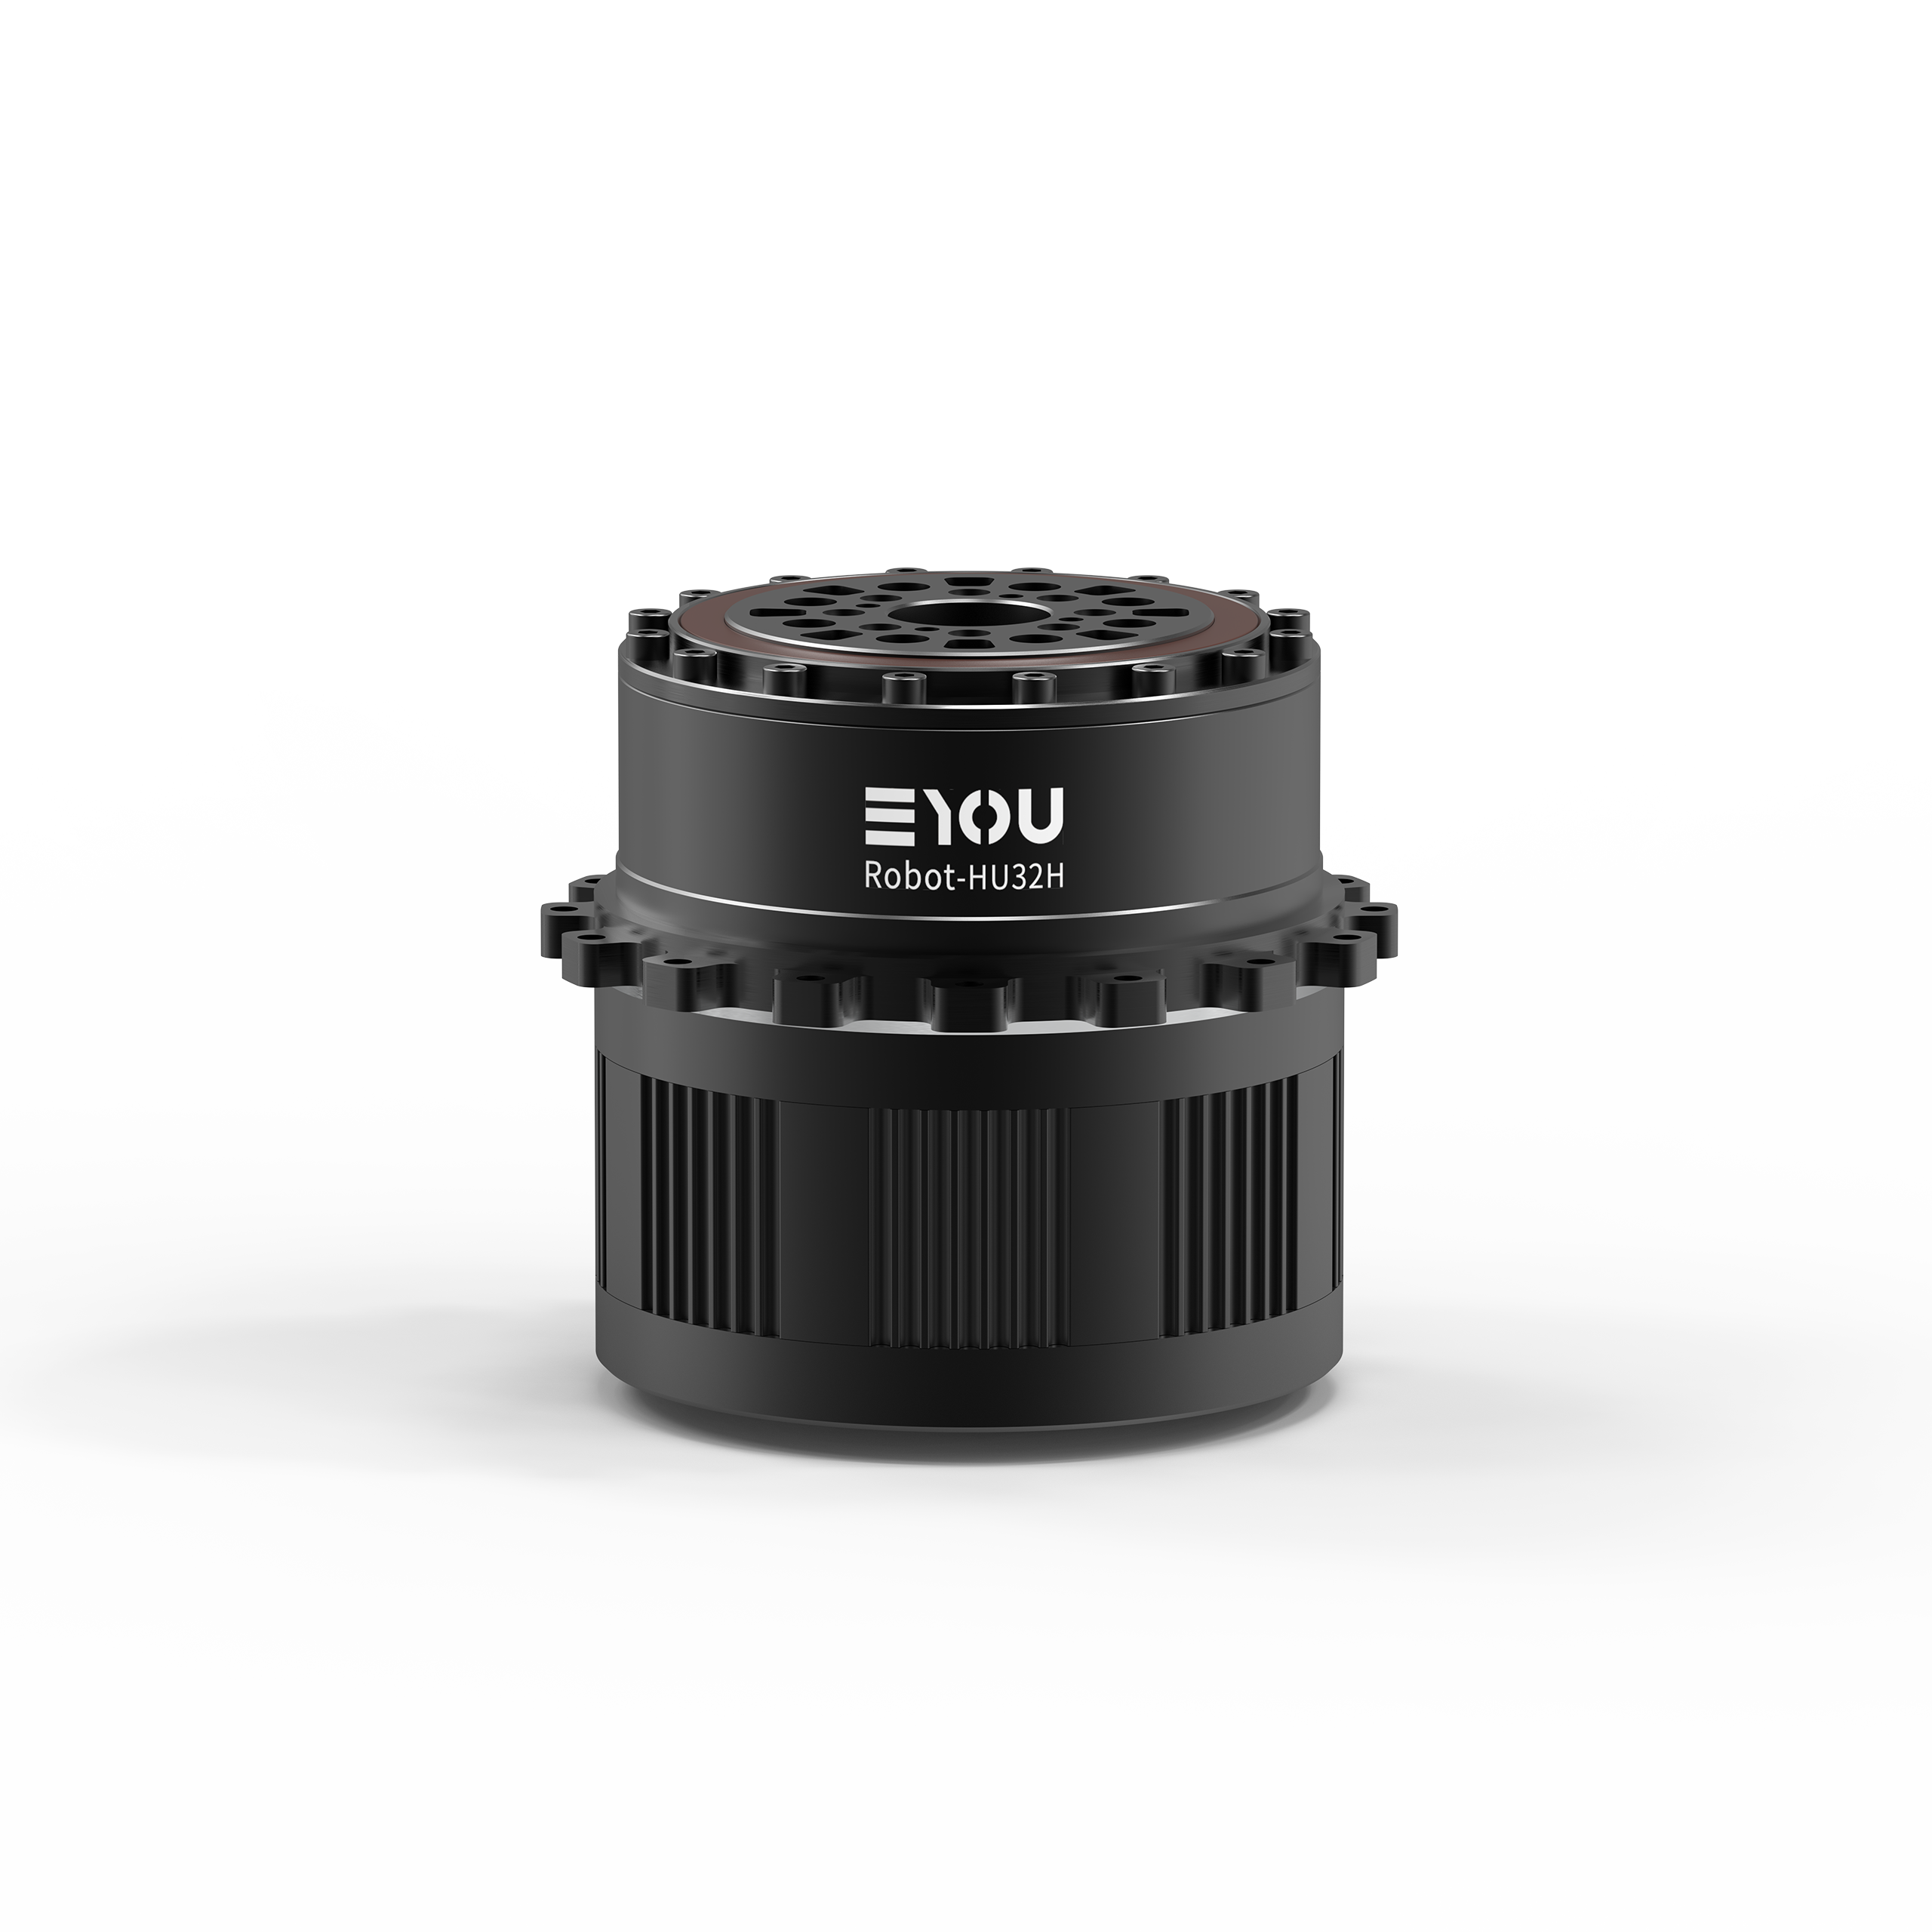
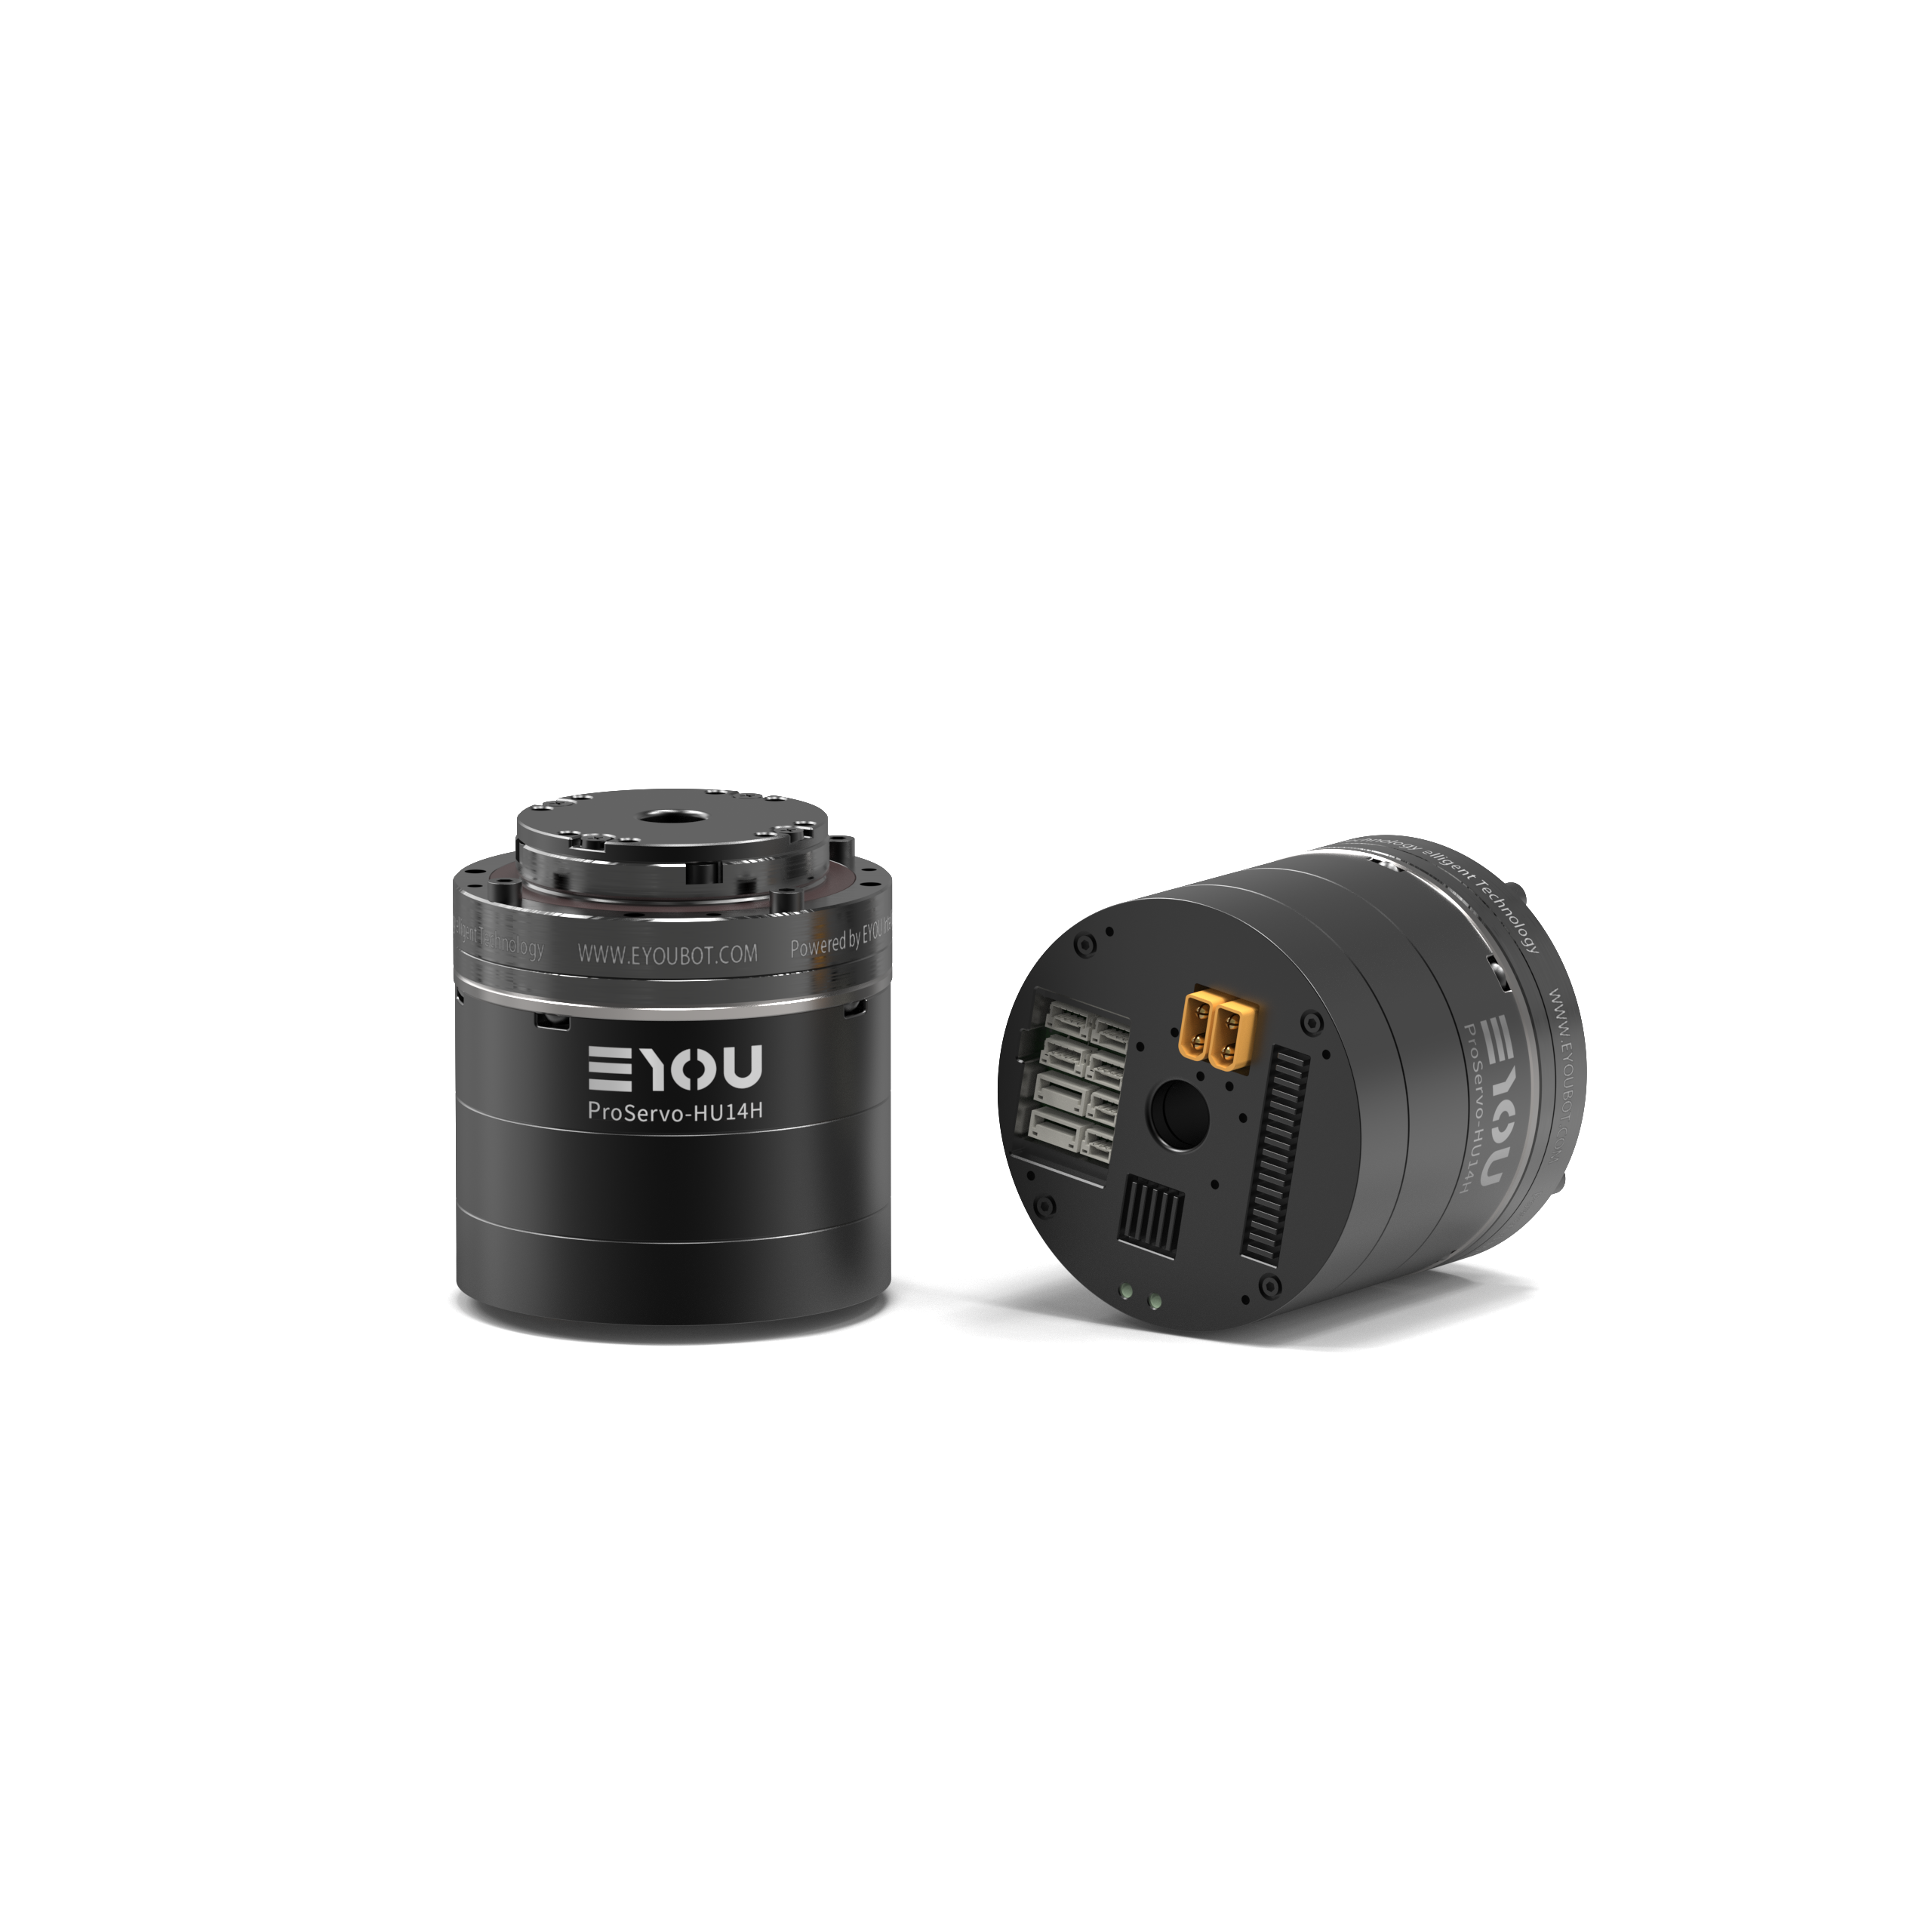
EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module
prev
EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module
next
型号:RHU17L-60-N-F角色:english_official_product

EYOU RHU17L-60-N-F Humanoid Harmonic Joint Module

单价
面议
对比
询价暂无
浏览7
发货江苏无锡市
品牌EYOU Robotics
过期长期有效
更新2026-10-15 01:40

详细说明

规格参数

Product specifications · 按产品分类标准字段展示
中英文标准字段
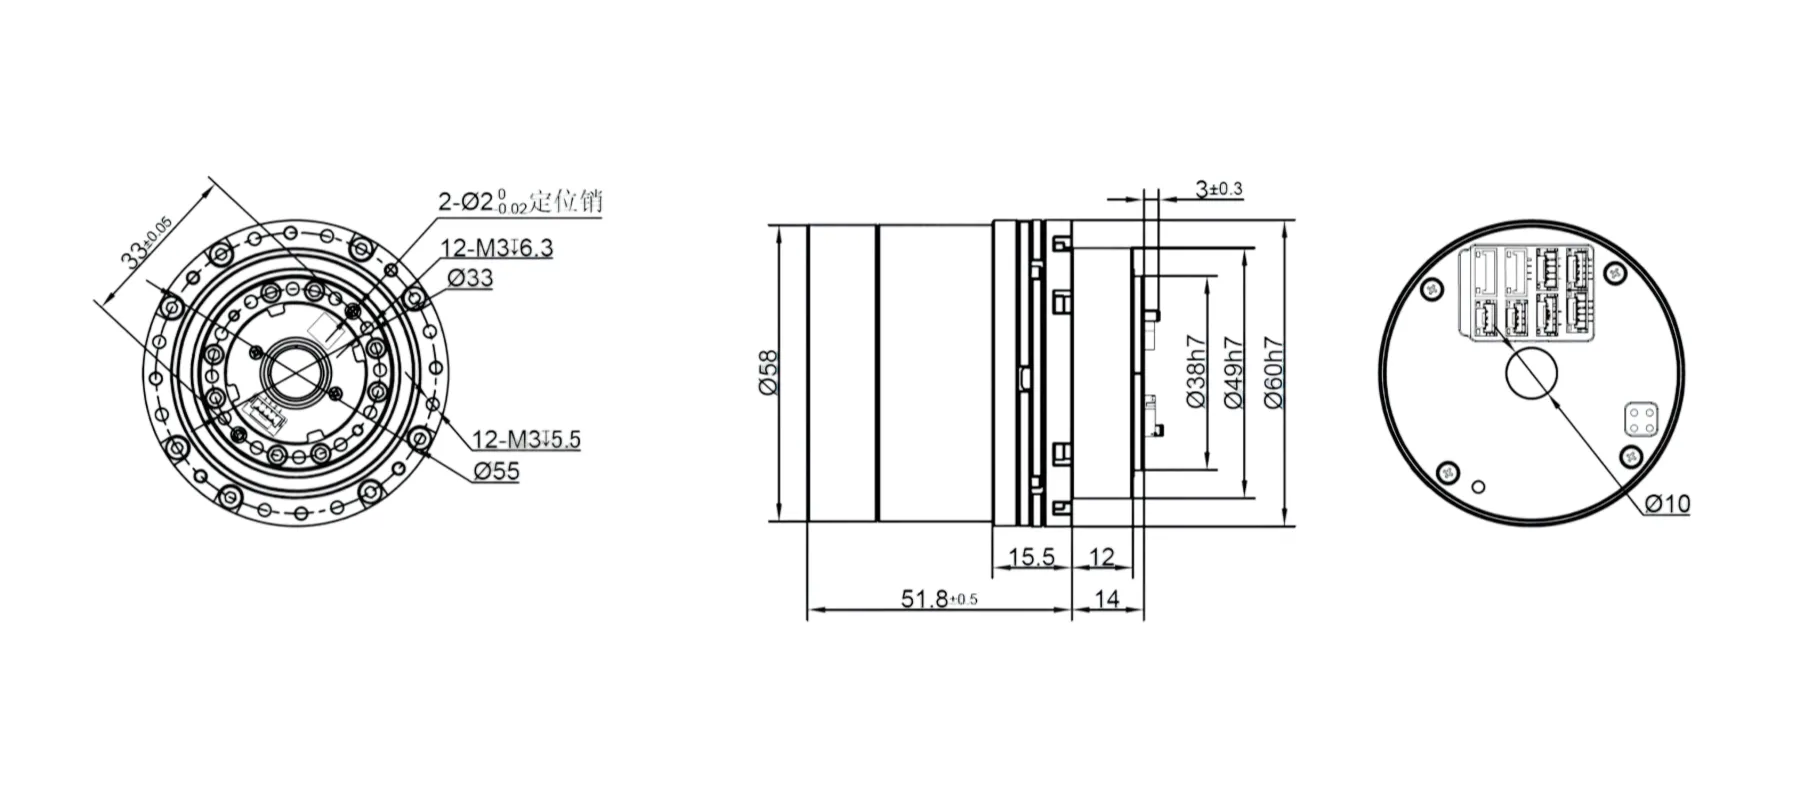
外径
Outer diameter
60 mm
长度
Length
66 mm
通孔直径
Through-hole diameter
10 mm
重量
Weight
0.521 kg (N configuration; B configuration 0.538 kg)
减速比
Reduction ratio
50 / 80 / 100
额定电压
Rated voltage
24–48 V
额定功率
Rated power
46 / 39 / 34 W
额定扭矩
Rated torque
11 / 15 / 16 N·m
峰值扭矩
Peak torque
23 / 29 / 37 N·m
编码器类型
Encoder type
absolute (dual absolute encoders)
通信协议
Communication protocol
EtherCAT|CANopen
技术扩展参数
Technical extension parameters
Average output torque: 18 / 19 / 27 N·m; maximum allowable momentary torque: 48 / 61 / 71 N·m; torque accuracy ≤±0.5% FS; sensor resolution 0.1% FS; sampling frequency ≥5 kHz; encoder accuracy 19 bit; power-off brake optional. Ratios in the source table correspond positionally to each listed torque/power series.
技术扩展参数 · Technical extension
外径
Outer diameter
60 mm
长度
Dimensions / length
66 mm
通孔直径
Hollow bore diameter
10 mm
重量
Weight
0.521 kg (N configuration; B configuration 0.538 kg)
减速比
Reduction ratio
50 / 80 / 100
额定电压
Operating voltage
24–48 V
额定功率
Rated output power
46 / 39 / 34 W
额定扭矩
Rated torque at 2,000 rpm
11 / 15 / 16 N·m
峰值扭矩
Peak start-stop output torque
23 / 29 / 37 N·m
编码器类型
Encoder type
absolute (dual absolute encoders)
通信协议
Communication protocol
EtherCAT|CANopen
技术扩展参数
Technical extension
Average output torque: 18 / 19 / 27 N·m; maximum allowable momentary torque: 48 / 61 / 71 N·m; torque accuracy ≤±0.5% FS; sensor resolution 0.1% FS; sampling frequency ≥5 kHz; encoder accuracy 19 bit; power-off brake optional. Ratios in the source table correspond positionally to each listed torque/power series.

Force-control humanoid harmonic joint module with a 60 mm outer diameter, 10 mm hollow bore, 24–48 V operation, dual absolute encoders and EtherCAT/CANopen communication. The official page lists multiple reduction-ratio and torque configurations.

Specifications

Outer diameter60 mm
Dimensions / length66 mm
Hollow bore diameter10 mm
Weight0.521 kg (N configuration; B configuration 0.538 kg)
Reduction ratio50 / 80 / 100
Operating voltage24–48 V
Rated output power46 / 39 / 34 W
Rated torque at 2,000 rpm11 / 15 / 16 N·m
Peak start-stop output torque23 / 29 / 37 N·m
Encoder typeabsolute (dual absolute encoders)
Communication protocolEtherCAT|CANopen
Technical extensionAverage output torque: 18 / 19 / 27 N·m; maximum allowable momentary torque: 48 / 61 / 71 N·m; torque accuracy ≤±0.5% FS; sensor resolution 0.1% FS; sampling frequency ≥5 kHz; encoder accuracy 19 bit; power-off brake optional. Ratios in the source table correspond positionally to each listed torque/power series.
分享3

联系卖家

联系方式
加关注0

江苏意优机器人科技有限公司

企业会员第1年
资料通过RoboInd企业数据导入认证
保证金未缴纳
Shopping Cart
0 new
购物车

当前购物车数量由 Destoon 实时读取

Cart Items
0
打开购物车时加载商品清单
Go to shopping cart 我的订单