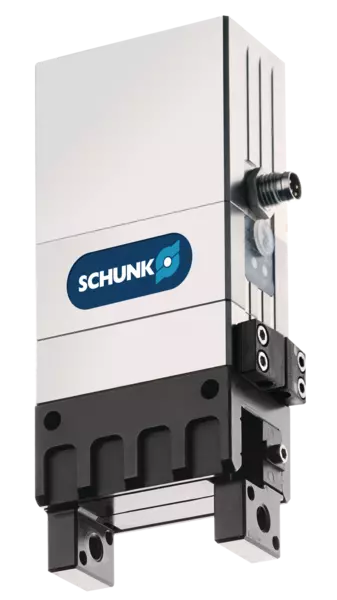
SCHUNK EGP 64-N-N-IOL IO-Link Servo-Electric Parallel Gripper
型号:EGP 64-N-N-IOL角色:english_official_product

SCHUNK EGP 64-N-N-IOL IO-Link Servo-Electric Parallel Gripper

单价
面议
对比
询价暂无
浏览7
发货全国
品牌SCHUNK
过期长期有效
更新2026-10-27 13:47

详细说明

规格参数

Product specifications · 按产品分类标准字段展示
中英文标准字段
夹爪类型
Gripper type
parallel
额定负载
Rated payload
Recommended workpiece mass: 1.25 kg (manufacturer-recommended value; not a rated robot payload)
夹持力
Grip force
Minimum 75 N; maximum 300 N (manufacturer defines gripping force as the arithmetic sum on both jaws)
行程/开口
Stroke / opening
10 mm per jaw
手指长度
Finger length
Maximum permitted finger length: 80 mm
产品型号
Product model
EGP 64-N-N-IOL
重复定位精度
Repeatability
Gripping repeat accuracy: 0.02 mm
供电电压
Supply voltage
24 V
防护等级
Ingress protection
IP30
外形尺寸
Dimensions
64.0 × 35.0 × 119.95 mm (X × Y × Z)
重量
Weight
0.83 kg
工作温度
Operating temperature
5 to 55 °C
技术扩展参数 · Technical extension
产品型号
Product model
EGP 64-N-N-IOL
夹爪类型
Gripper type
parallel
额定负载
Rated payload
Recommended workpiece mass: 1.25 kg (manufacturer-recommended value; not a rated robot payload)
夹持力
Grip force
Minimum 75 N; maximum 300 N (manufacturer defines gripping force as the arithmetic sum on both jaws)
行程/开口
Stroke / opening
10 mm per jaw
手指长度
Finger length
Maximum permitted finger length: 80 mm
重复定位精度
Repeatability
Gripping repeat accuracy: 0.02 mm
供电电压
Supply voltage
24 V
防护等级
Ingress protection
IP30
外形尺寸
Dimensions
64.0 × 35.0 × 119.95 mm (X × Y × Z)
重量
Weight
0.83 kg
工作温度
Operating temperature
5 to 55 °C
技术扩展参数
Technical extension parameters
Communication interface: IO-Link; gripping modes: FastGrip and SoftGrip; repeat accuracy (positioning): ±0.2 mm unidirectional and ±0.2 mm bidirectional; opening time 0.49 s and closing time 0.49 s (base jaws only; excludes application-specific fingers and PLC reaction time); maximum total current 2.0 A; nominal current 0.15 A; recommended workpiece mass 1.25 kg; maximum permitted finger length 80 mm; maximum permitted finger mass 0.24 kg per finger; cleanroom class ISO 14644-1 Class 5 (1999); two digital inputs; noise emission <70 dB(A); rack-and-pinion operating principle; servo-electric actuation via brushless DC servomotor; coated aluminum-alloy housing and steel base jaws; maximum static moments per jaw Mx 3.5 Nm, My 6.0 Nm, Mz 9.0 Nm; maximum axial force Fz 250 N; 24-month warranty. Manufacturer defines gripping force as the arithmetic sum on both jaws. Recommended workpiece mass is not robot payload. SCHUNK labels the linked image an illustration similar to the selected variant.

SCHUNK EGP 64-N-N-IOL servo-electric parallel gripper with IO-Link for medium-sized components. Manufacturer specifications are preserved with qualifiers for jaw stroke, grip force, workpiece weight and positioning accuracy.

Standard specifications

Product modelEGP 64-N-N-IOL
Gripper typeparallel
Rated payloadRecommended workpiece mass: 1.25 kg (manufacturer-recommended value; not a rated robot payload)
Grip forceMinimum 75 N; maximum 300 N (manufacturer defines gripping force as the arithmetic sum on both jaws)
Stroke / opening10 mm per jaw
Finger lengthMaximum permitted finger length: 80 mm
RepeatabilityGripping repeat accuracy: 0.02 mm
Supply voltage24 V
Ingress protectionIP30
Dimensions64.0 × 35.0 × 119.95 mm (X × Y × Z)
Weight0.83 kg
Operating temperature5 to 55 °C

Additional manufacturer specifications

Technical extension parametersCommunication interface: IO-Link; gripping modes: FastGrip and SoftGrip; repeat accuracy (positioning): ±0.2 mm unidirectional and ±0.2 mm bidirectional; opening time 0.49 s and closing time 0.49 s (base jaws only; excludes application-specific fingers and PLC reaction time); maximum total current 2.0 A; nominal current 0.15 A; recommended workpiece mass 1.25 kg; maximum permitted finger length 80 mm; maximum permitted finger mass 0.24 kg per finger; cleanroom class ISO 14644-1 Class 5 (1999); two digital inputs; noise emission <70 dB(A); rack-and-pinion operating principle; servo-electric actuation via brushless DC servomotor; coated aluminum-alloy housing and steel base jaws; maximum static moments per jaw Mx 3.5 Nm, My 6.0 Nm, Mz 9.0 Nm; maximum axial force Fz 250 N; 24-month warranty. Manufacturer defines gripping force as the arithmetic sum on both jaws. Recommended workpiece mass is not robot payload. SCHUNK labels the linked image an illustration similar to the selected variant.

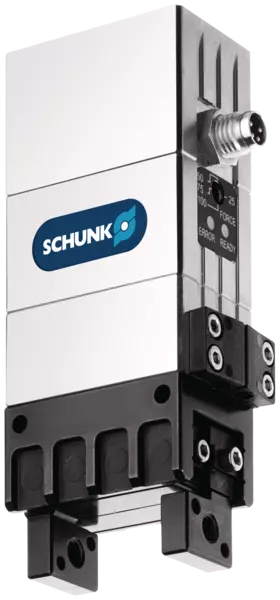
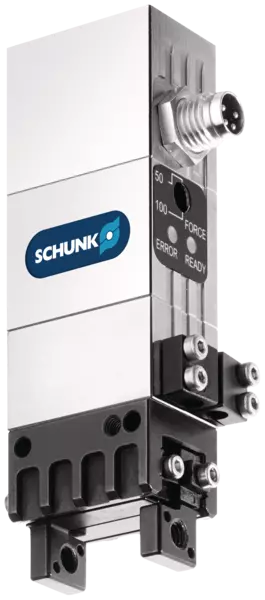
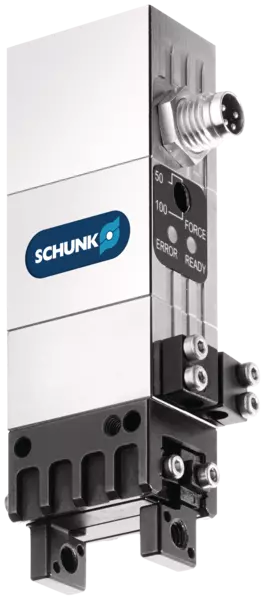
Image note: SCHUNK labels this linked product image an illustration similar to the selected variant.

Official English manufacturer source: https://schunk.com/us/en/gripping-systems/parallel-gripper/egp/egp-64-n-n-iol/p/000000000001383545
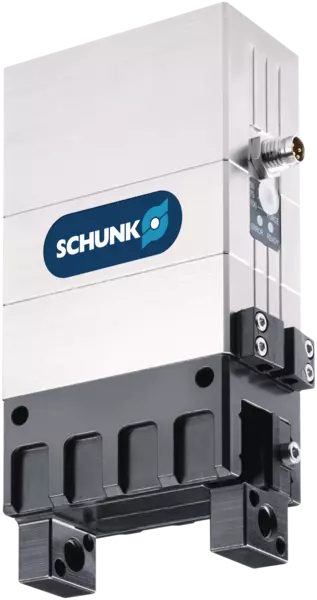
SCHUNK EGP 64-N-N-IOL official gripper image, illustration similar

分享2

联系卖家

联系方式
加关注0

SCHUNK

企业会员第1年
资料未认证
保证金未缴纳
  • 上次登录 N/A •
Shopping Cart
0 new
购物车

当前购物车数量由 Destoon 实时读取

Cart Items
0
打开购物车时加载商品清单
Go to shopping cart 我的订单