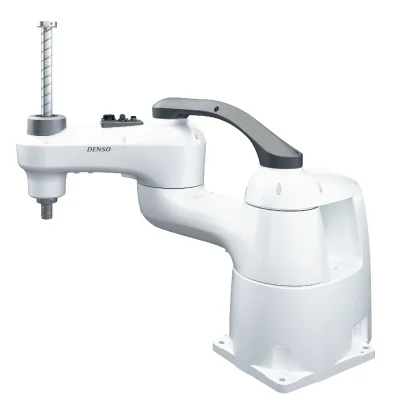
HSR-048/055/065 是 DENSO WAVE 的四轴 SCARA 工业机器人系列,面向工厂自动化应用。
规格参数
| T (4th axis) | ±360° |
|---|---|
| Axis combination | J1 (1st axis)+J2 (2nd axis)+Z (3rd axis)+T (4th axis) |
| Maximum payload | 8kg |
| Z | ±0.01mm |
| T | ±0.004° |
| Maximum force-fit | 98N (1 second or less) |
| Maximum allowable inertia moment | 0.12kgm2 |
| Position detection | Absolute encoder |
| Drive motor and brake | AC servomotors for all axes Brakes for Z axis (3rd axis) and T axis (4th axis) |
| UL-Listed models | 1. Press the brake release switch when the controller power is ON. 2. The teach pendant or mini-pendant cannot release the brakes. |
| User air piping | 4 systems (φ4×2、φ6×2) |
| User signal lines | ・19 (for proximity sensor signals, etc.) ・Ethernet(8)(1) |
| Max. allowable pressure | 0.59MPa |
| Airborne noise (A-weighted equivalent continuous sound pressure level) | 80dB or less |
| T (4th axis) | ±360° |
| Axis combination | J1 (1st axis)+J2 (2nd axis)+Z (3rd axis)+T (4th axis) |
| Maximum payload | 8kg |
| Z | ±0.01mm |
| T | ±0.004° |
| Maximum force-fit | 98N (1second or less) |
| Maximum allowable inertia moment | 0.12kgm2 |
| Position detection | Absolute encoder |
| Drive motor and brake | AC servomotors for all axes Brakes for Z axis (3rd axis) and T axis (4th axis) |
| UL-Listed models | 1. Press the brake release switch when the controller power is ON. 2. The teach pendant or mini-pendant cannot release the brakes. |
| User air piping | 4 systems (φ4×2、φ6×2) |
| User signal lines | ・19 (for proximity sensor signals, etc.) ・Ethernet(8)(1) |
| Max. allowable pressure | 0.59MPa |
| Airborne noise (A-weighted equivalent continuous sound pressure level) | 80dB or less |
| Overhead-mount | Standard/Bellows/UL |

 企业会员