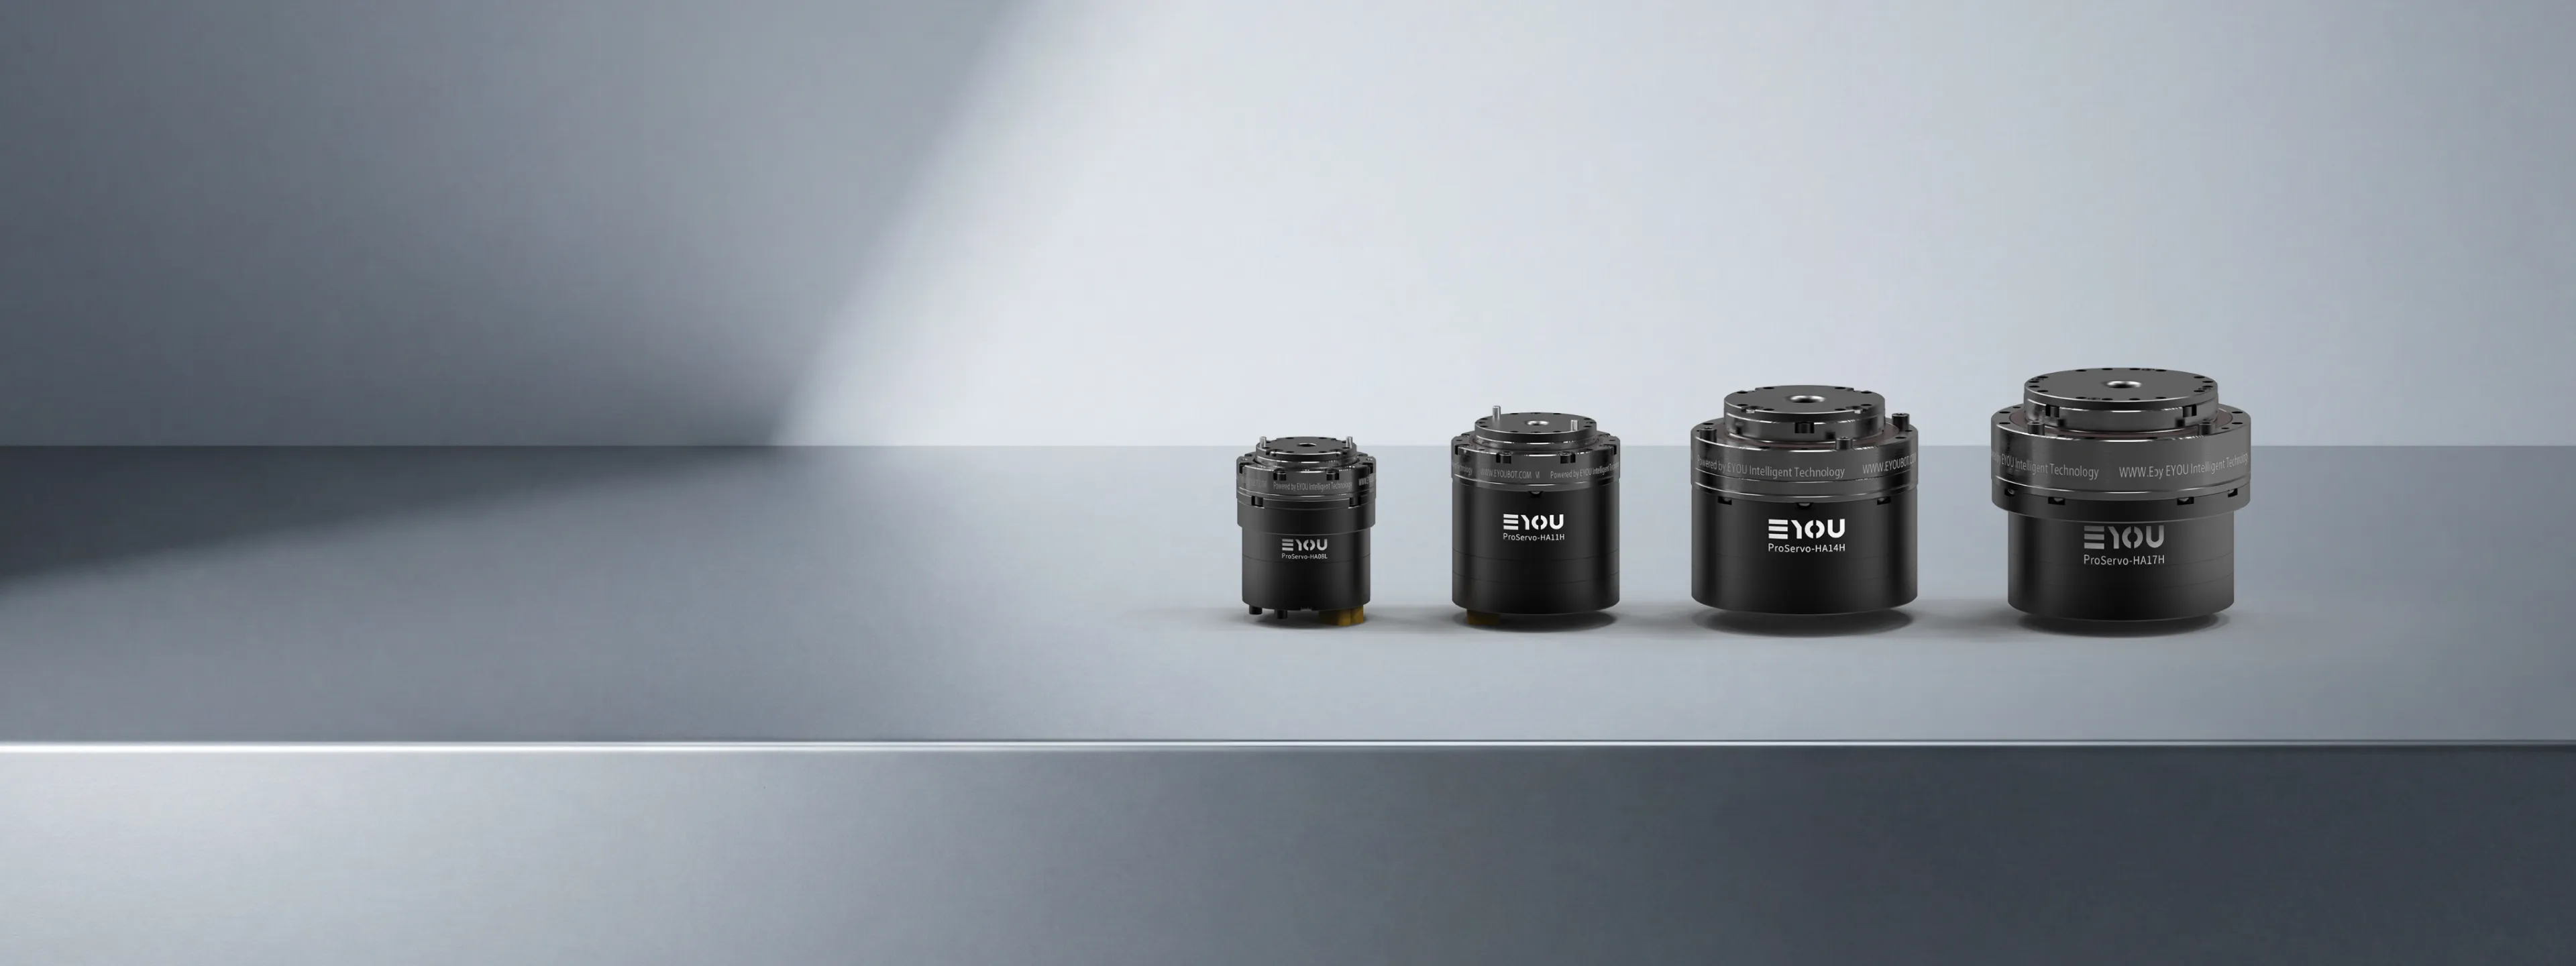
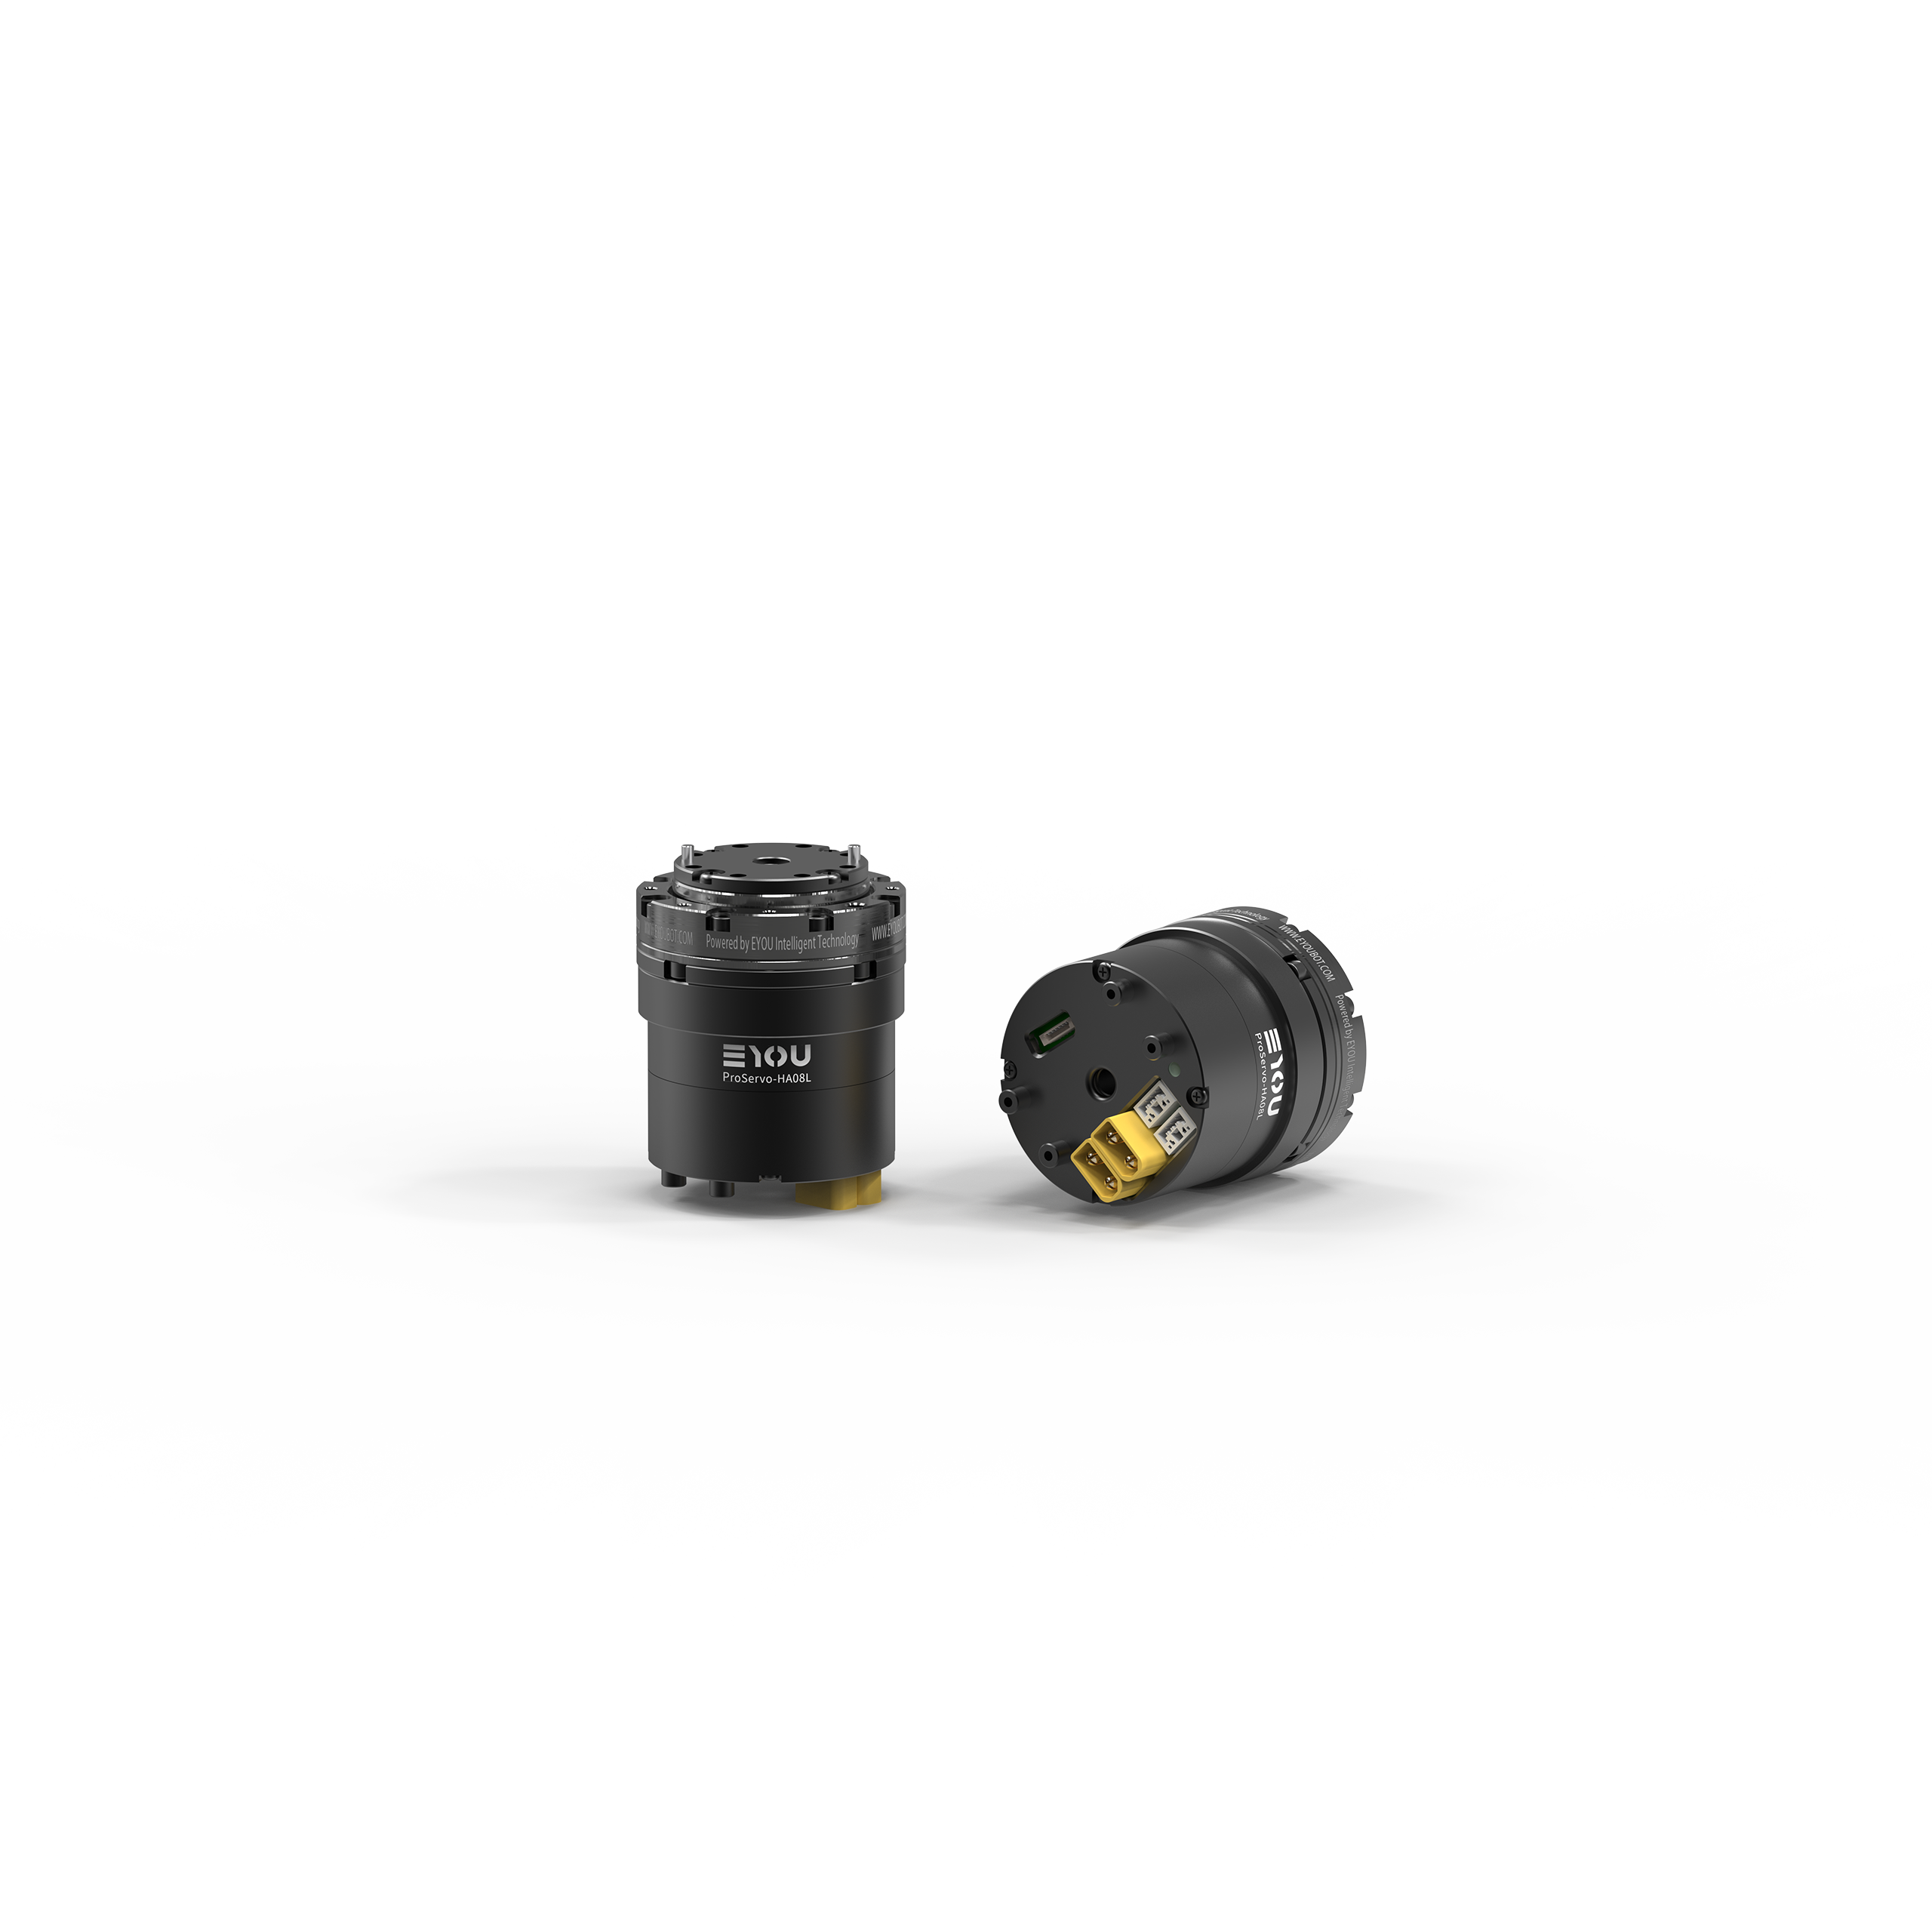
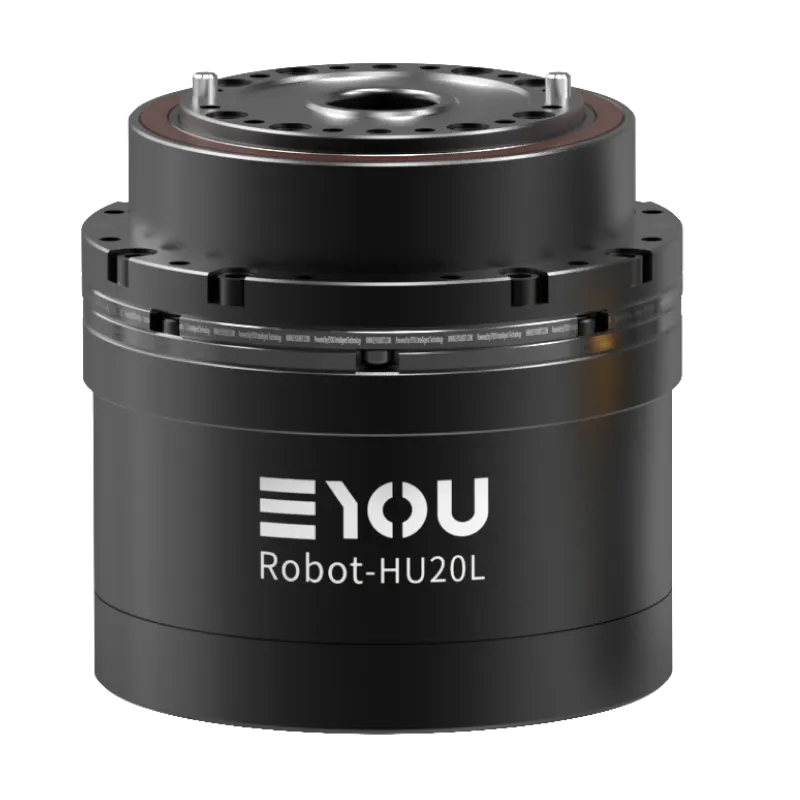
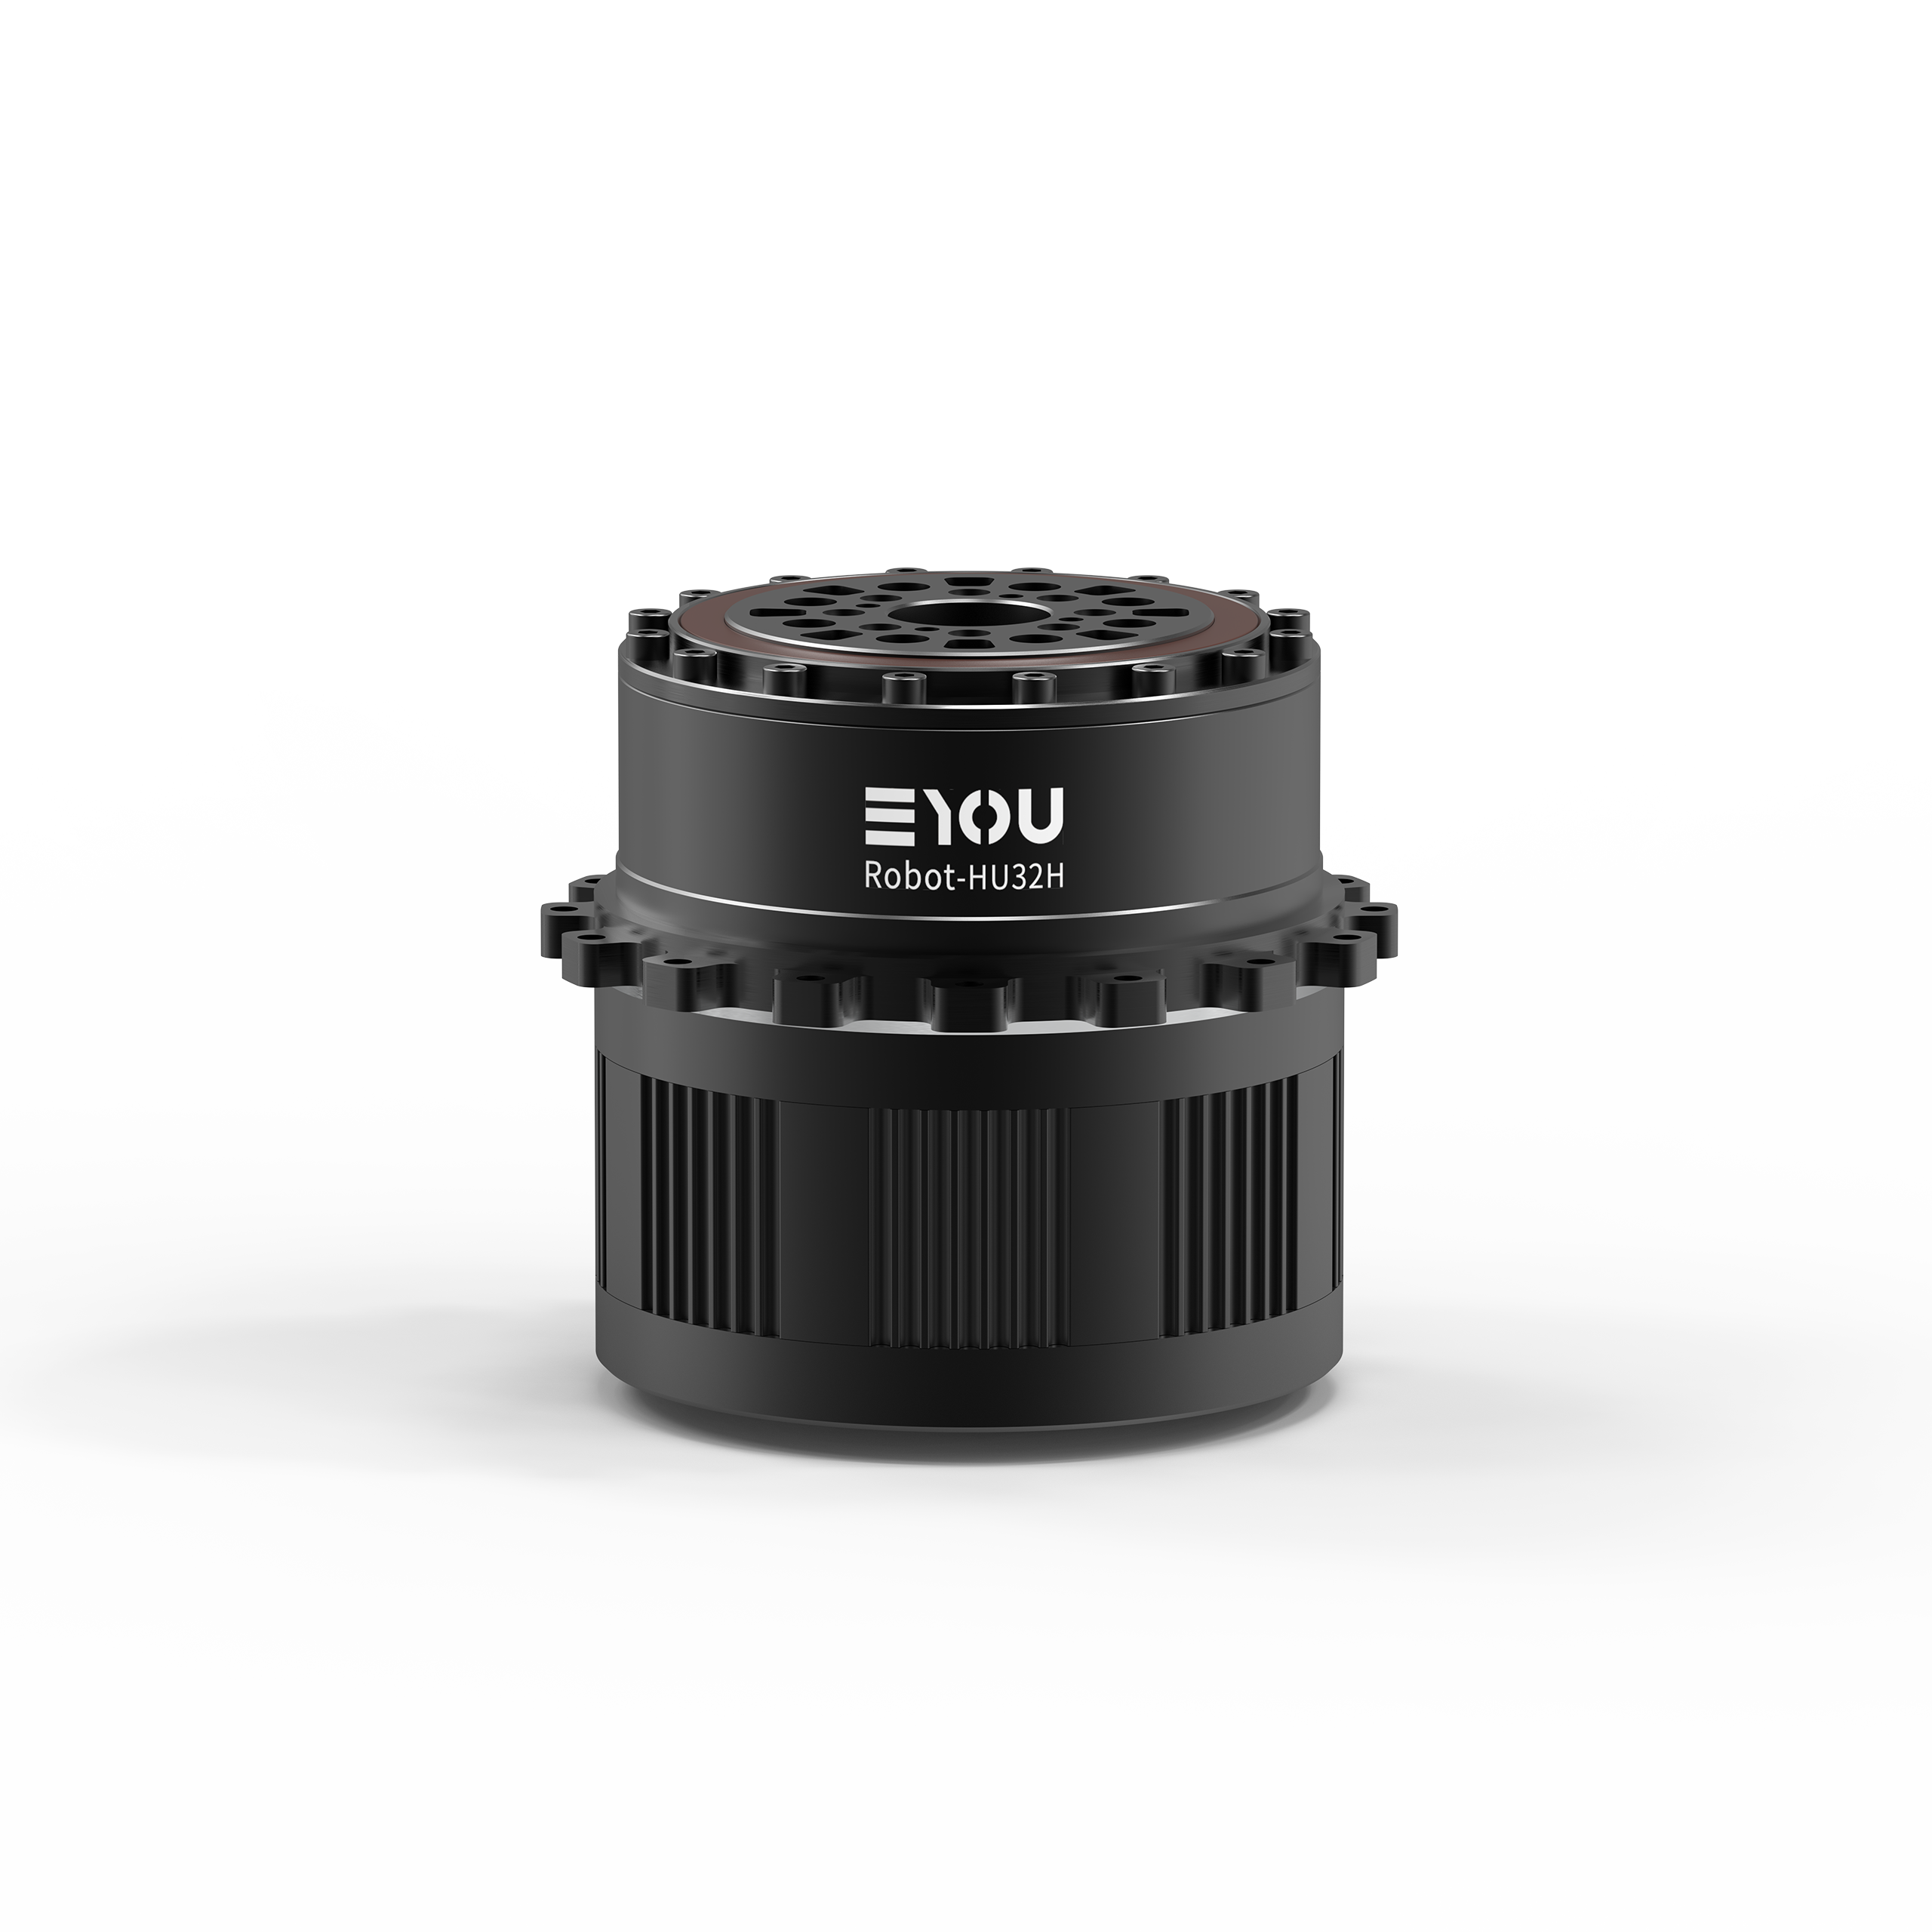
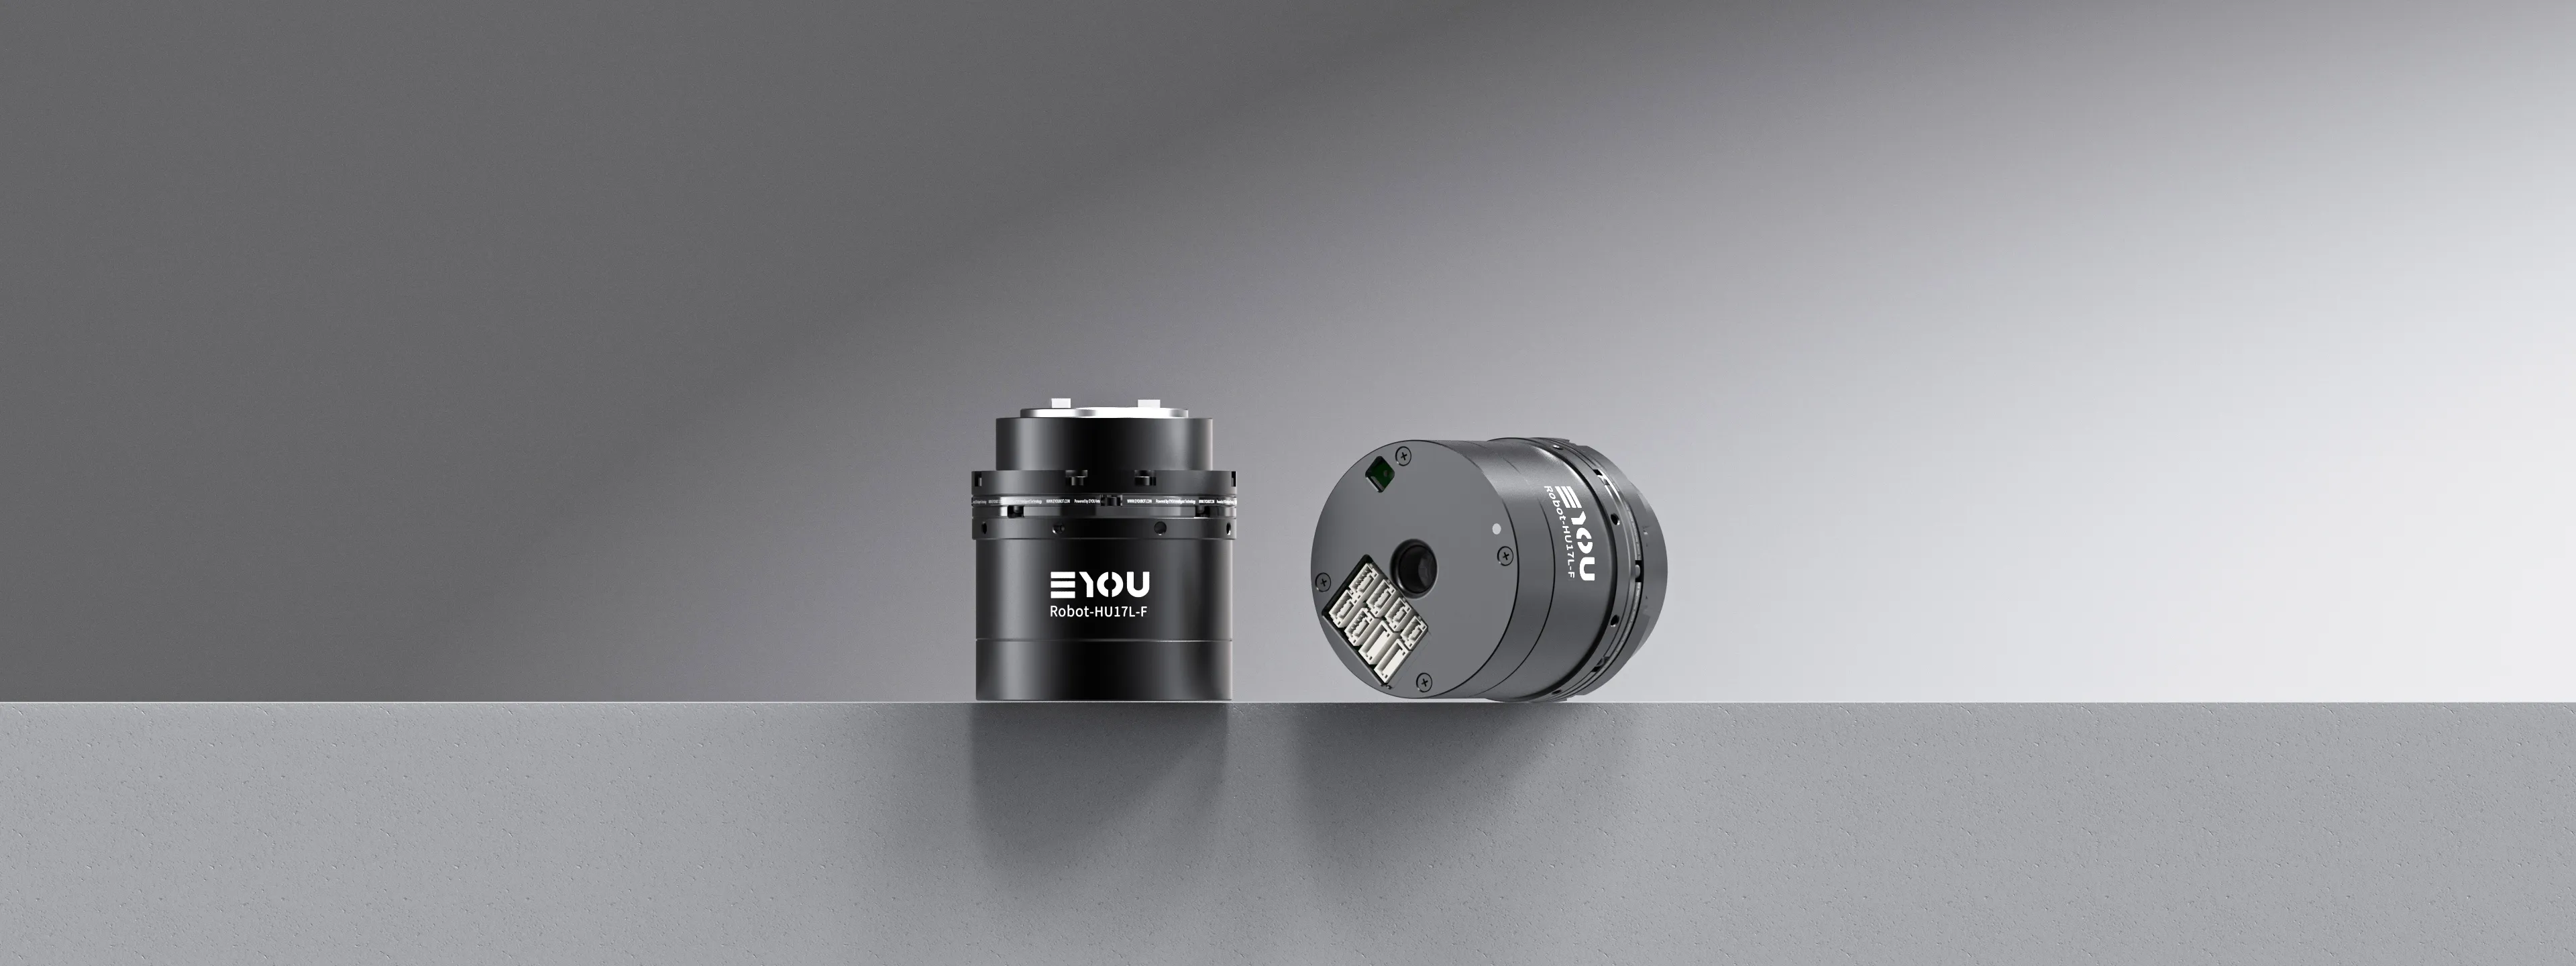
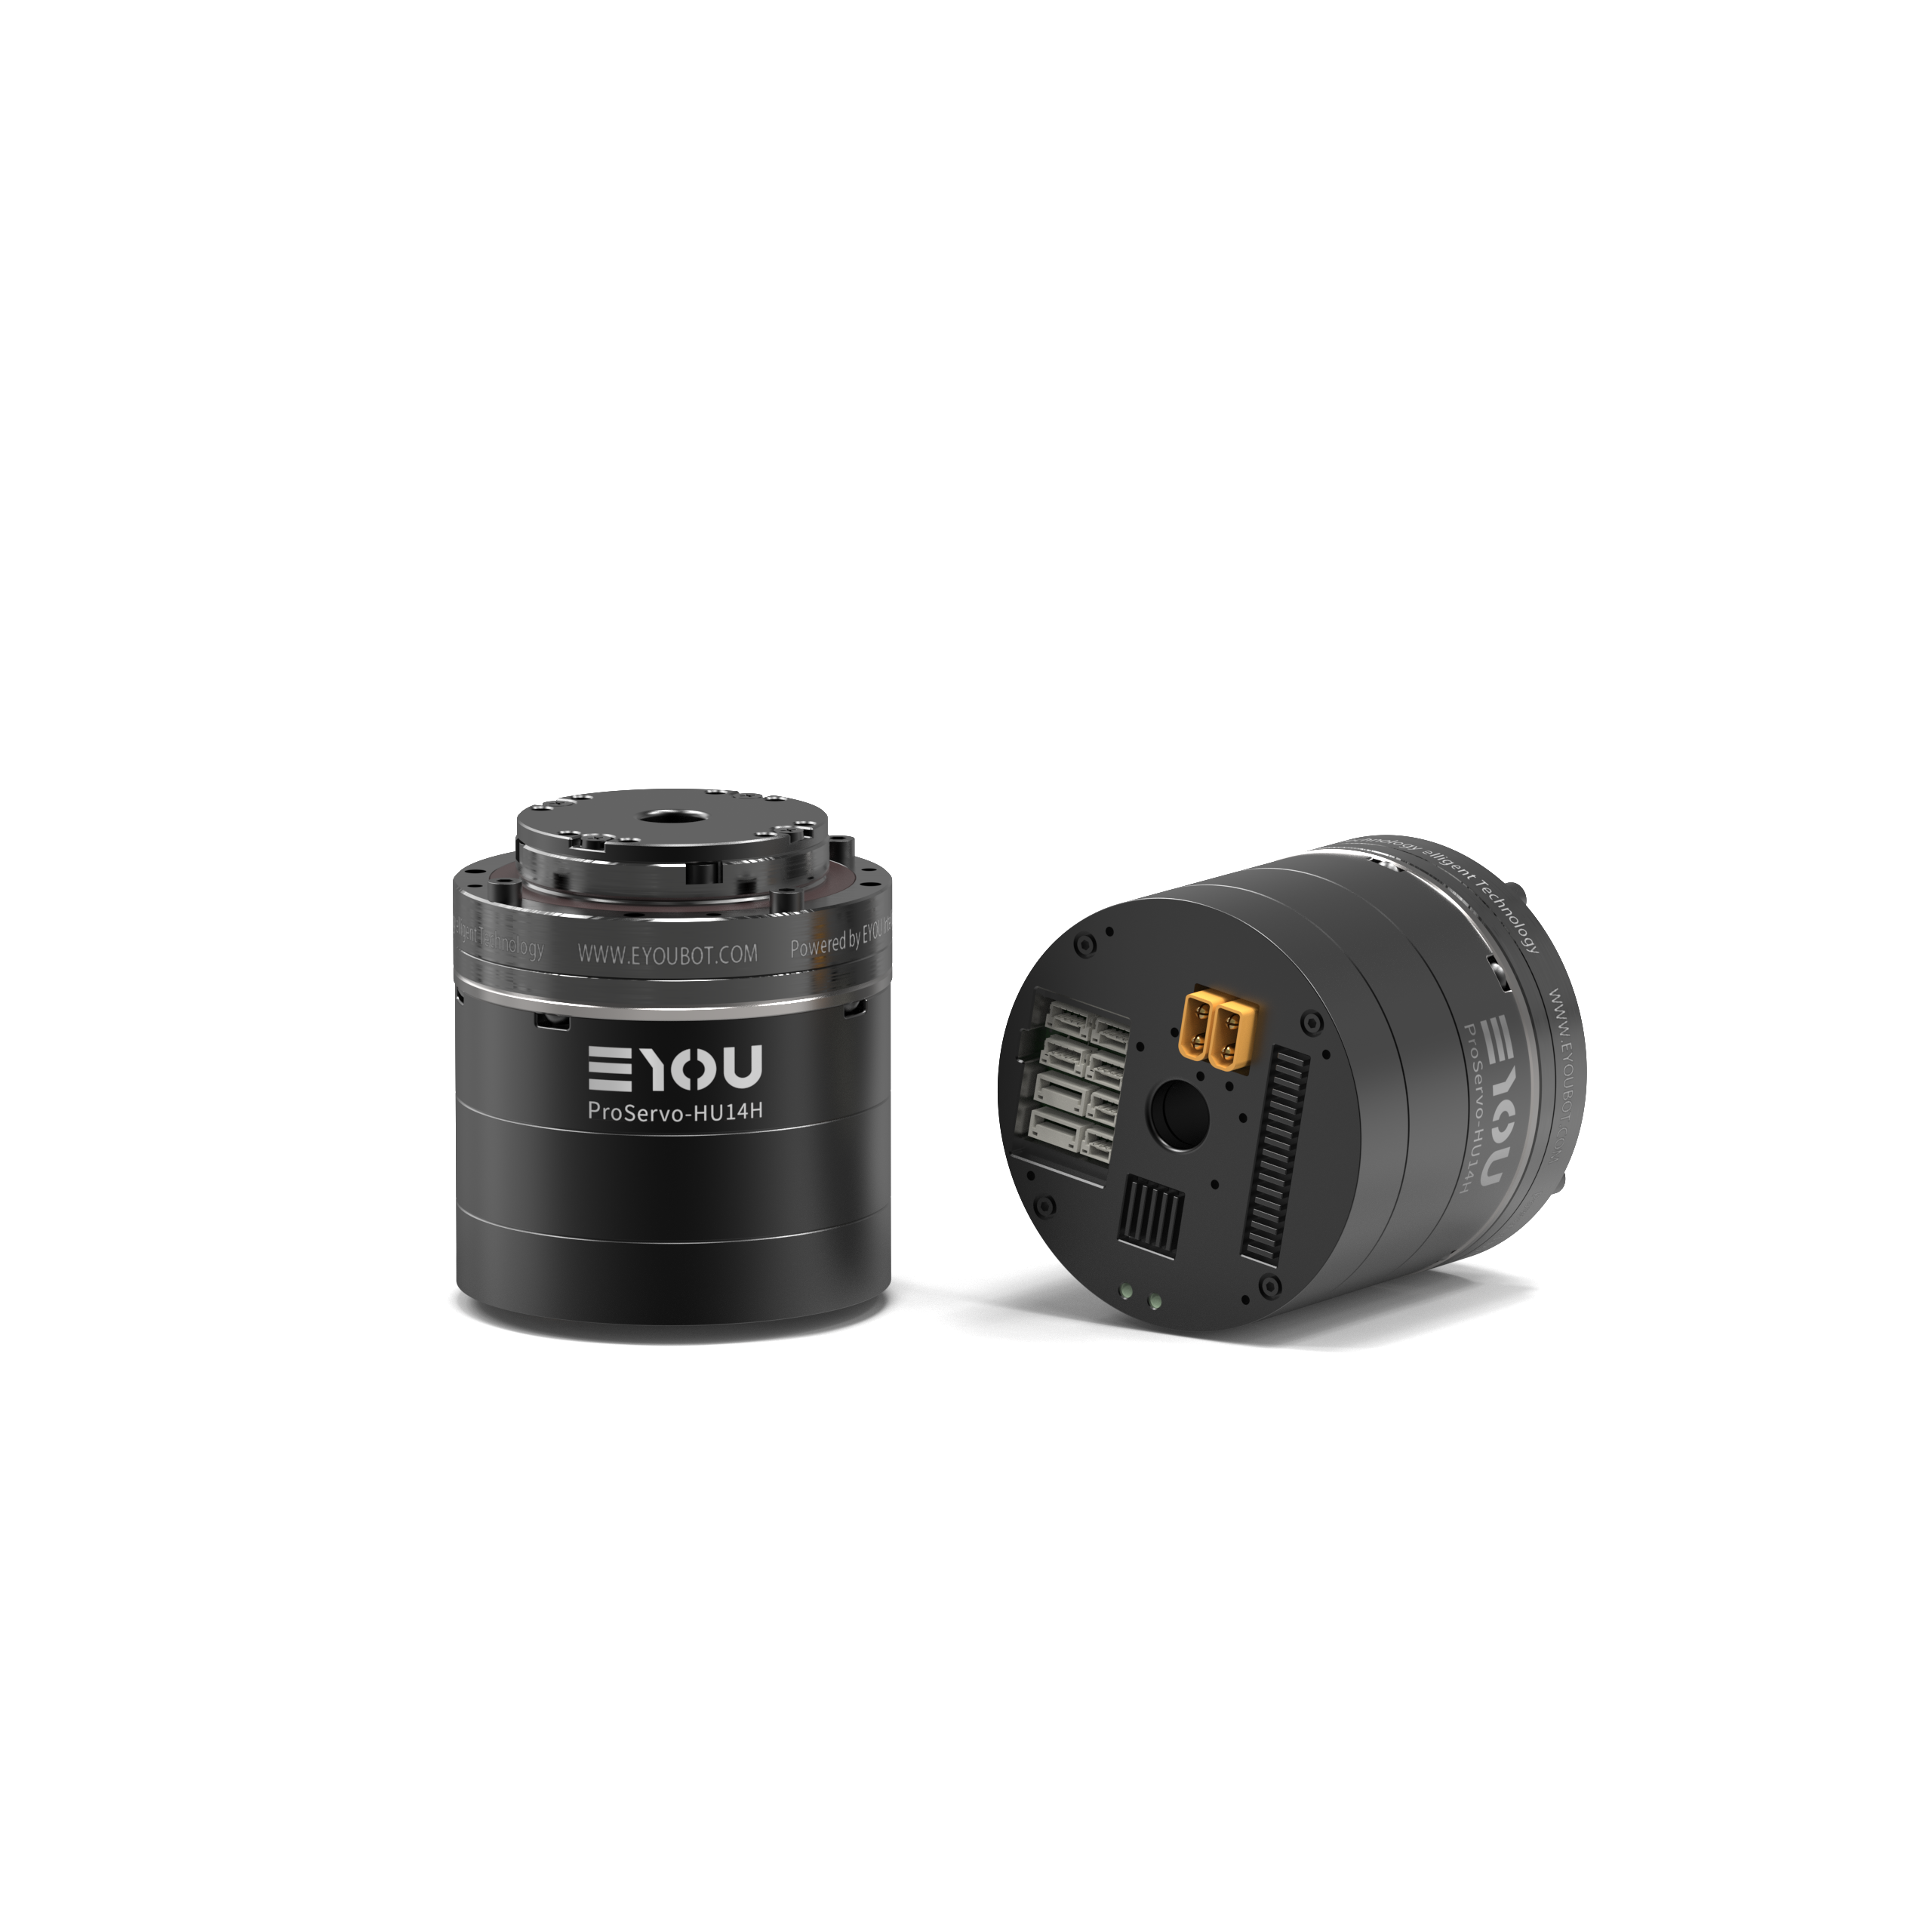
Compact harmonic joint module for humanoid and collaborative robot joints.
Specifications
| Reduction ratio | 51 / 101 |
|---|---|
| Rated torque | 1.8 / 2.4 N·m |
| Peak torque | 6.6 / 9 N·m |
| Rated speed | 60 / 30 rpm |
| Operating voltage | 14–42 V |
| Backlash | 15 arcsec |
| Communication | EtherCAT / CAN |
| Technical extension | 40 mm diameter; 4.4 mm inner diameter; 19-bit dual magnetic encoder; optional power-off brake; -20~80 °C |