I'm going to tell you something.The shadows
Robot Foreigner reported on November 10 that yesterday, Ingrid launched an open-source world mouse action model at the international top conference in the field of robot learning, CoRL 2026.The GR00T 2 series,There are two versions of GR00T 2 and GR00T 2 Turbo.
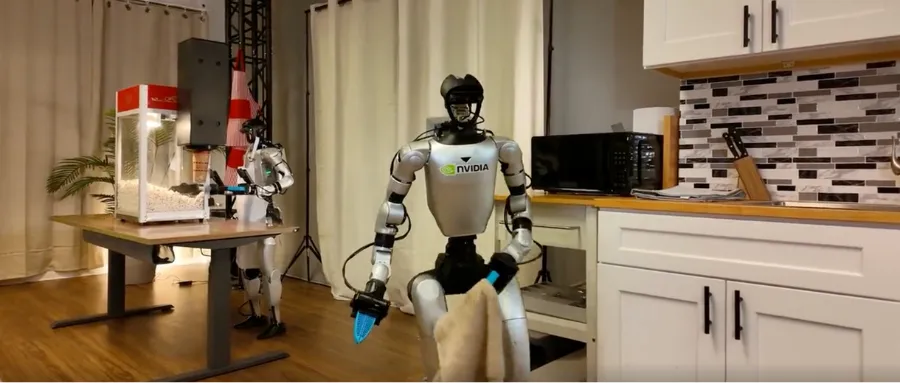
GR00T 2Mainly generalizing and fine-tuning capabilities, available for parallel claw, dexter hand and man-made robots;GR00T 2 TurboIt can be deployed directly on the Yuke's G1 by upgrading the running speed with smaller parameters, taking only a little time each time it is reasoned.124 millisecondsIt can control robots walking, bending, reaching out and moving.
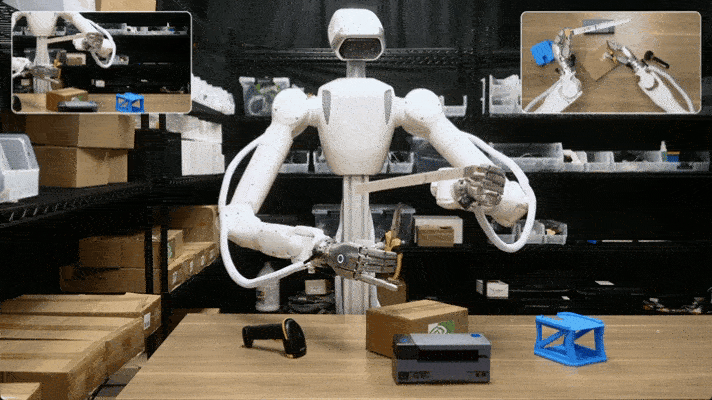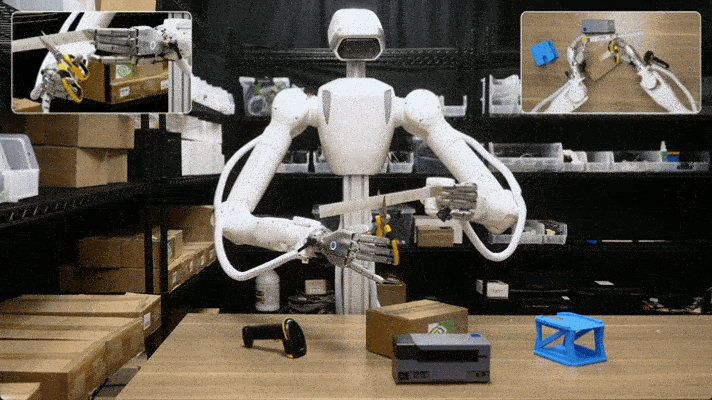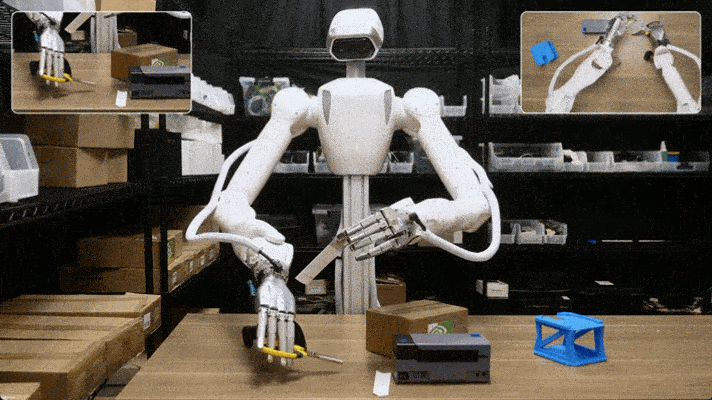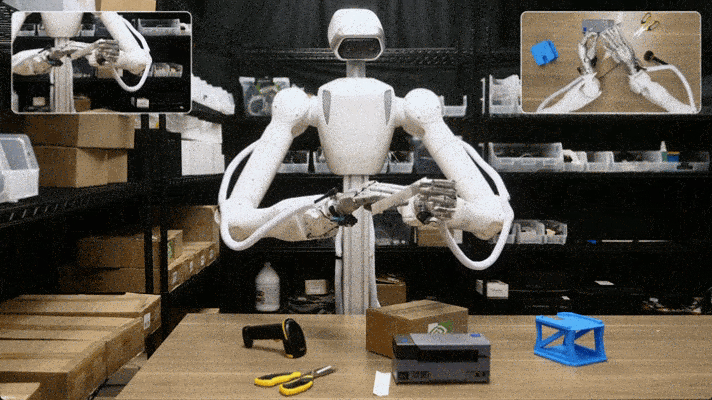
In the video shown by Ingrid,The GR00T 2 is a sophisticated robot that can perform chemical experiments with gloves, head-mounted cameras, and wrist cameras.After accessing the reasoning model (System 2), the GR00T 2 allows the YAM machine arm to continuously assemble three toys, with at least 97 successful trials of 100 toys each. However, from the video, although the machine arm completed the task, the operation process was played at 16 times the speed, the entire video still lasts more than 30 minutes, and the actual execution efficiency is still improved. The GR00T 2 Turbo Utrecht G1 completed the operation of cleaning the floor of the towel, then putting the towel in the washbasket.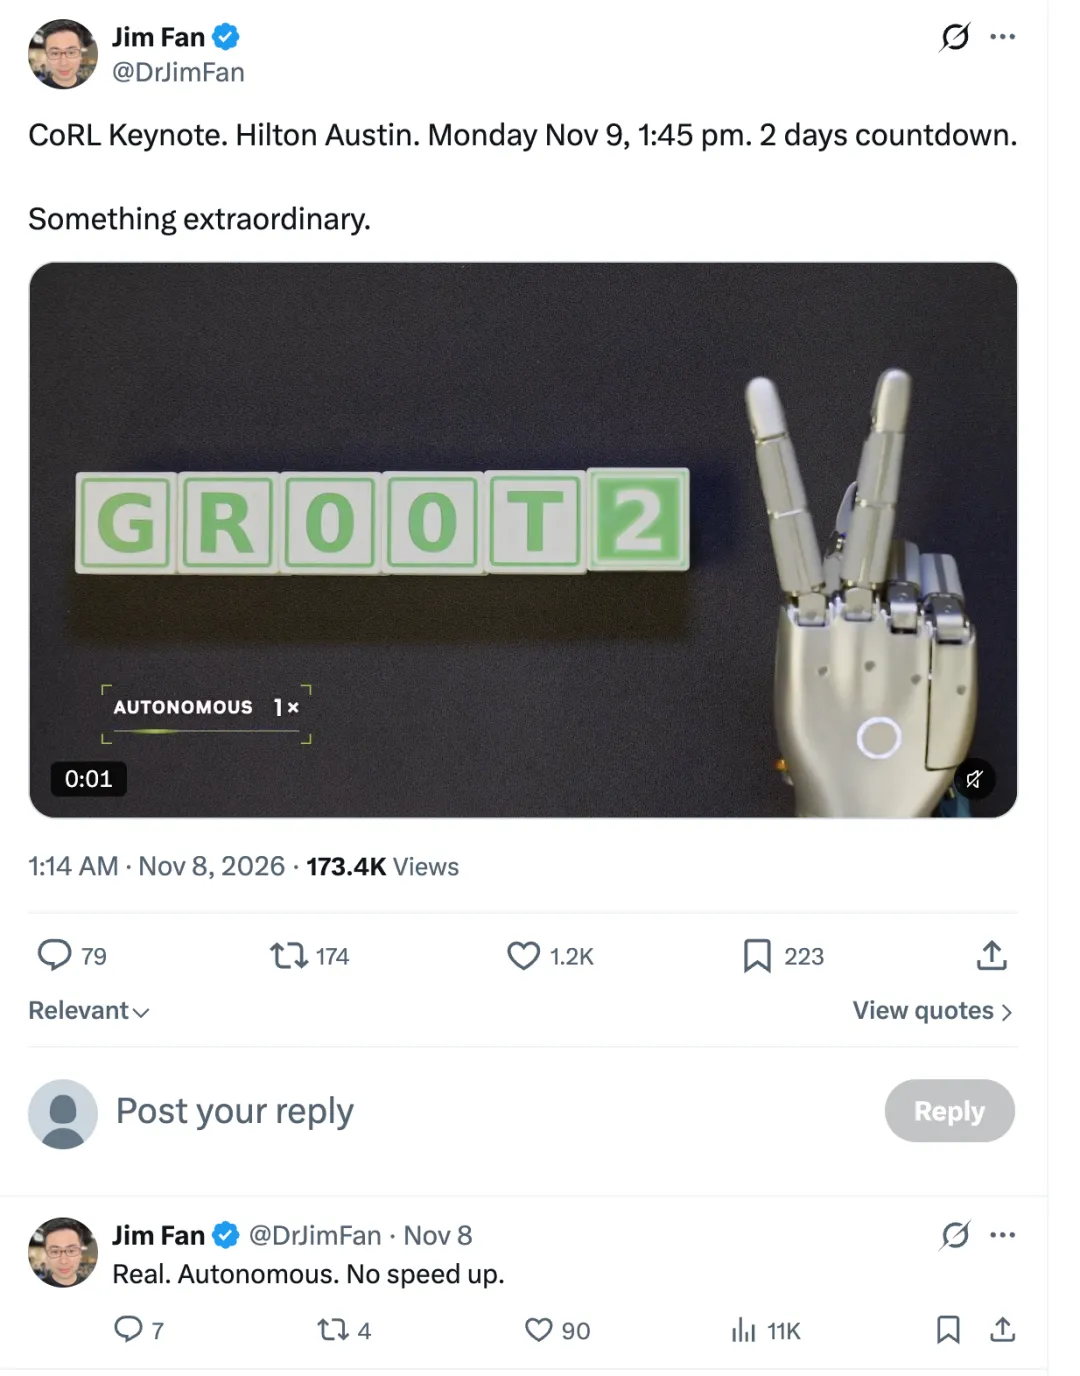 Jim Fan posted on Twitter that GR00T 2 is the latest in the series.A masterpieceReal. Autonomous. No speed up.)
 Below the post announcing the results, some netizens believe that the technological development of human robots is impressive.
 Some netizens have also claimed that chickens are better than chickens.
 But there are also expectations that Intel will reveal more critical information, such as data to improve the success rate of model missions, whether it comes from the same robot or human data.
 It has also been suggested that its open-source approach benefits small robotic teams in saving costs. Jim Fan, in introducing the model to CoRL 2026, also concludes with an optimistic statement:The flame of hope is shining before your eyes.He believes that from now on, anyone can become a robot developer, and everything that moves will have autonomous capabilities, and in that blazing fire, summer is coming. According to Ingrid's tech blog, the GR00T 2 has four main capabilities that can be realized.X-Adaptability, small sample adaptation, Fast Adaptation, intelligent control, and Agentic Control.Visual Steering (VISUAL STIRING)
01.
There are three ways to achieve cross-body migration.Less samples to adapt to new tasks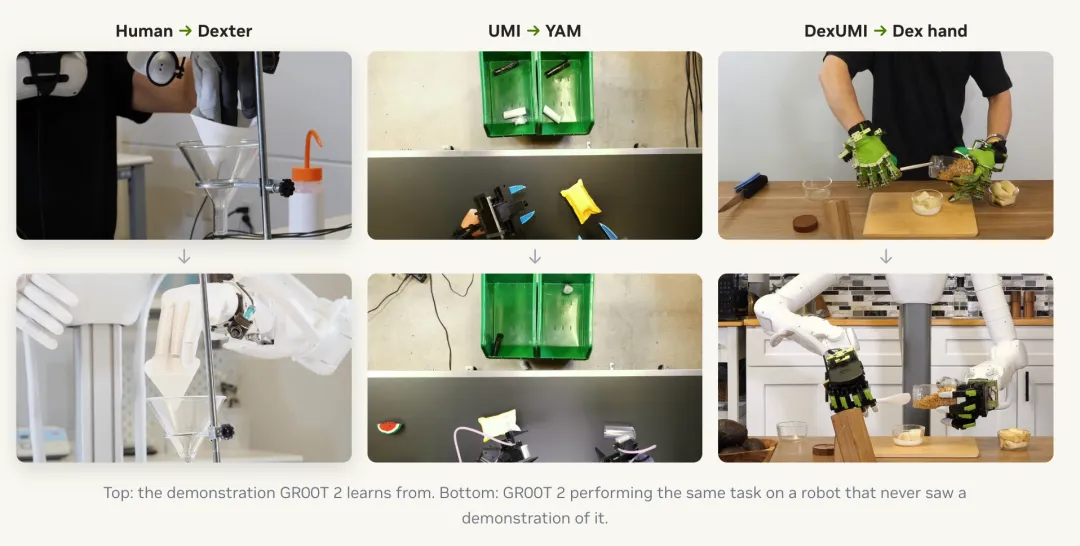
GR00T 2 is the first to demonstrate the ability to migrate across bodies (X-Adaptability). The robot itself does not have to demonstrate this task, and GR00T 2 is able to use this ability to learn human video and other robot data.
Specifically, it supports three modes of migration.
The first is to turn humans into robots.In chemical experimental missions, humans demonstrate wearing gloves, head-mounted cameras, and wrist cameras, while skilled hands learn how their bodies look and move by freely exploring data unrelated to specific missions.
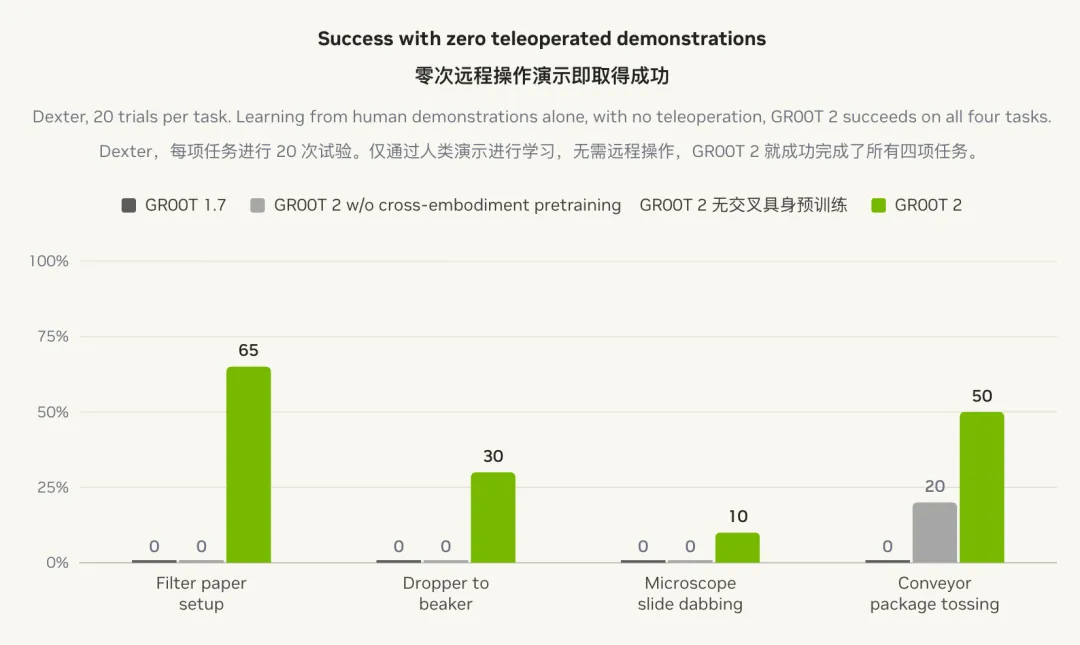
The GR00T 2 is still successful in four missions without the use of remote-operation demonstrations at all:65%It's like putting a drip tube into the burning cup.30%The microscope's glass is lightweight and lightweight.10%The packaging on the conveyor belt was tossed.50%。
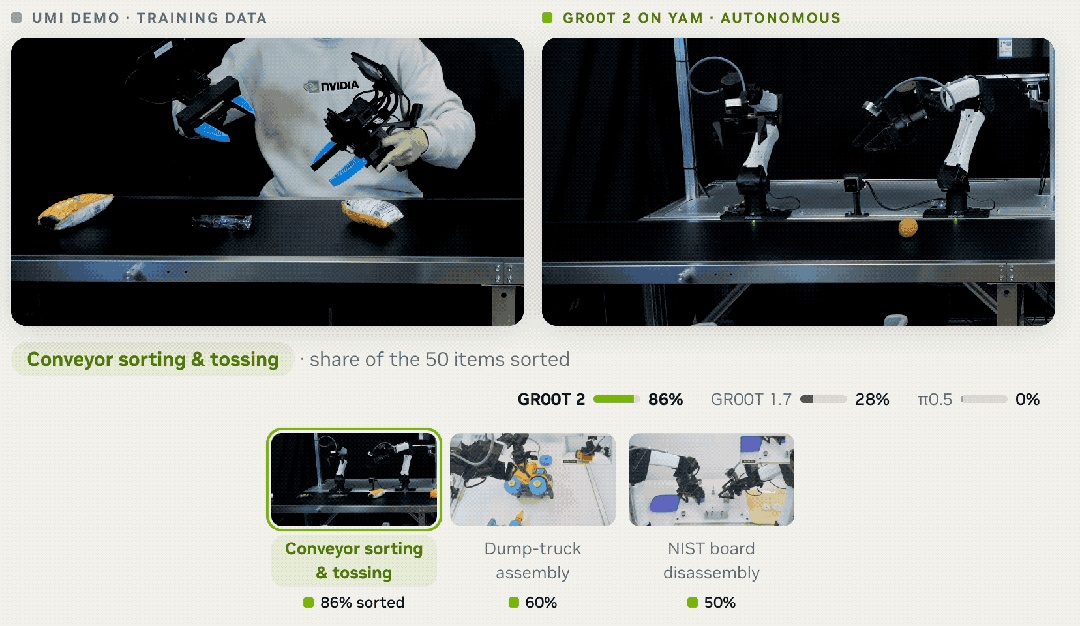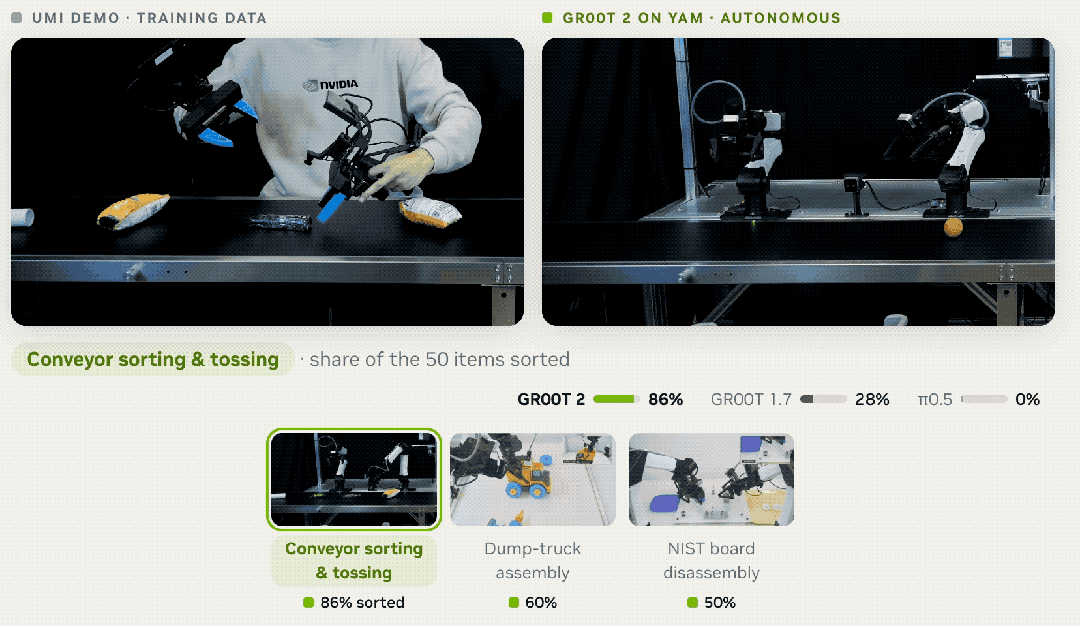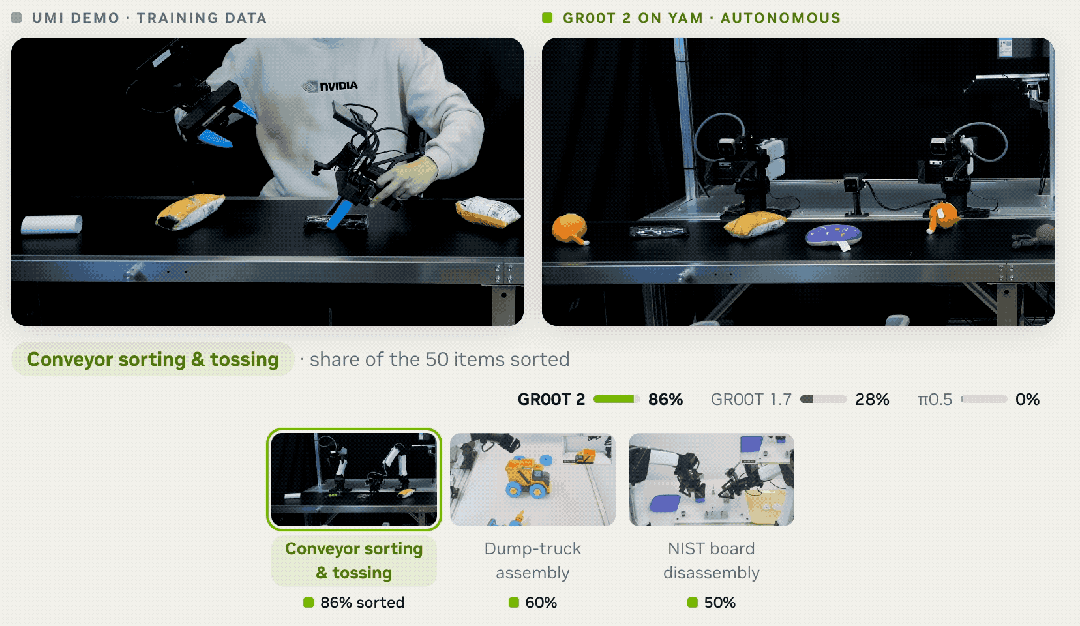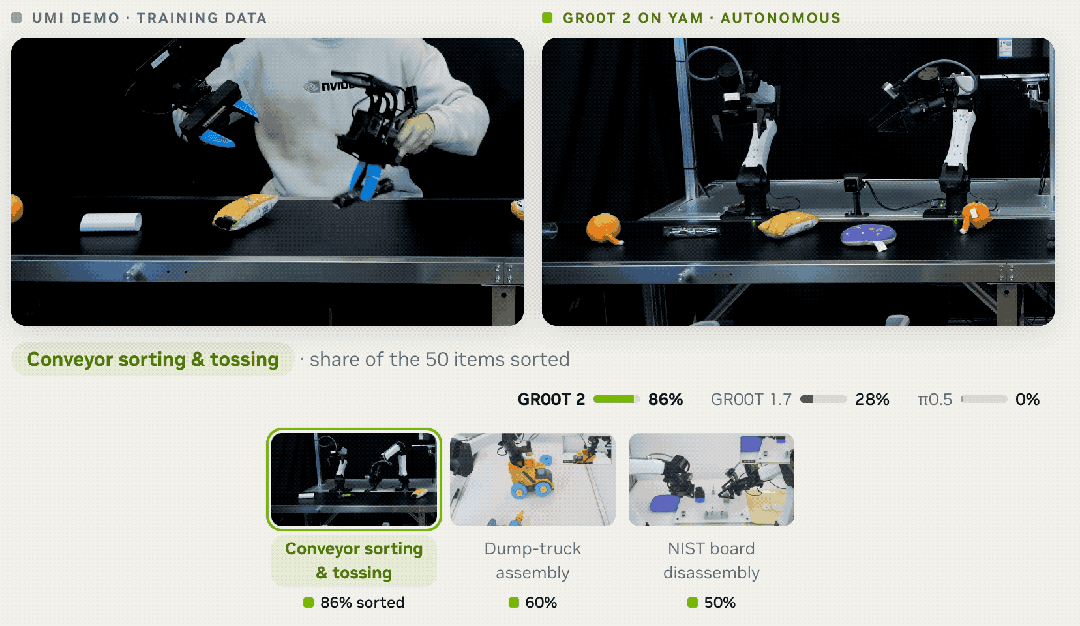
The second is the hand claw to the mechanical arm claw.In the three main tasks of delivering belt sorting and throwing, toy self-unloading truck assembly, and dismantling NIST boards, Ingrid only demonstrated the model with the handheld GEAR UMI claw.
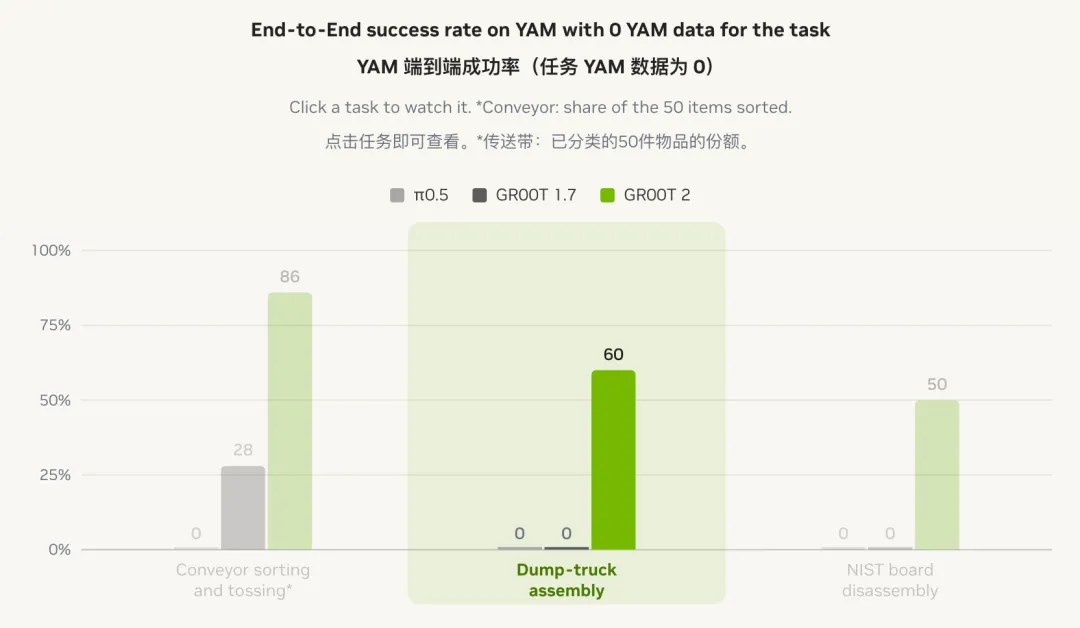
Real machine demonstration data for GR00T 2 deployed on the YAM mechanical arm without these missions were eventually obtained.86%, 60% and 50%The success rate.

The third is wearable equipment to robotic handles.GEAR DexUMI is a wearable exoskeleton compatible with robotic arm joints that can map human arm movements directly to the robot.
With the DexUMI demonstration alone, the GR00T 2 enables the robot with two XHAND1 smart hands to learn three hands-on tasks: make champagne yogurt, extract granular paste, and light the fireplace under the burner bottle and put the fireplace in the water to put out.
Cross-bodied migration mainly addresses the problem of how skills are transferred from one body to another.A small sample adapts (Few-Shot Adaptation)Further answers were given to how the model can improve task success rates at a lower cost.
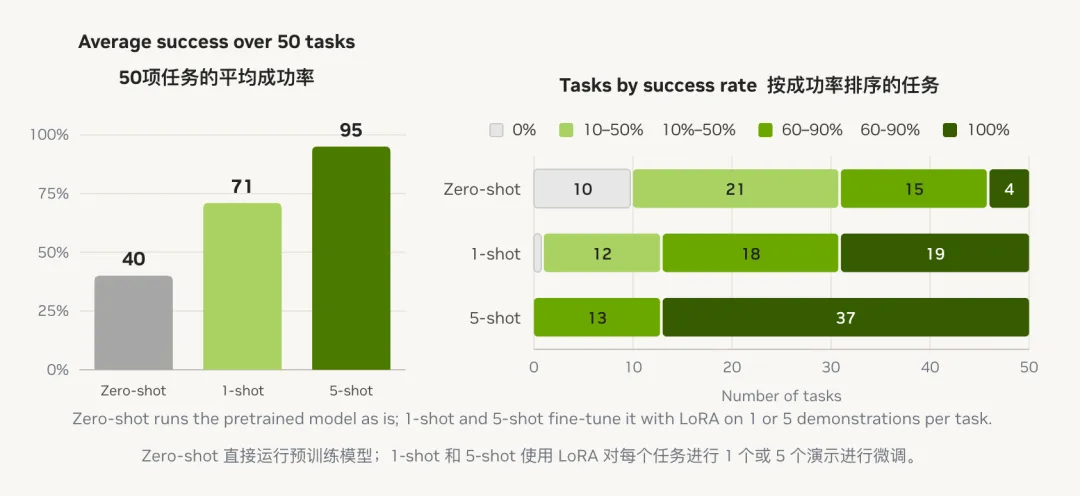
The team selected 50 missions that no target robot has ever seen. These missions appear only in data from other robots or human videos, while the target robot is a robot equipped with two Sharpa hands.
It's not.This is the first time I've ever seen a video of the same name.Under the conditions of GR00T 2, the test success rate was achieved by mission instructions alone.40%It was a success at least once in 40 of the 50 missions.
Invidia found that most failures were not due to the model's misunderstanding of the task, but to the inaccuracy of its execution, and that robots were able to do the right steps in the right order, only to miss a step.
A small amount of targeted robot data can fill this gap.
According to the report, the average success rate for each mission is increased to one sample per mission.71%After providing five samples, the average success rate rose to95%Of the 50 missions, 37 were successful in each trial.
The company also added that every adaptation requires a 30-minute LoRA ((Low-Rank Adaptation) mitigation on a single RTX 5090.
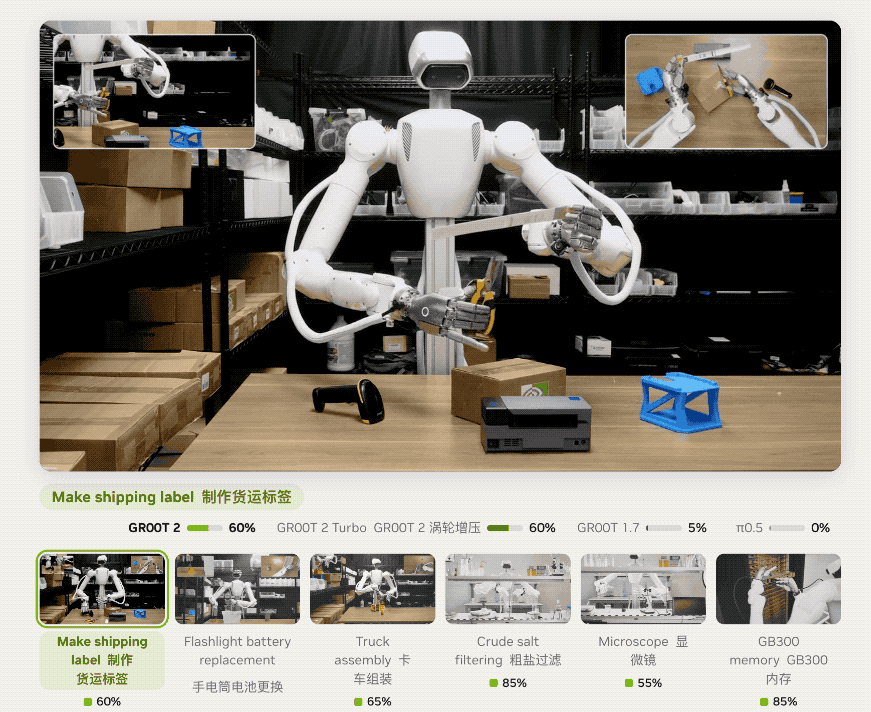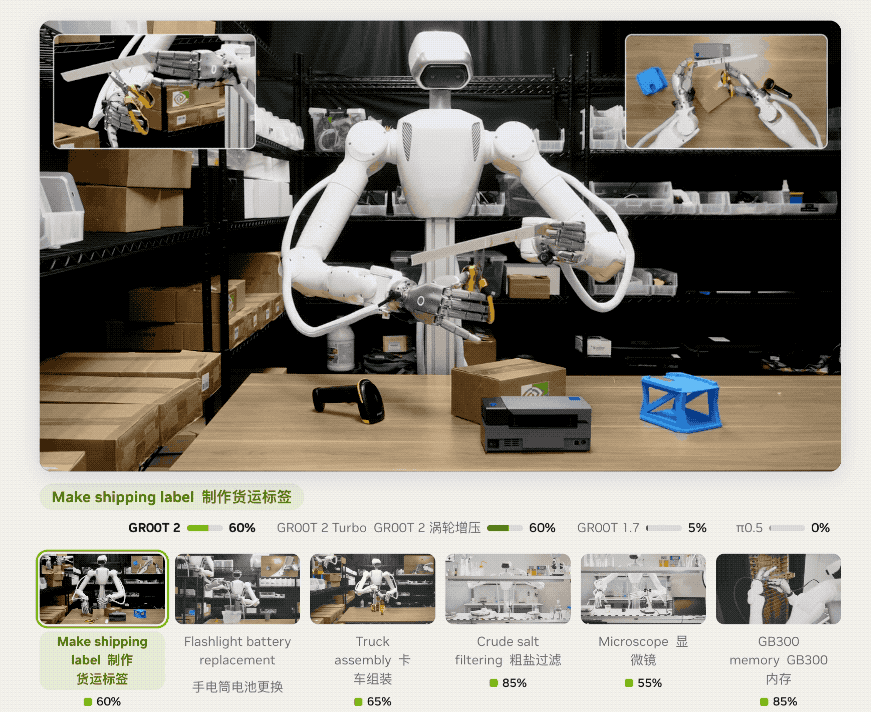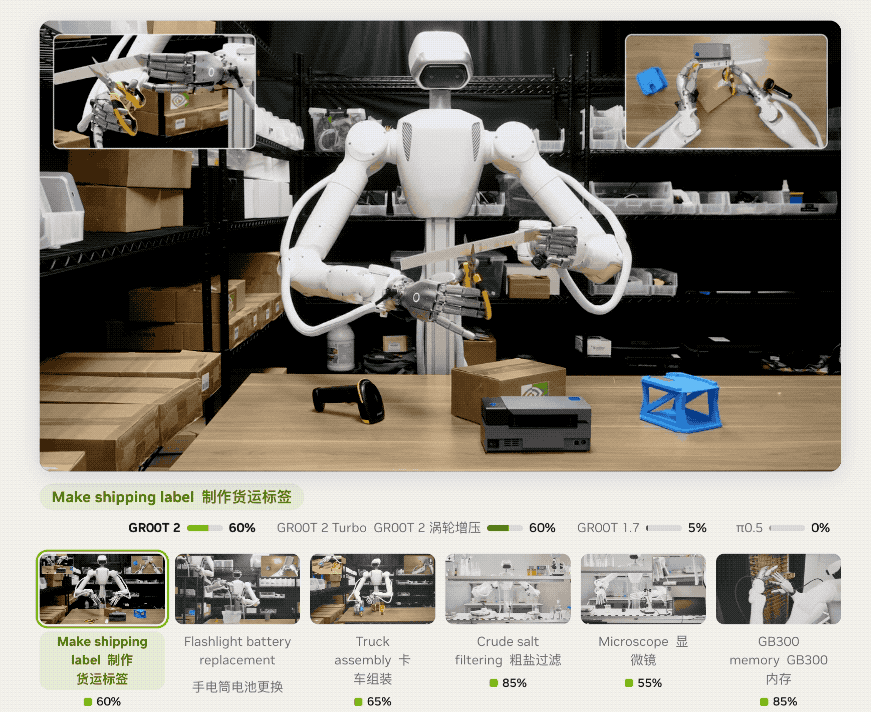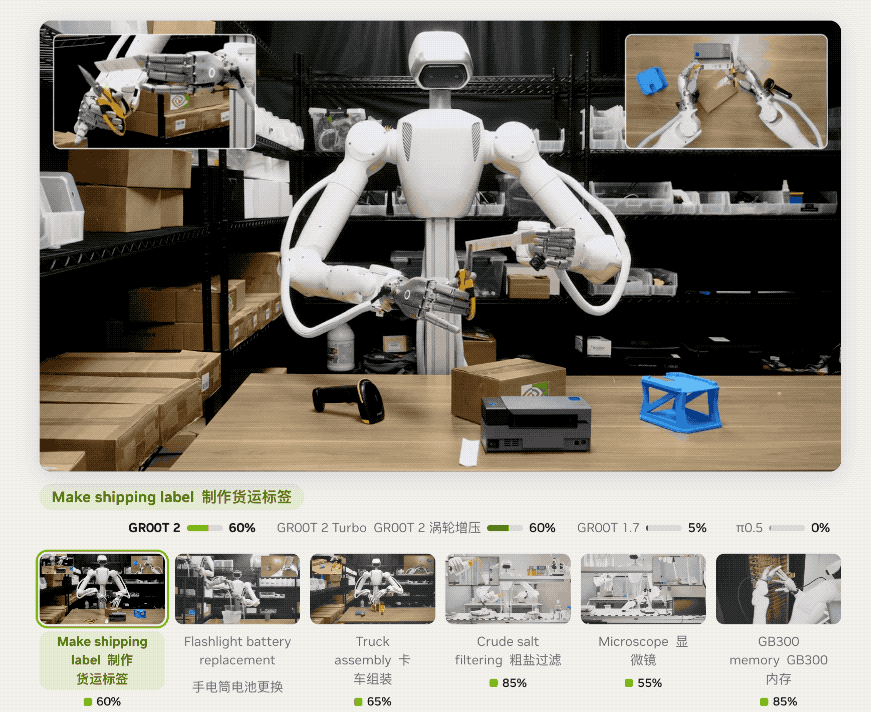
Post-training also plays a role in tasks that require more precise operations.
Gr00T 2 uses two Sharpa hands with 22 degrees of freedom to complete sophisticated operations, such as labeling packaging, replacing parts, assembling toys, and end-to-end chemical experimentation.
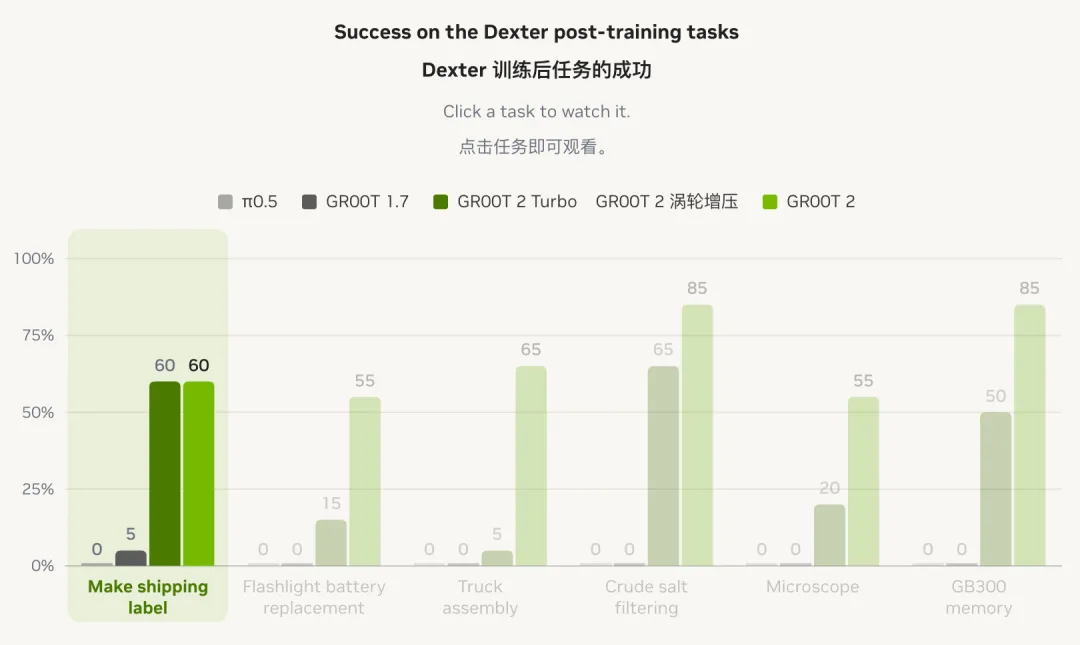
Among them, the success rates of producing and pasting freight labels, replacing hand-held cylinder batteries, assembling trucks, crude salt filtering, microscope operation and inserting GB300 memory modules were:It's about 60 percent, 55 percent, 65 percent, 85 percent, 55 percent and 85 percent.
02.
It's a good idea to use Agent to make up your mind.And how to use visual programming to catch a mouse.In addition to single skill sequence growth tasks, robots also have to deal with the problem of understanding task planning, failing recovery.Let the front-end reasoning agent collaborate with the robotic model.
The intelligent organism decides what to do with the mouse, which is responsible for dismantling tasks, checking progress and writing code; GR00T 2 decides how to do with the mouse, which performs a large number of interactive operations that are difficult to write in script.
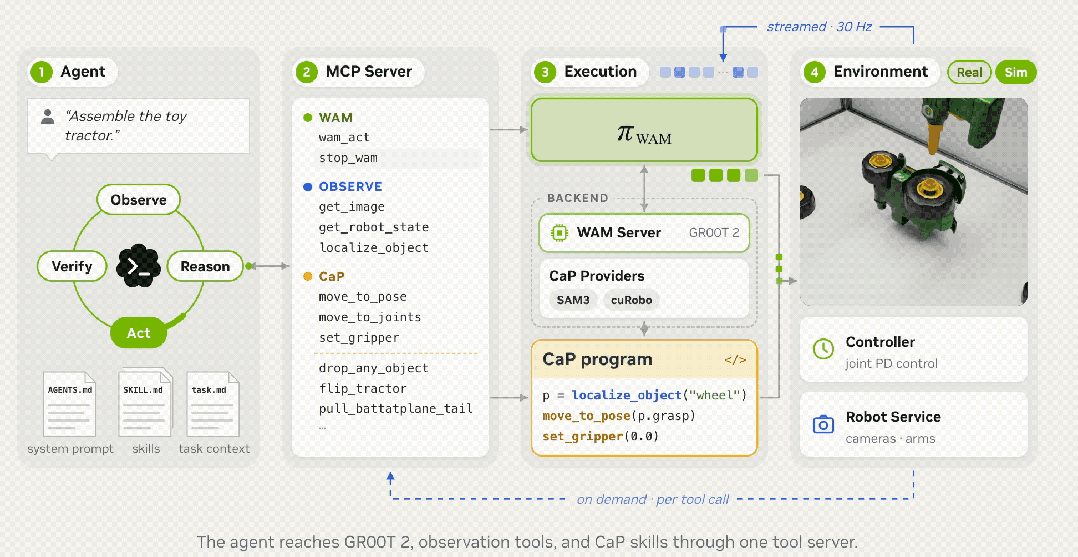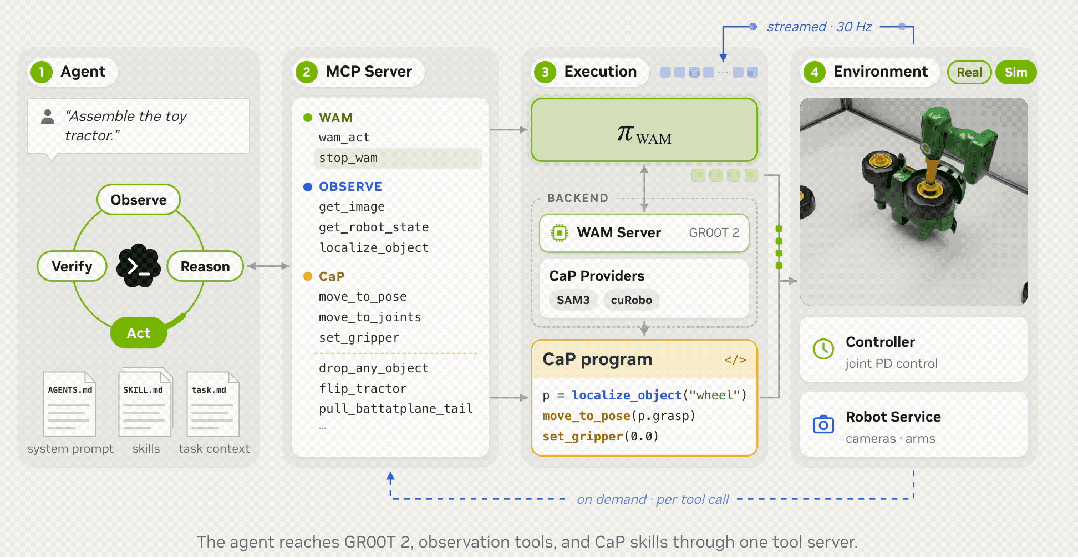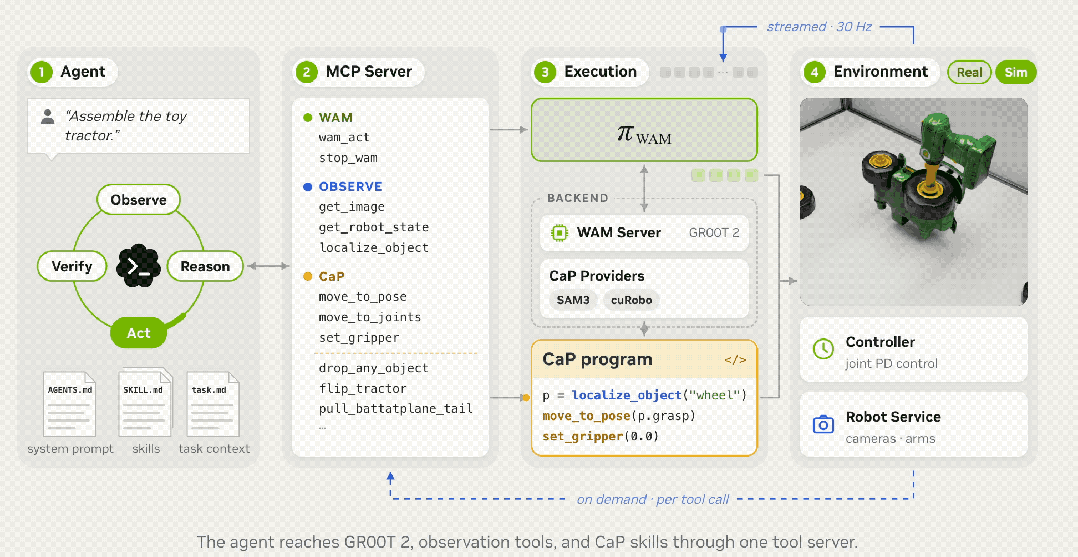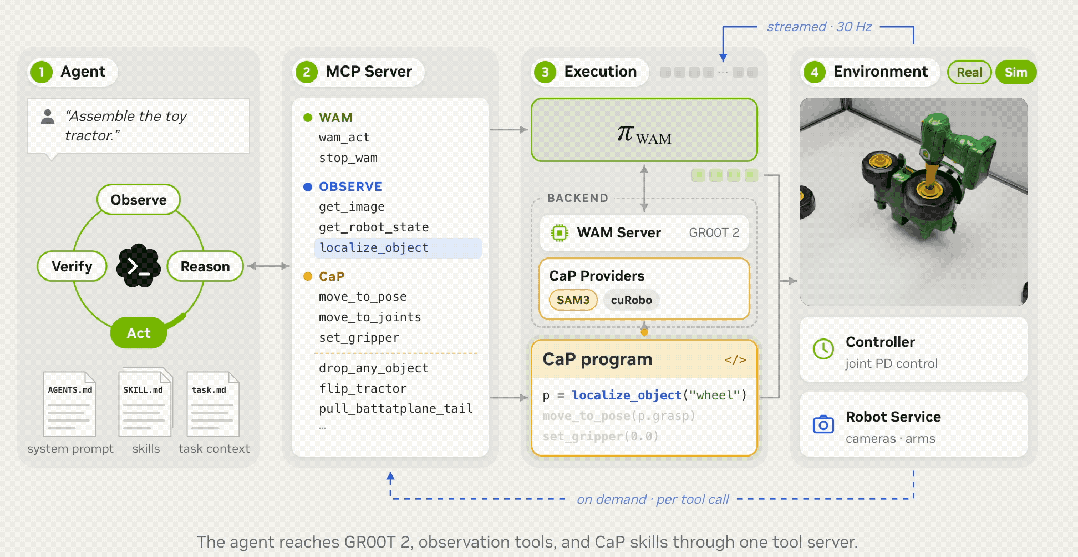
It's the world's most popular video game, and it's the world's most popular video game.Smart entities can use GR00T 2 as a tool to use it in conjunction with camera images, robot status, and code-as-policy (CaP) skills.
On the physical robot, the GR00T 2 completes most of the operations, and the Intelligent continues to monitor the implementation. Once the parts fall off or progress stagnates, the Intelligent Body calls the CaP skill recovery scene learned through ASPIRE and returns control to the GR00T 2.

Before each test, all the parts were dropped on the table, creating a messy layout that has never been seen in post-training data.
Under these conditions, when the GR00T 2 is equipped with a smart body, assembling toy planes, toy trailers and Hot Wheels toy cars,In the 100 trials, he was successful 98 times, 97 times and 97 times respectively.
However, in terms of the length of the video, the GR00T 2 takes up more time and still has room to move away from the actual application.
Intelligences can also combine real-world reinforcement learning skills with longer tasks.
For example, inserting five Ethernet wires into a network switch or inserting five chargers into a designated socket.
In this process, CaP is responsible for positioning, grabbing and placing, GR00T 2 performs high-precision insertion movements, while the intelligent organism arranges the steps, validates the results, and invokes recovery skills when needed.
In the video, the mechanical arm is able to accurately position itself at the interface of the Ethernet line, completing the insertion operation, and the model will confirm the task and then perform the next operation after completion.
Following the success rate of replacing the surveillance strategy with GR00T 2 with reinforced learning training,The total number of successful cable missions increased from 12 to 19 times out of 20 and charger missions from 2 to 20 times.
While language instruction commands robots in chaotic environments, which may also be faced with target objects and performing uncertain actions, Ingrid introduced the GR00T 2 as a solution to the problem.Visual Steering capabilities。
Simply put, the planner can directly mark the grab and release points in the camera image of the GR00T 2 and execute the mechanical arm with different color differentiation, with the GR00T 2 then completing movements such as approach, grab, move and release.
At the end of each step, the planner re-observes, decides to continue, retest or stop. This function requires no additional training data, and the marking points can be extracted from the existing model's claws and hands, so the model can still run only with language instructions.
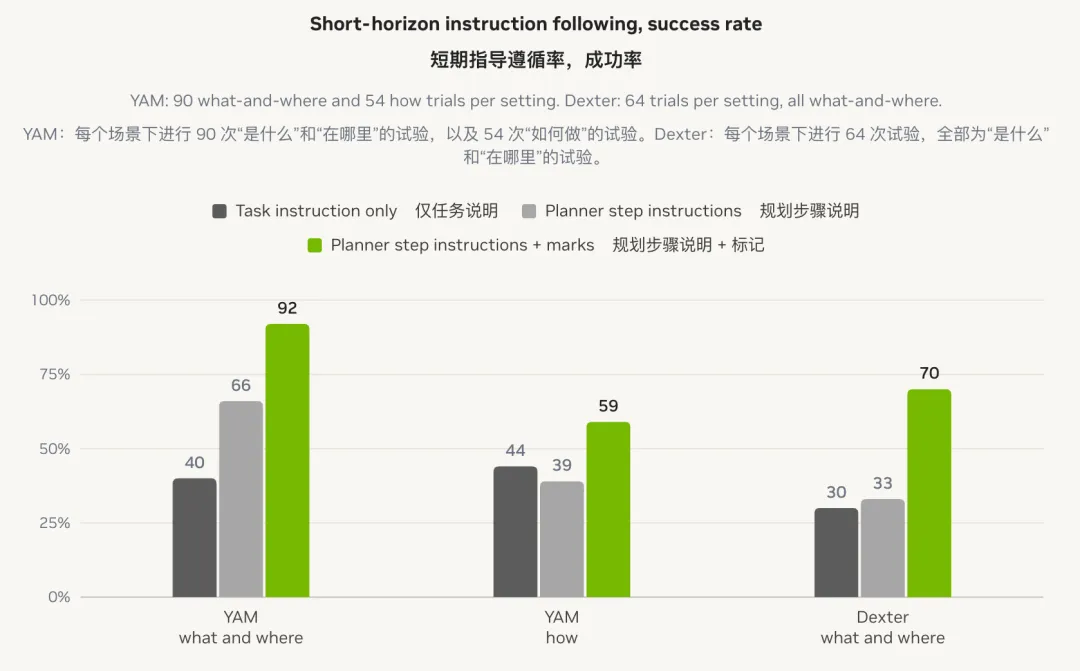
For short-range instructions on what to move and where to move, step-by-step instructions mark the success rate of YAM mechanical arm operation by providing mission instructions only.40%Upgraded to92%It's easy to use, but it's not easy.30%Upgraded to70%。
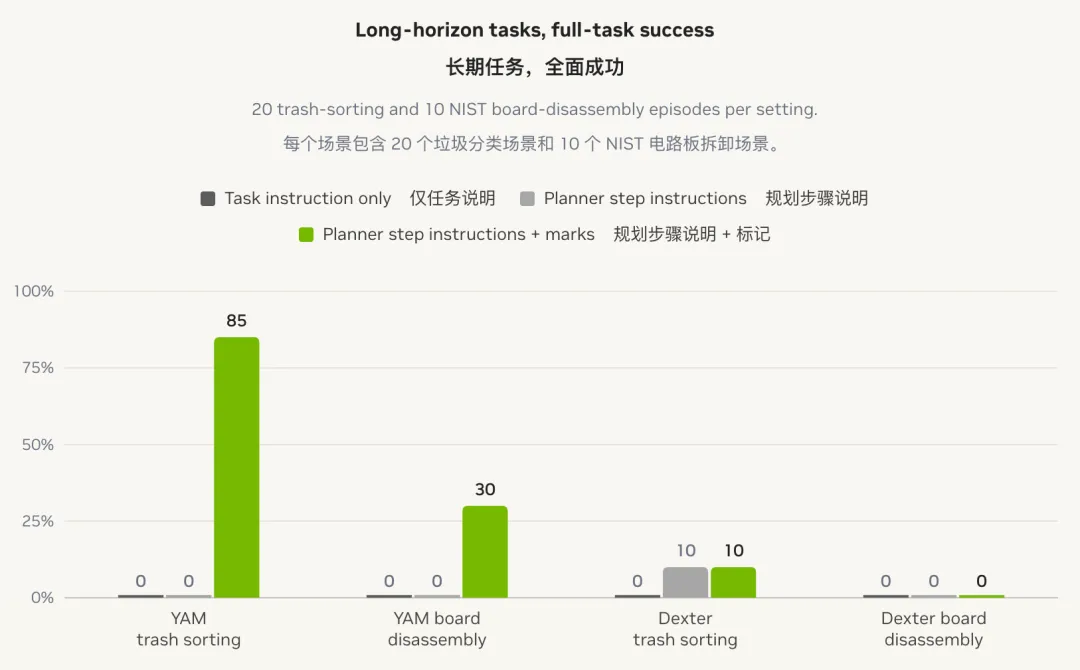
The gap in long-range tasks is even more pronounced. On the YAM mechanical arm, without labeling, GR00T2 is unable to complete a complete garbage classification or task board demolition, even with the programmer's step-by-step instructions; after adding the labeling, 20 garbage classification tasks have been completed 17 times, 10 circuit board demolition tasks have been completed 3 times.
However, Invidia also found that in the most sophisticated way, marking points can help robots sort out more garbage, but the model rarely completes the entire task, which is the current limitation of the system.
In addition, marking points cannot convey information about the final direction of an object, nor can they explain the relationship of motion between grabbing and releasing, such as dumping or wiping such complex motion information still needs to be expressed in language.
03.
It's been a long time since I've been able to do this.Commander Yuri G1 to clear the roomIn addition, the GR00T2 also introduces a more high-speed approach to humanoid robots.GR00T 2 Turbo。
In order to perform Whole-Body Loco-Manipulation, a humanoid robot must maintain balance while moving its entire body at high speed, while keeping its hands in place.
Turbo reduces modeling costs with small combined video-action Transformers and higher compression-rate video encoders, where the parameters of the combined video-action Transformer are only limited to:Two billion。
The smaller model still uses a similar architecture to the GR00T 2, but can run directly on the Utrecht G1.
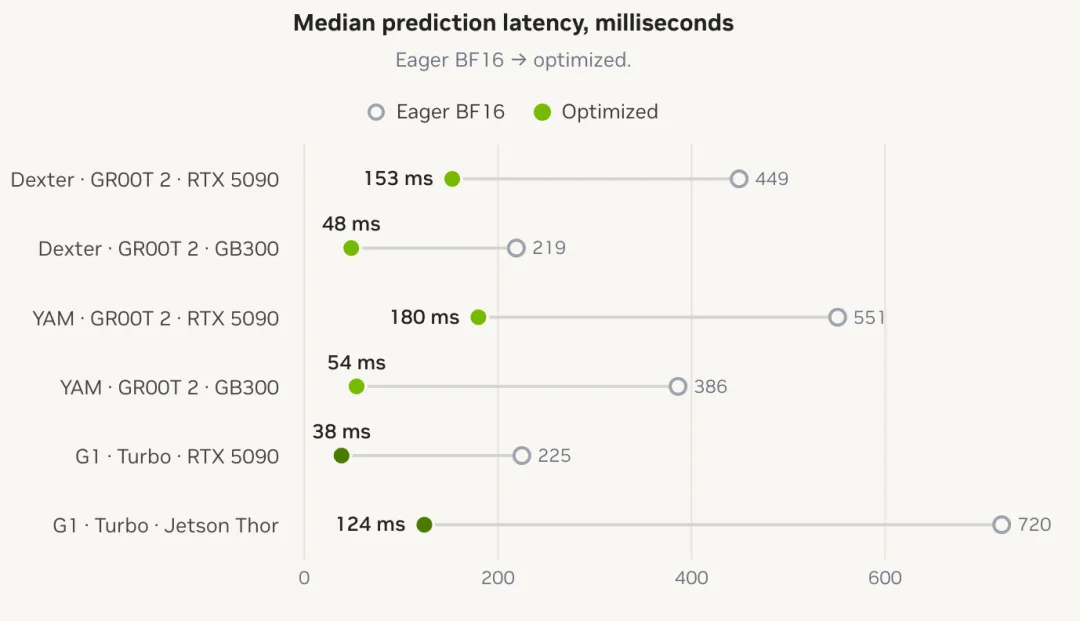
After optimisation, Turbo completed a reasoning for the G1, which was time consuming on the RTX 5090.38 millisecondsIt's time to get on the Jetson Thor.124 milliseconds。
As a result, the model was able to plan a full-body motion token block of about 1.6 seconds per second, and then execute it at a frequency of 50Hz by the full-body controller SONIC.
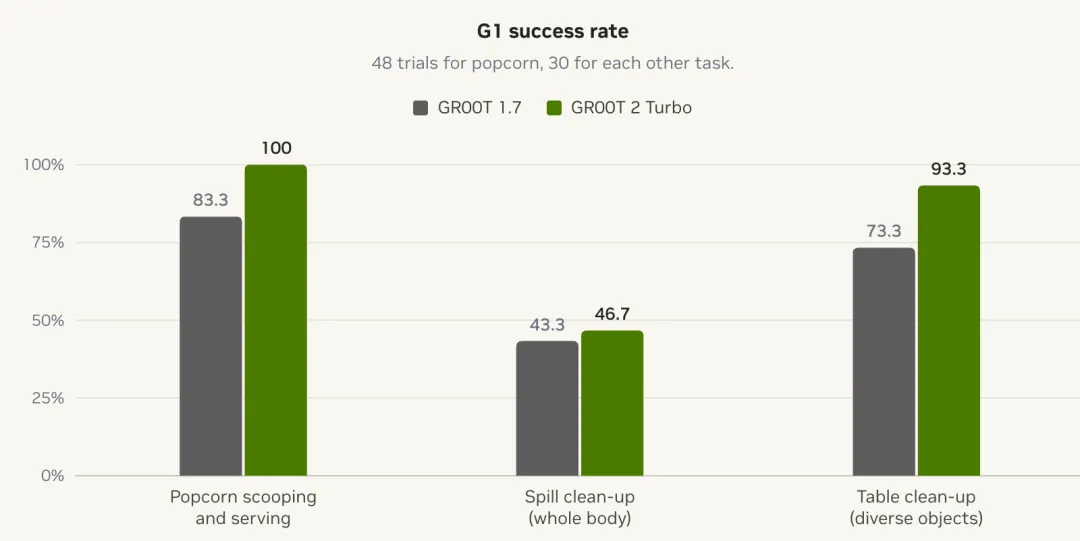
In real-world missions, the GR00T 2 Turbo controlled the G1 to extract and distribute popcorn, with 48 successful missions.46.7%The success rate of tasks for cleaning multiple items on the desk is93.3%The GR00T 1.7 has been upgraded.
From a video perspective, the G1's movements are more fluid, with fewer stops, and can last for several minutes, demonstrating a certain ability to perform long-range tasks.
04.
It's been a long time since I've been able to watch more than 400,000 hours of human video.Core based on DiT architectureIn training, GR00T 2 used three classes of pre-training data, including 402,730 hours of first-person video of human work, 10,184 hours of handheld UMI claw data covering 2,897 tasks, and 23,500 hours of robot remote control data.
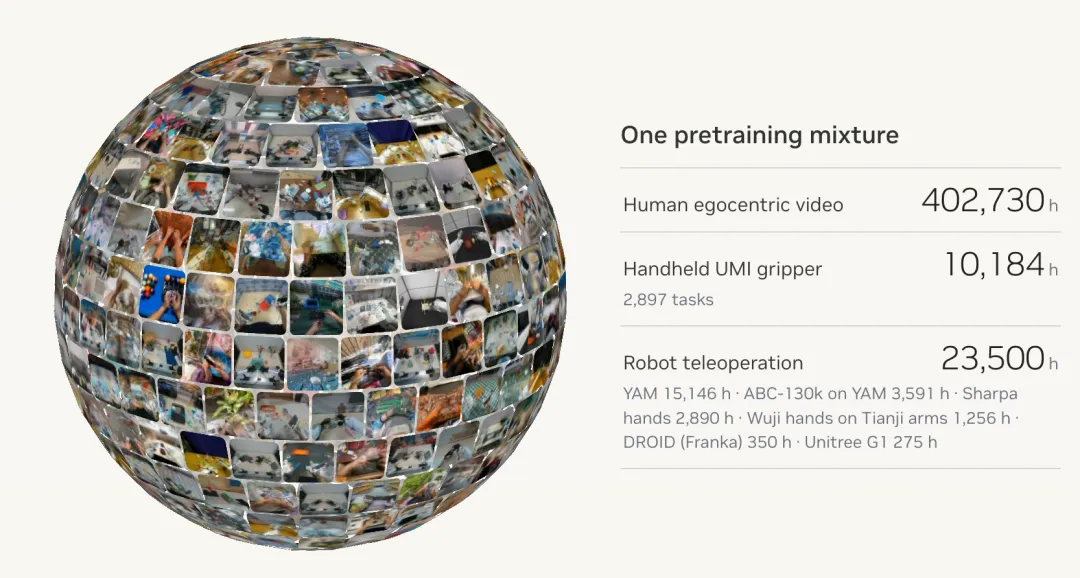
Among them, remotely operated data includes the parallel claw mechanism arms of YAM and Franka, Sharpa and Wuji, and the Yu Tree G1 humanoid robot. Human video comes from the first Human-1M dataset, which contains 1 million hours of human data, of which 100,000 hours have been available on Hugging Face in the form of Human-1M-100K.
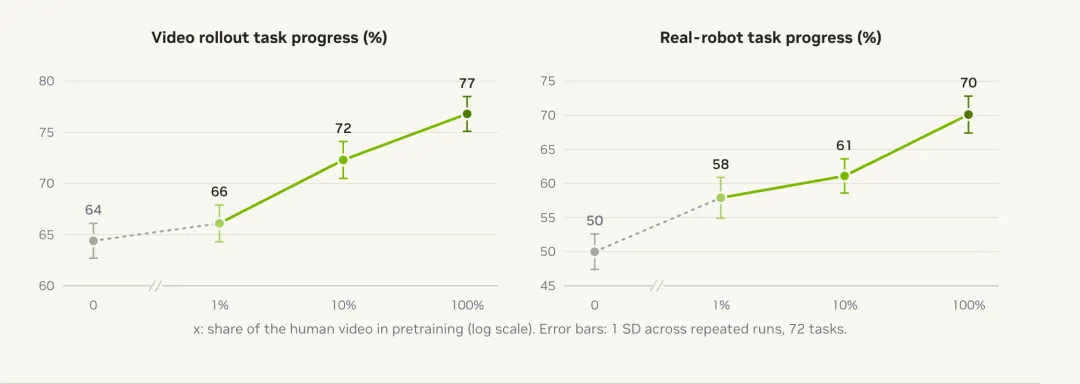
The scale of human video is also directly reflected in the performance of the task. The research team used human video pre-training models of 0, 1%, 10% and 100% respectively, and evaluated it on 72 agile operations tasks.
Data shows that as the proportion of human video data increases, the rate of mission completion of video strategies is increasing.64%Upgraded to77%The rate of completion of tasks by physical robots is50%Upgraded to70%。
The core of GR00T 2 is a Video-Action Diffusion Transformer.
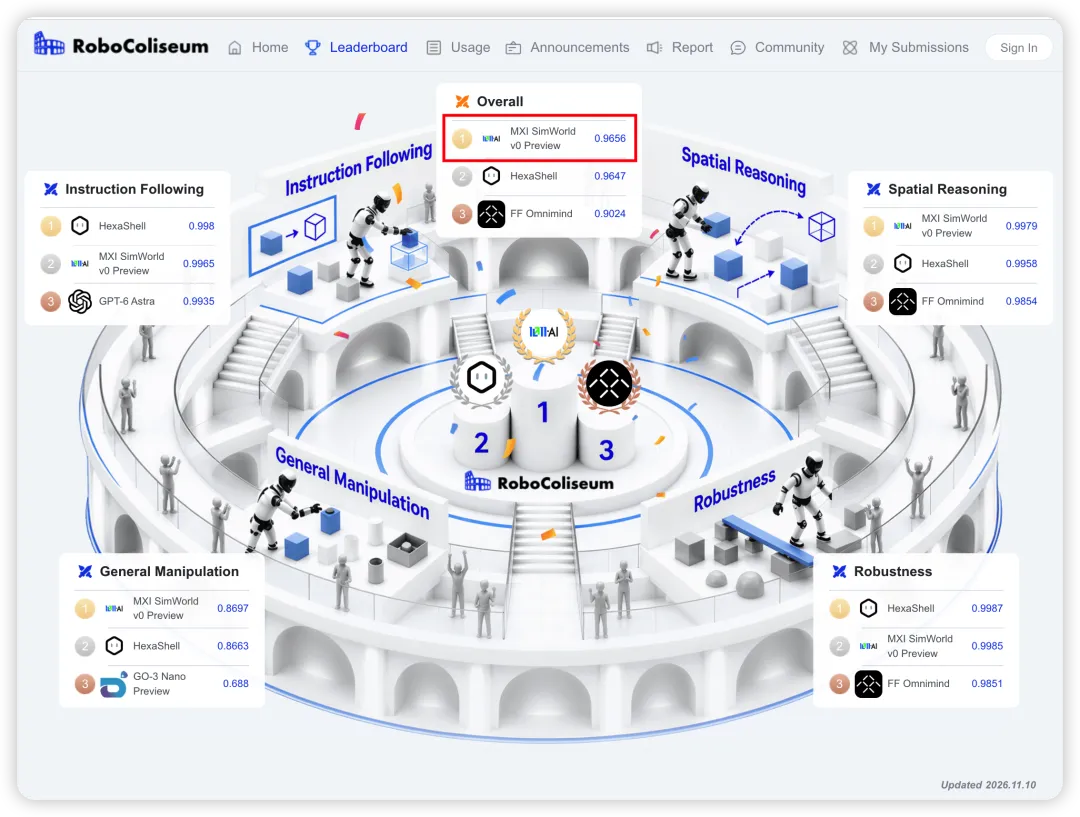
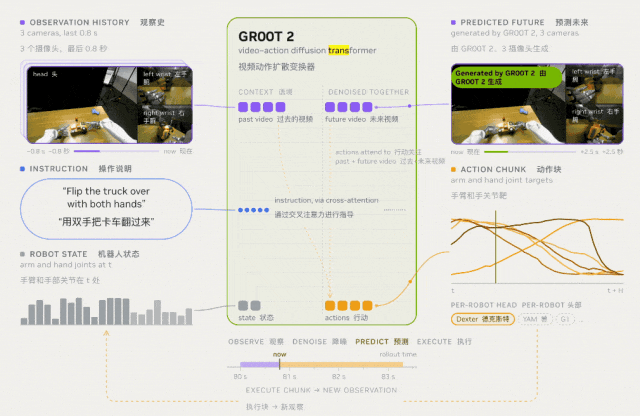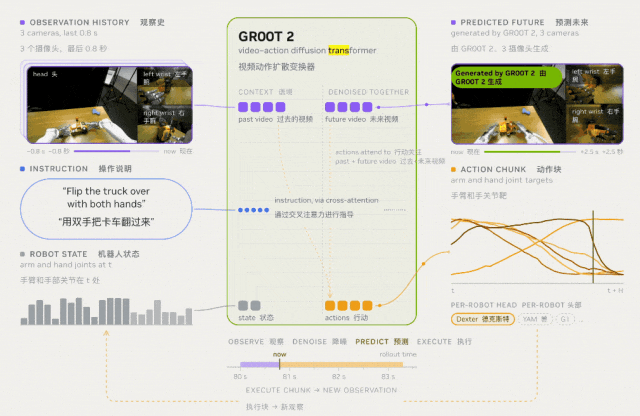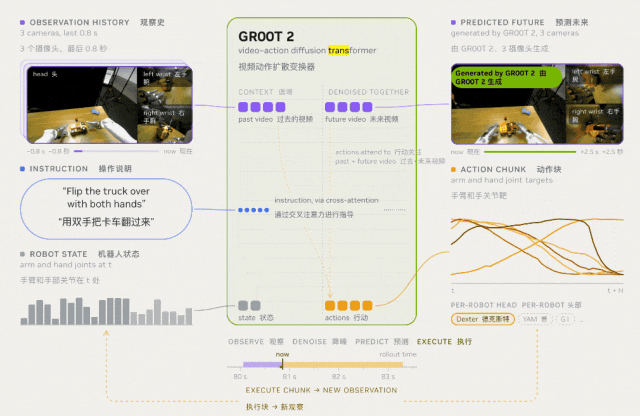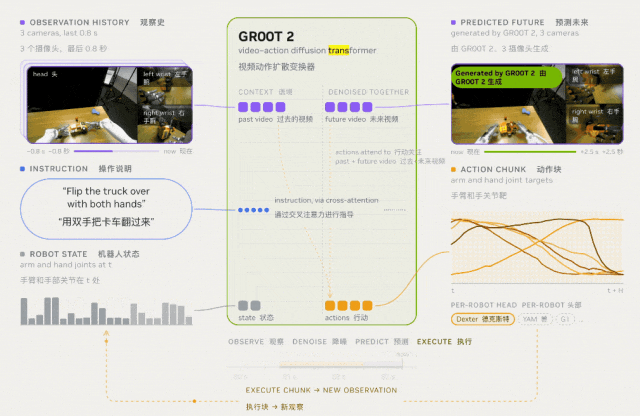 The model reads recent video, mission instructions, and robot status, combines future video with an action block, performs this action, and then proceeds to the next round of prediction. Simply put, it both generates the next possible image and generates the robot actions needed to achieve this result. In this process, the GR00T 2 predicts how the scenarios should change, learns the laws of physics from human video, and converts the program into corresponding machine control instructions for small output heads (small per-robot heads) of different human bodies.Ranked in the top three and topped the charts several timesFinally, Intel also disclosed that it is working with other companies to explore model capabilities. Chinese-Taiwanese robot company Nexuni is testing the GR00T 2 for garment processing, Foxconn is automating the GR00T 2 for server manufacturing plants, and Siemens is evaluating its applicability in various industrial scenarios.
05.
English: Ingrid wants to be more than a pimp and a pimpIn addition to GR00T 2, Jim Fan announces at CoRL 2026 that Ingrid will be promoting fully open source robotics-related technologies:In December, model weights and Cross-Adapt methods for GR00T 2 and Turbo were unveiled, as well as real-to-virtual simulation SimFoundry, the ASPIRE smart-body framework for sustainable accumulation of skills, data compilation and labeling tools Flora, and the first 100,000 hours of training data for the Human-1M, including complete hardware design drawings for devices such as UMI and DexUMI.
In other words, Invidia's open-source coverage in the physical domain includes not only models, but also data, simulation, smart body frameworks, and hardware design. In addition to computing platforms such as RTX 5090, Jetson Thor, the company is linking the software tools needed for robotics research and development with hardware infrastructure, covering everything from data acquisition, model training, to simulation evaluation, and real-machine deployment.
In this respect,Invisalign doesn't just want to sell chips as a vending machine, they want to collaborate with software, lower the barrier to robot development, accelerate the application of robotics from the laboratory to the real world, and form an industrial aircraft.This role is obviously more favourable to the market than that of a peddler.